projects / 4
Robotic Claw Machine
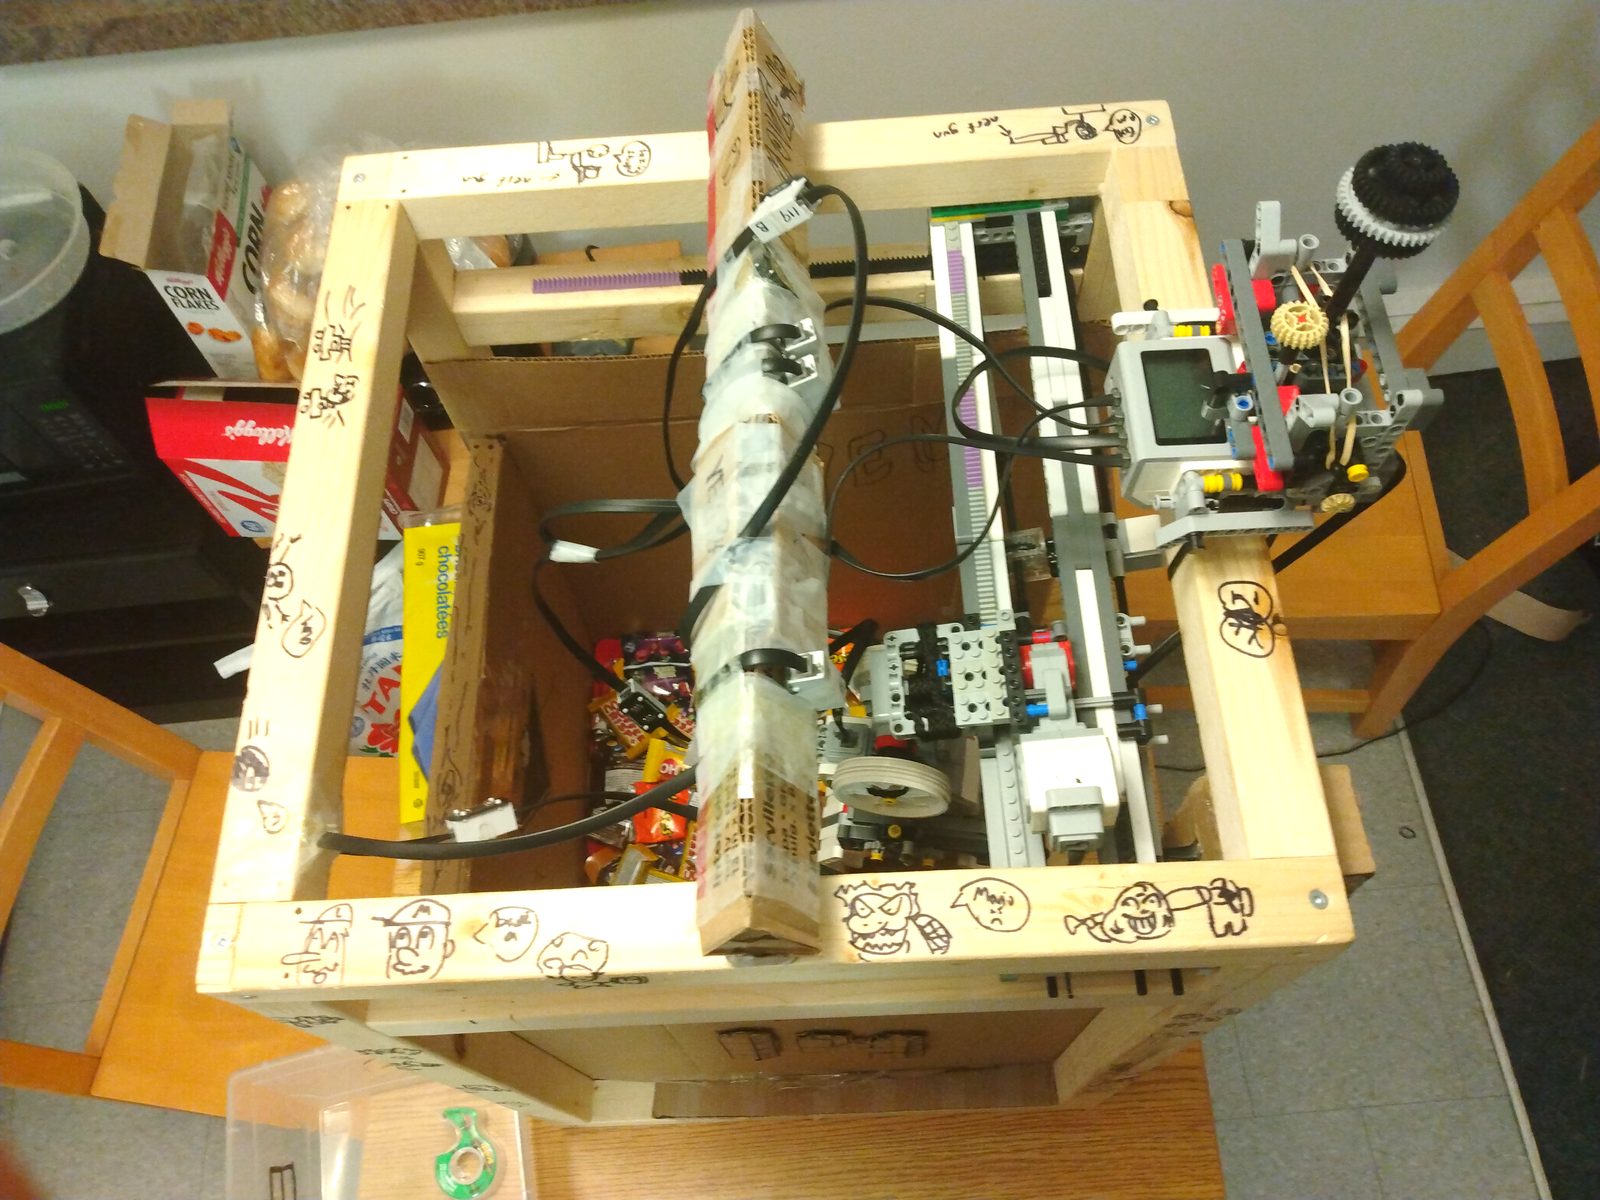
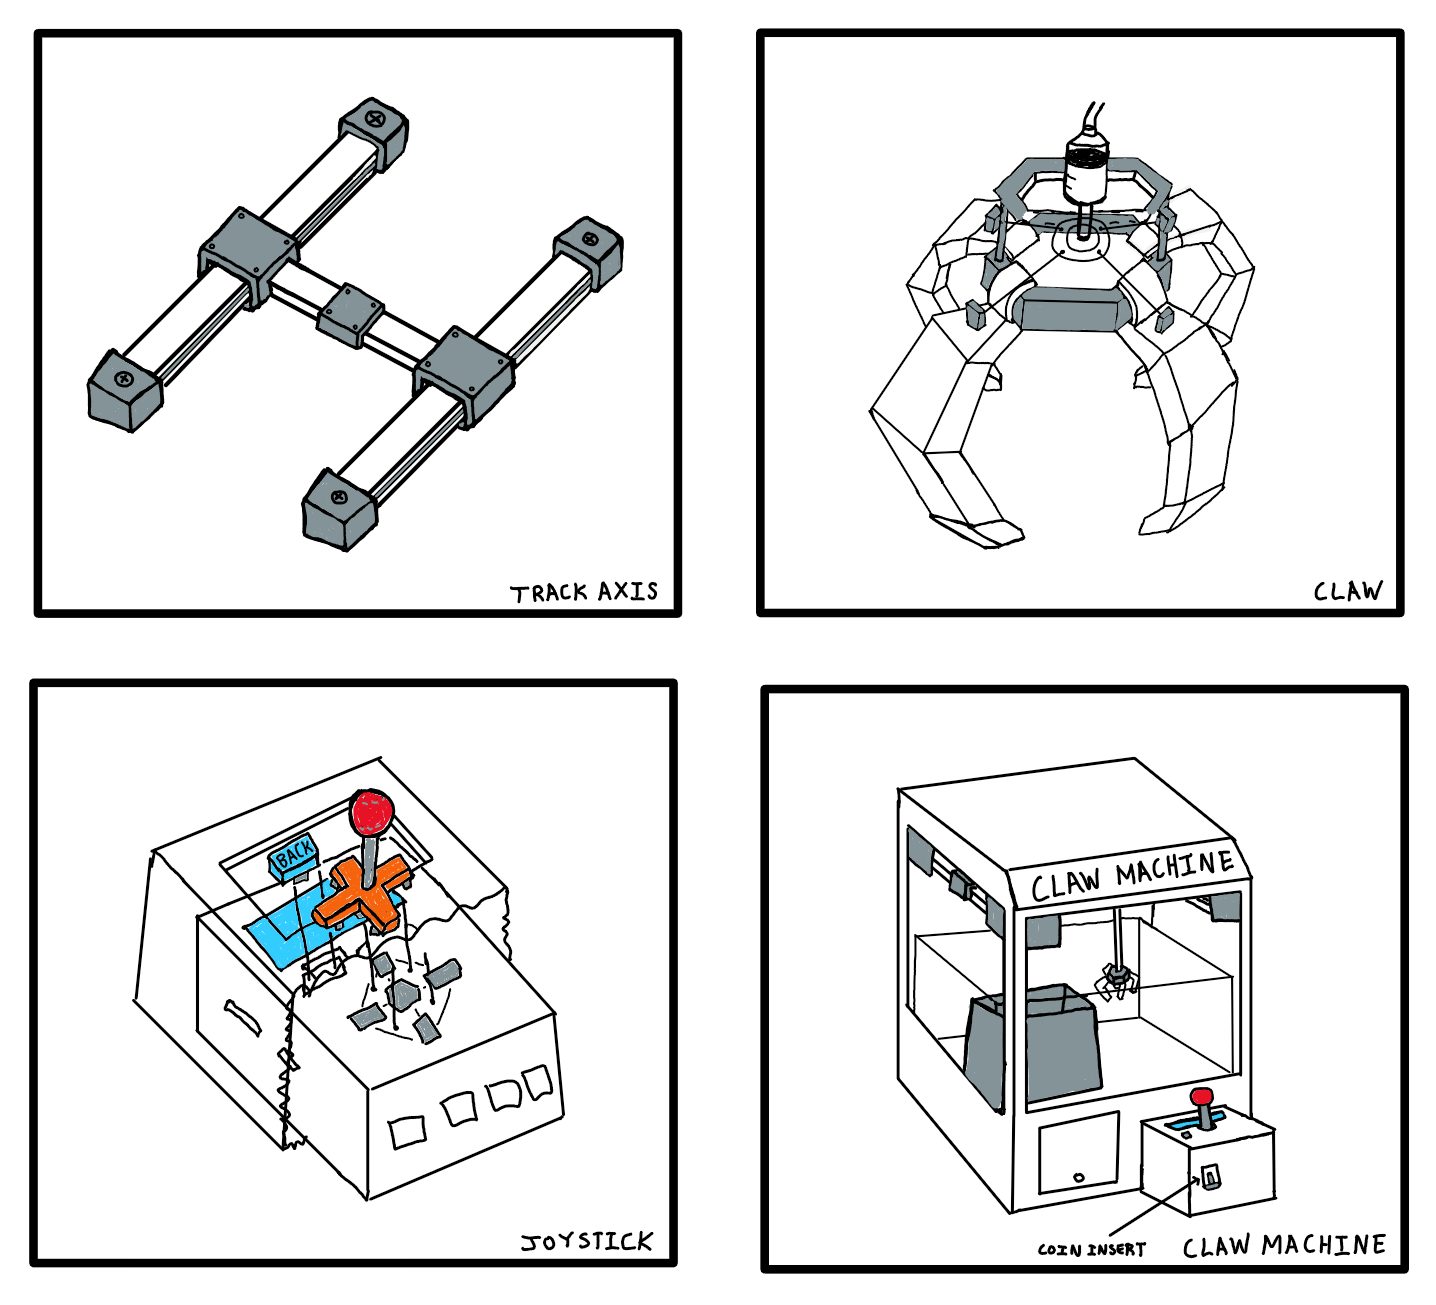
A fully functional desktop robotic claw machine designed and built for a first-year Mechatronics robotics competition. Features a custom 3-axis rack-and-pinion Cartesian gantry, dual-axis analog joystick control, and a motorized 3-jaw linkage claw mechanism.


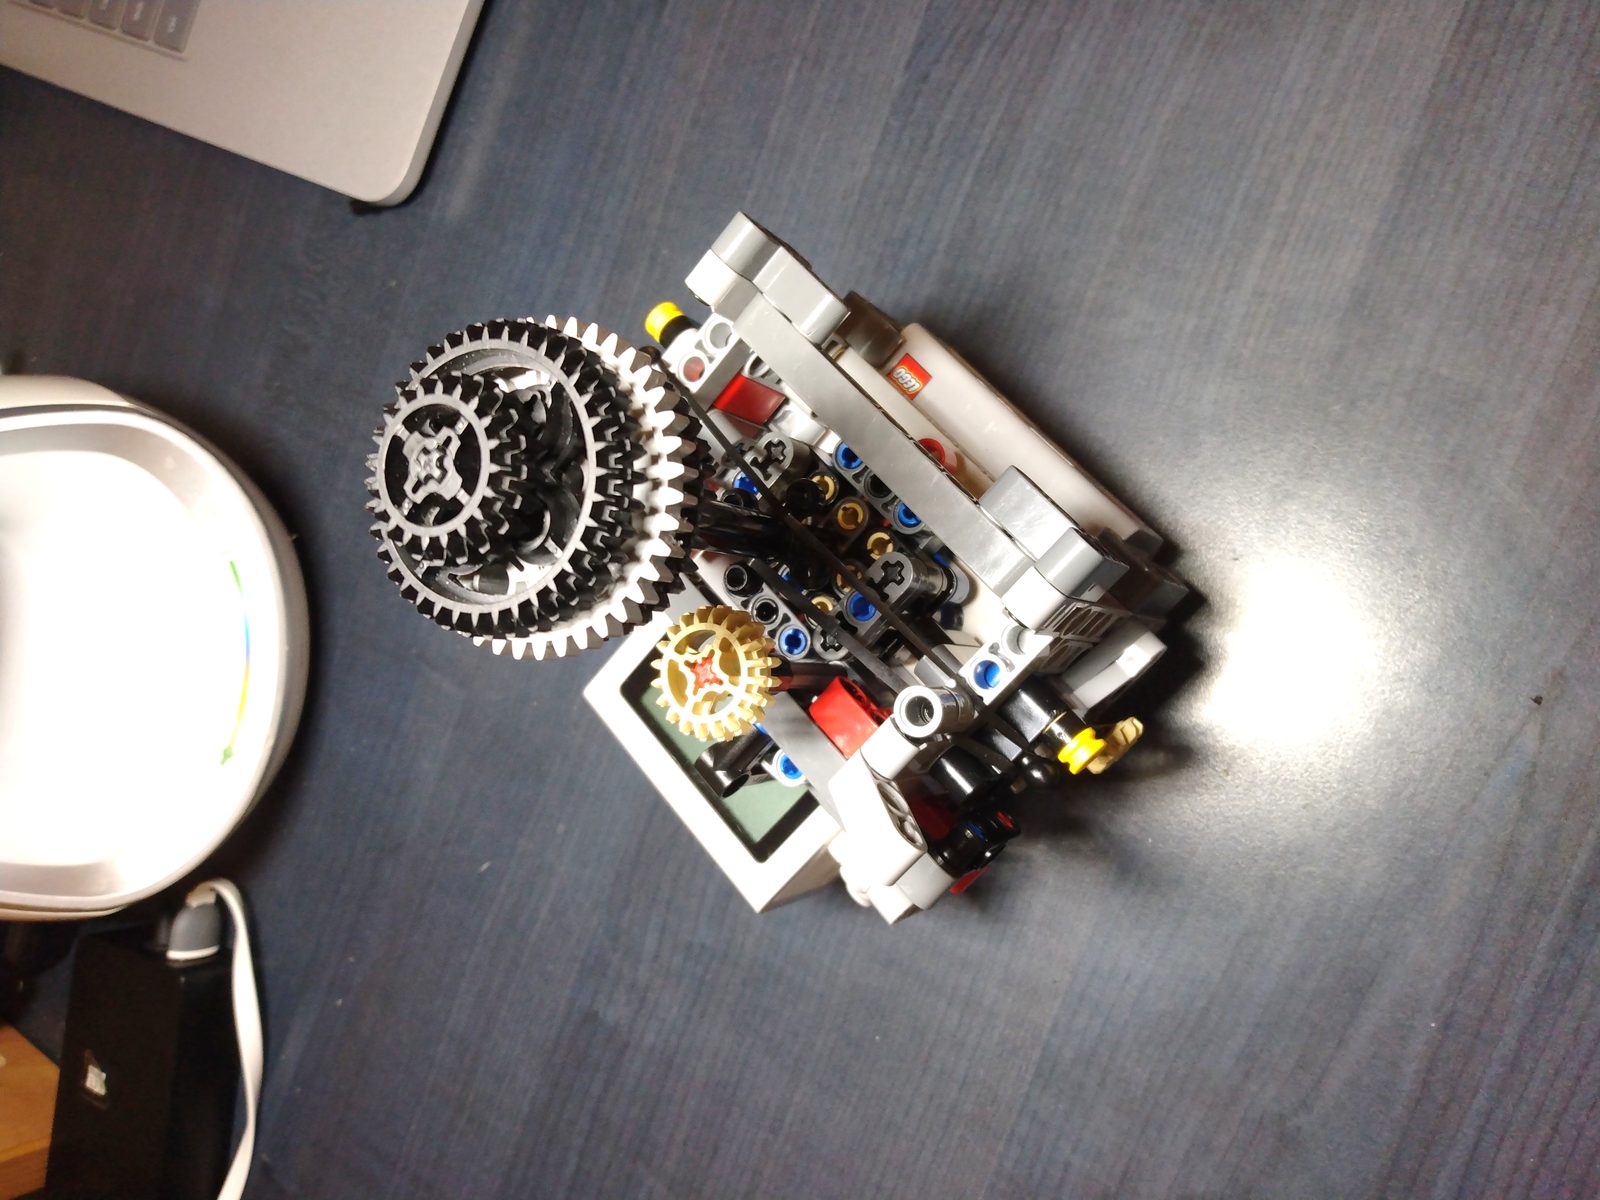
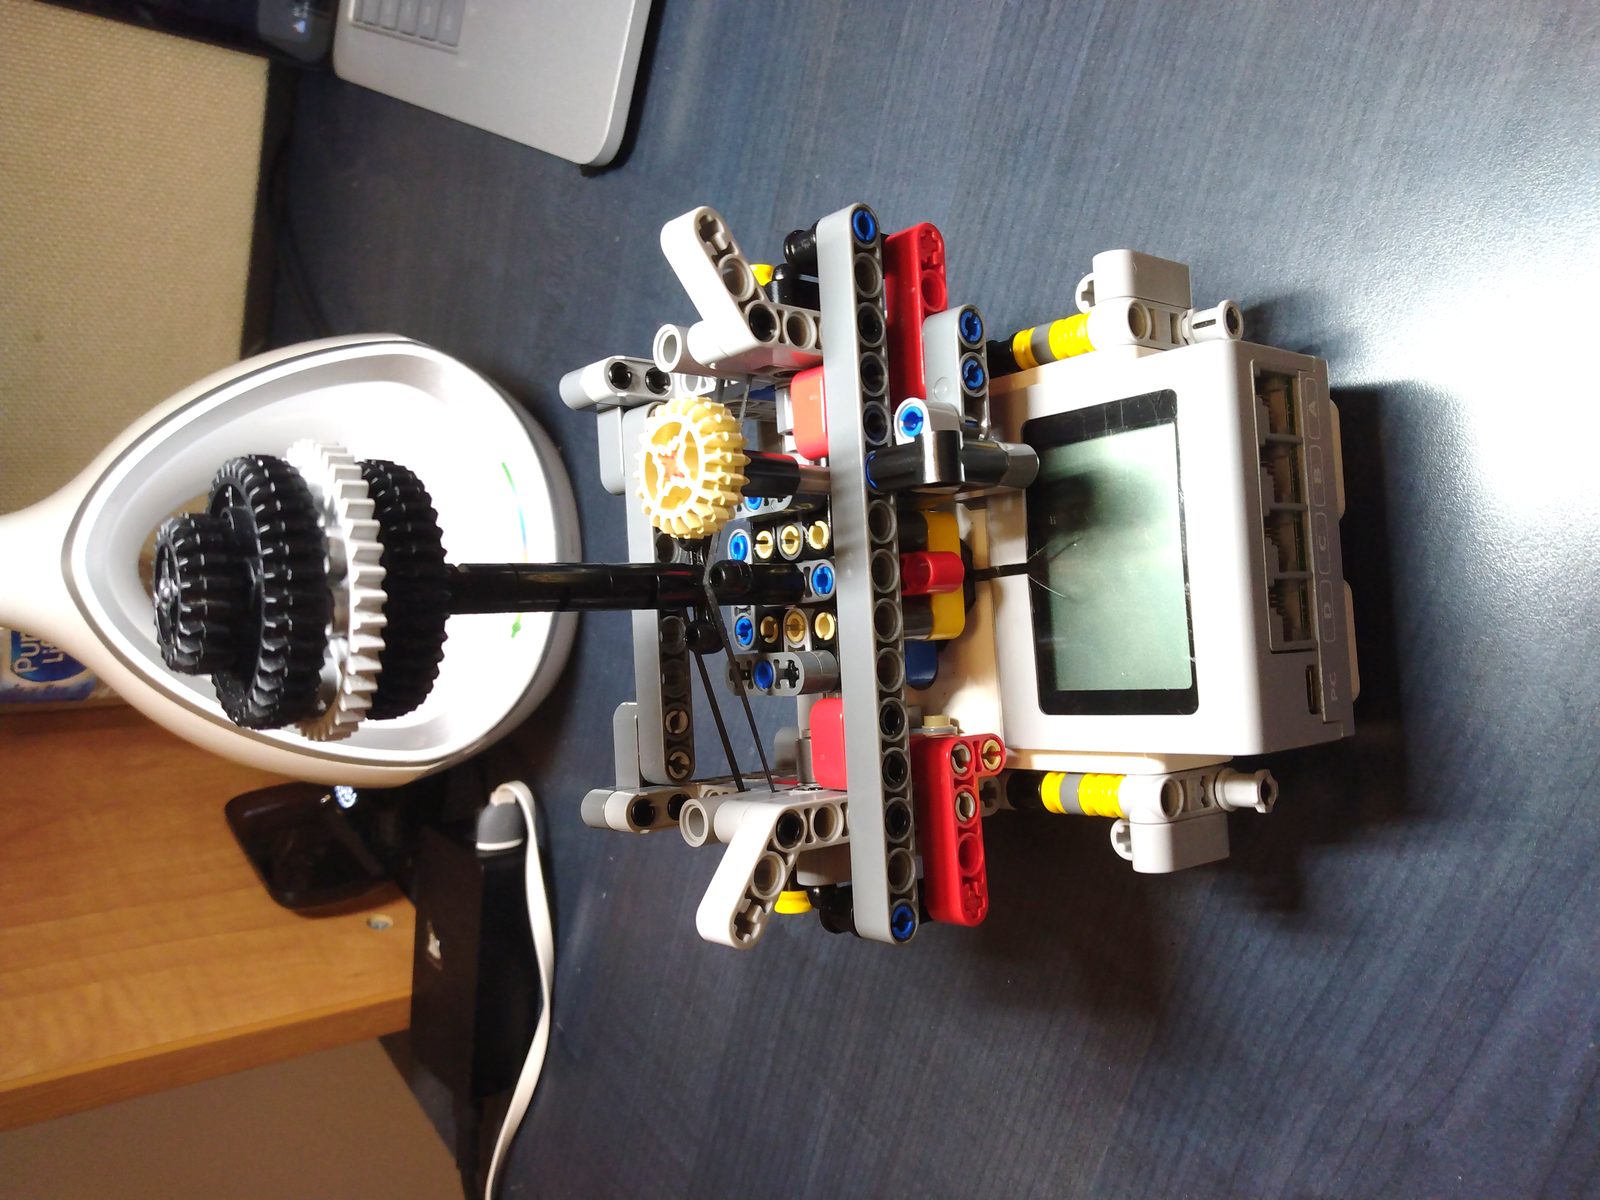
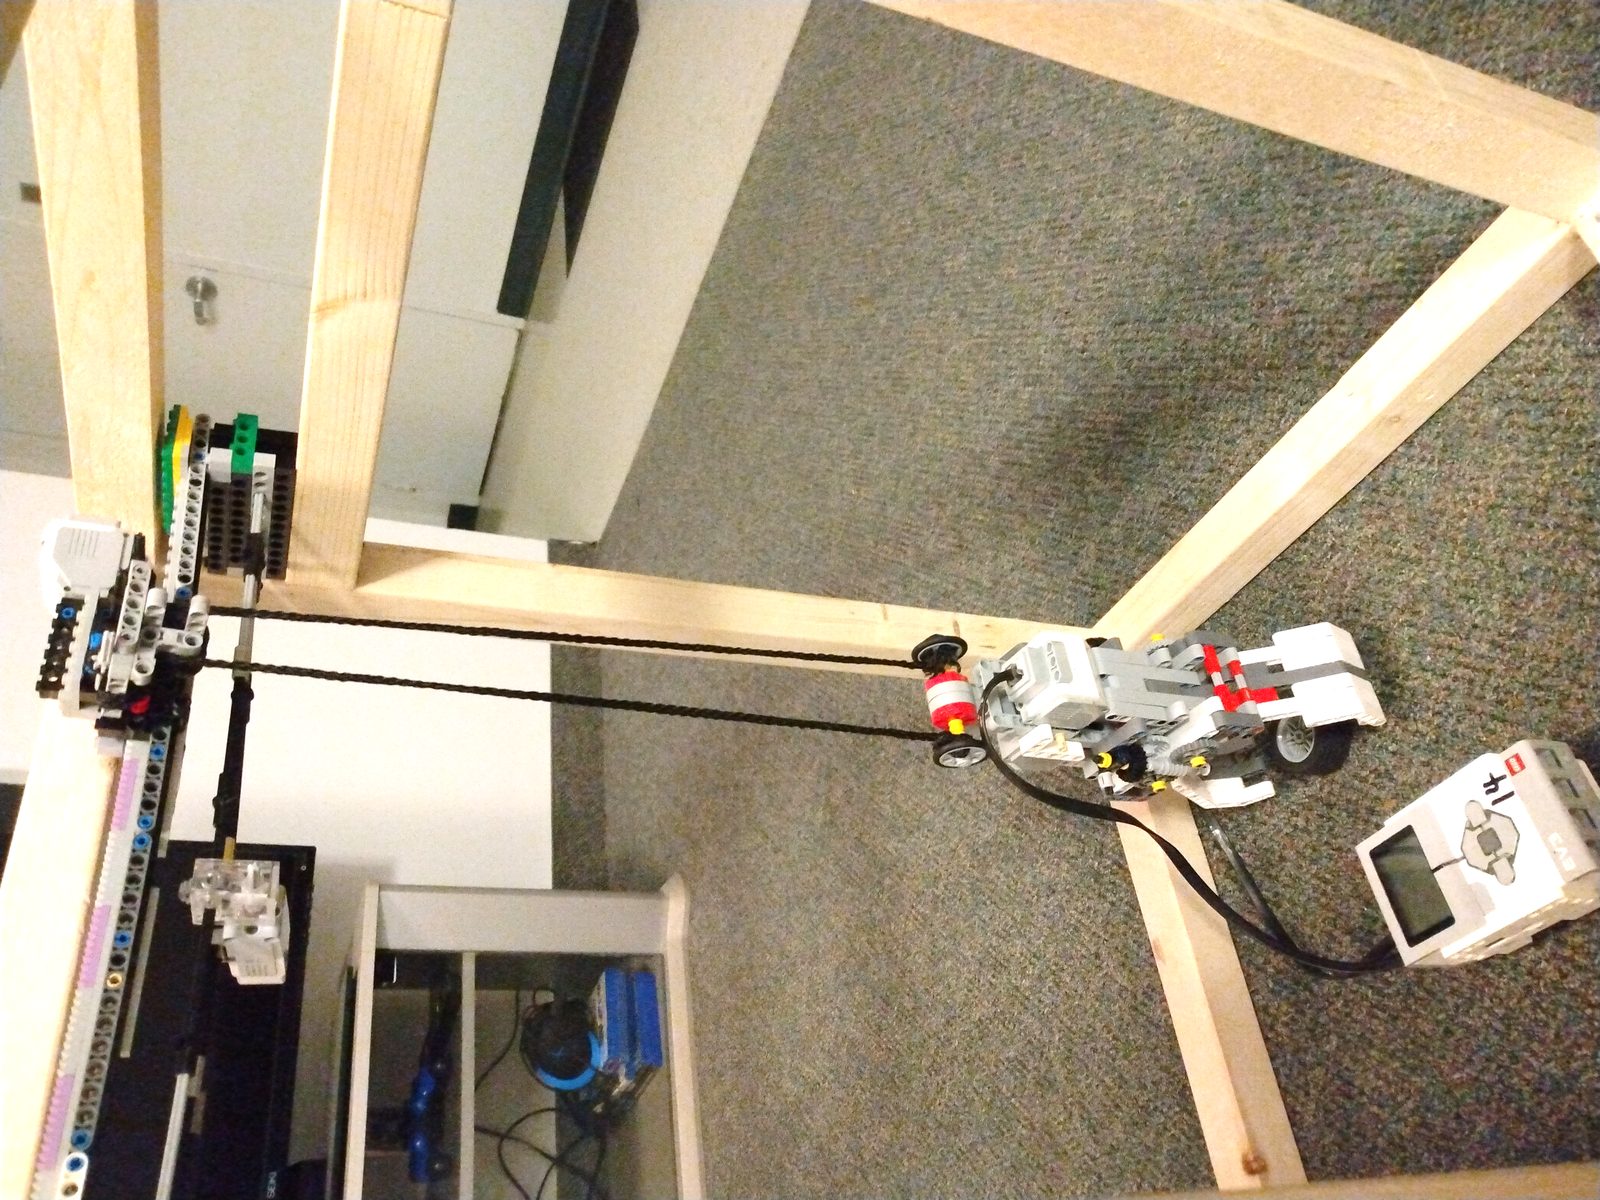
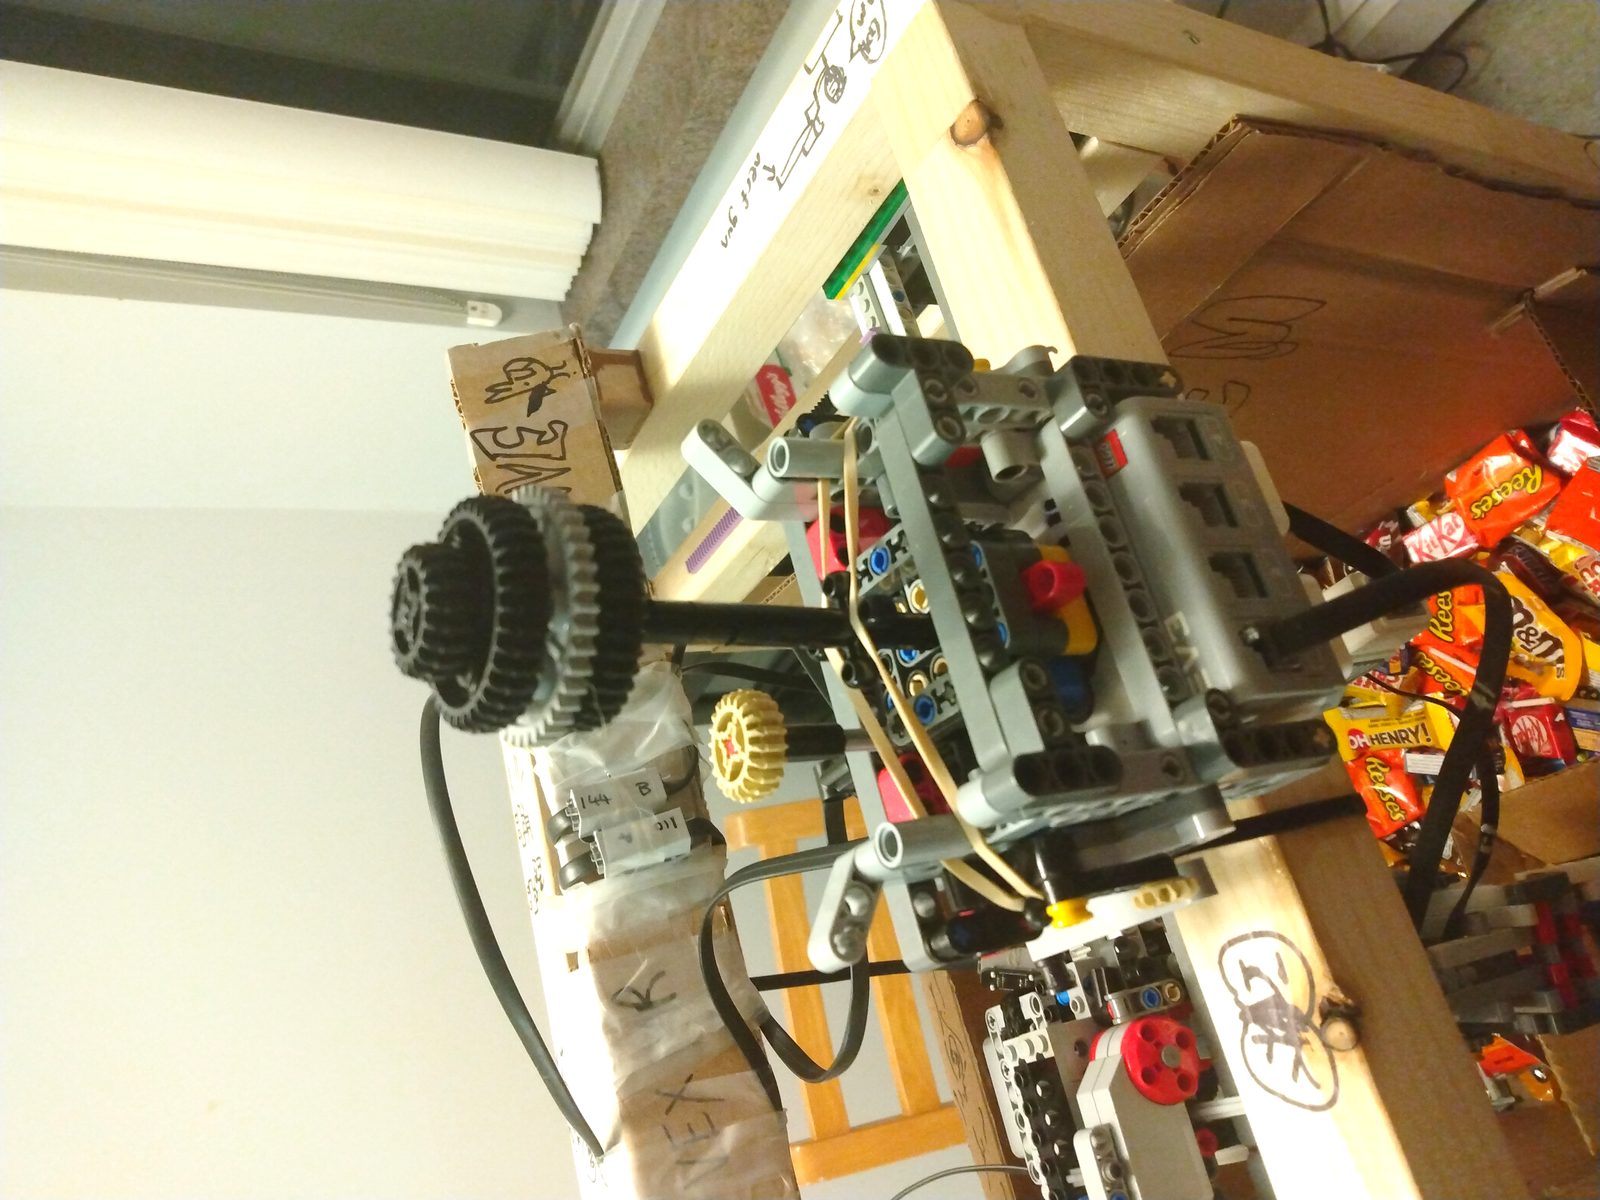
- Designed and fabricated a 3-axis Cartesian gantry system in SolidWorks with smooth linear guide rails and anti-backlash gears.
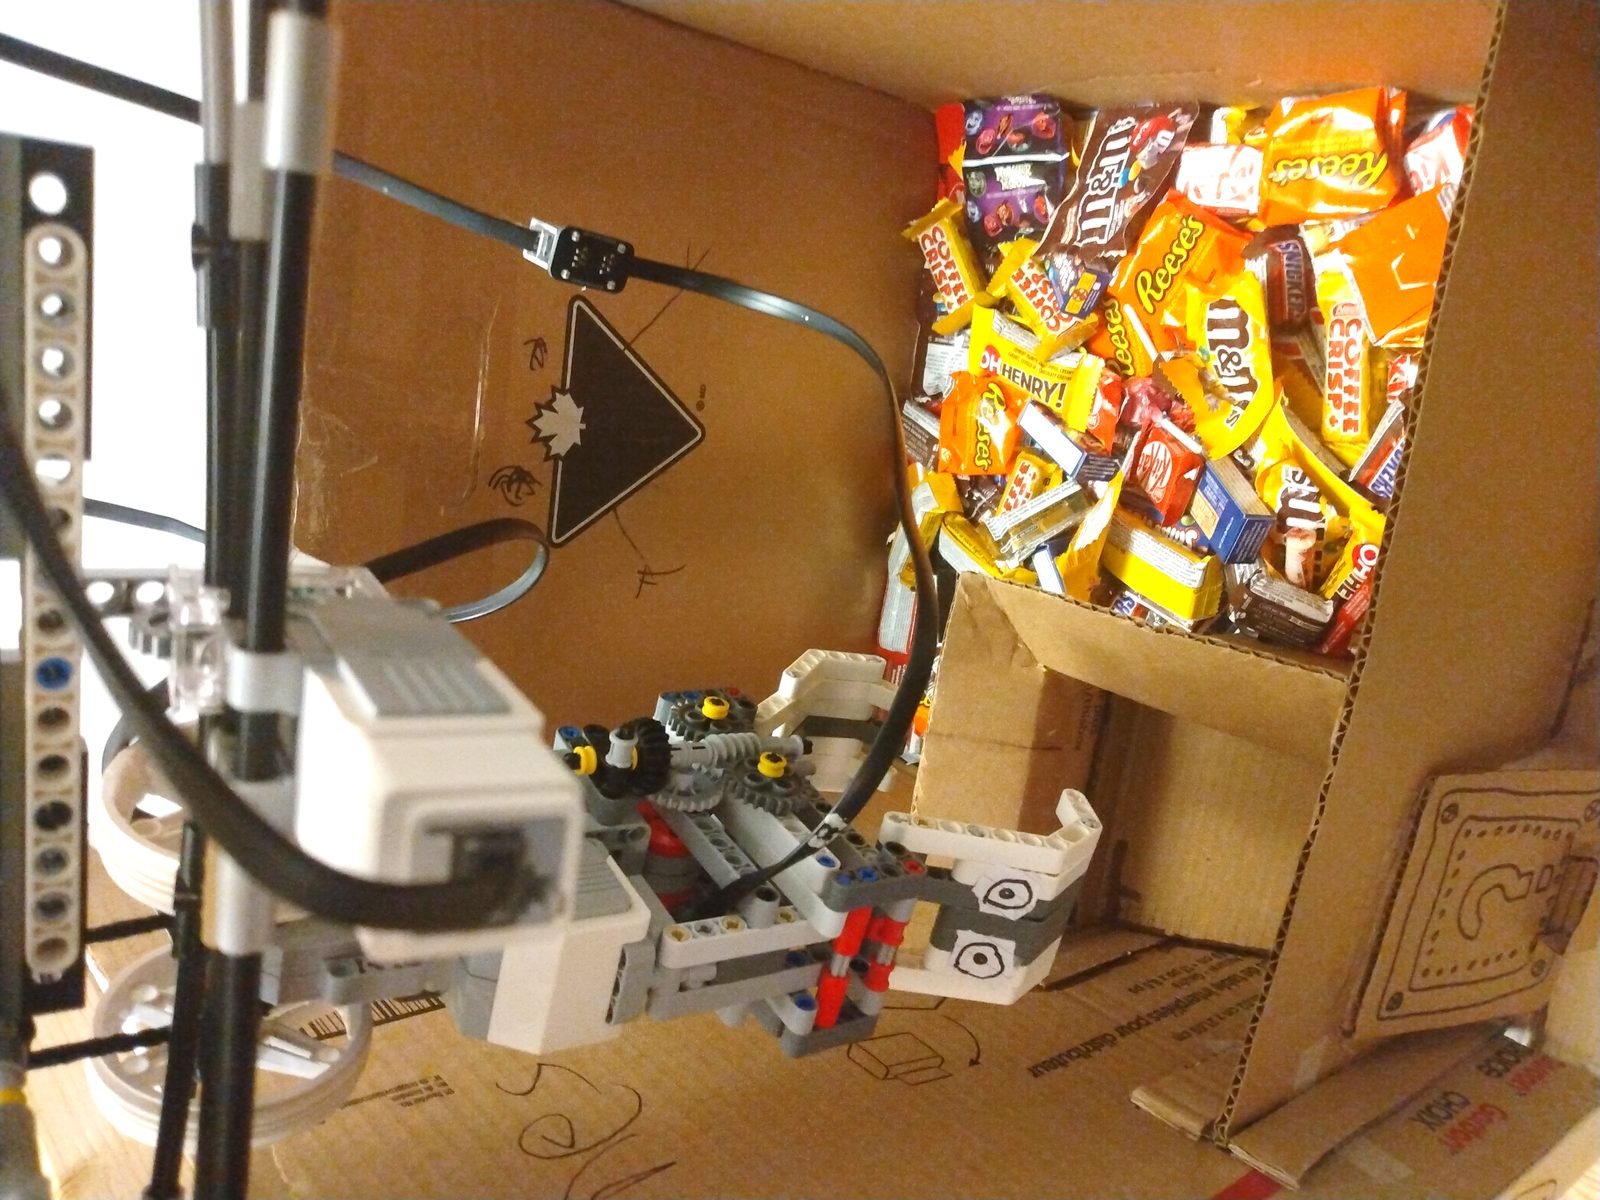
- Modeled and optimized a 3-finger articulating claw linkage with high friction grip pads for irregular prize retrieval.
- Programmed real-time motion control firmware with boundary limit detection and smooth PWM motor acceleration curves.
01Mechanical Design & CAD Assembly
Comprehensive SolidWorks 3D CAD modeling, multi-body kinematics, tolerance stack-up analysis, and assembly architecture.
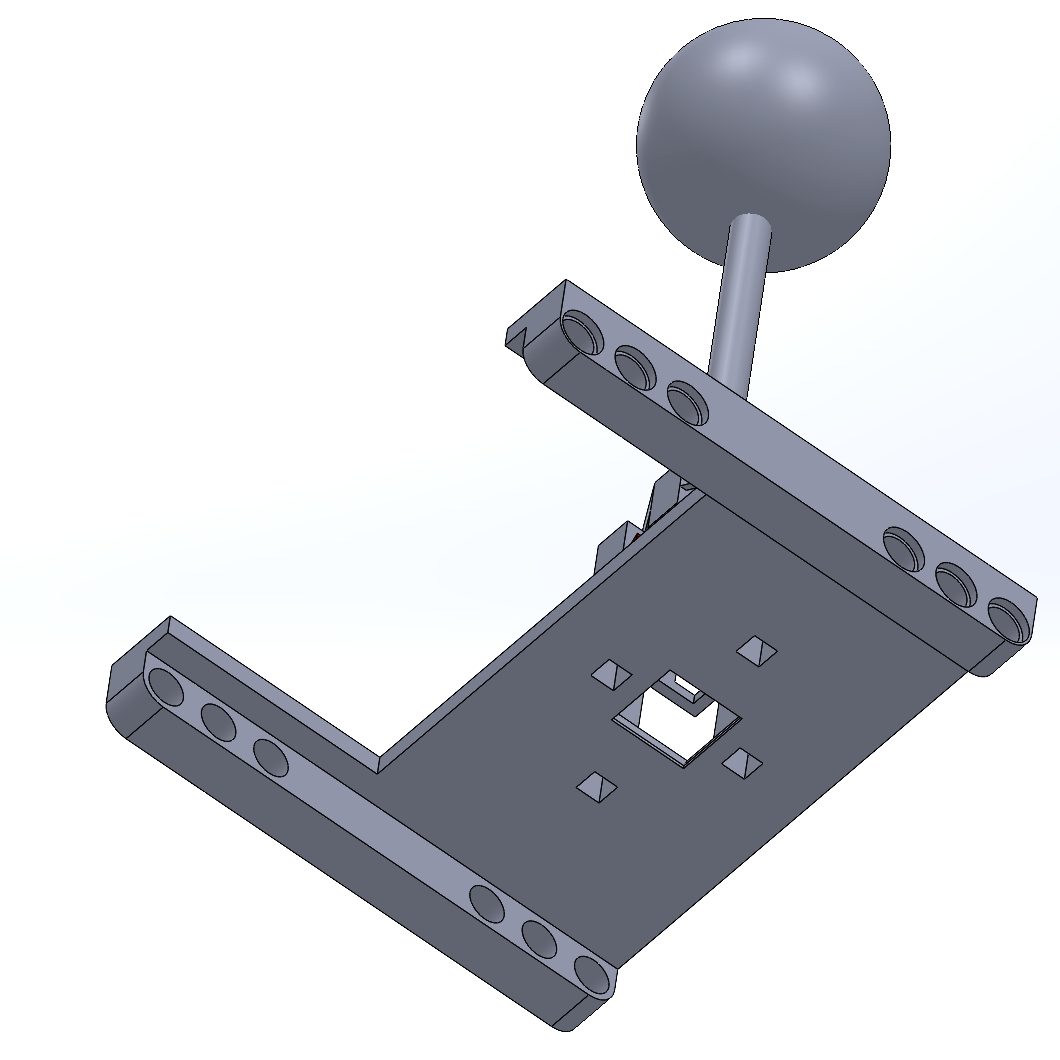
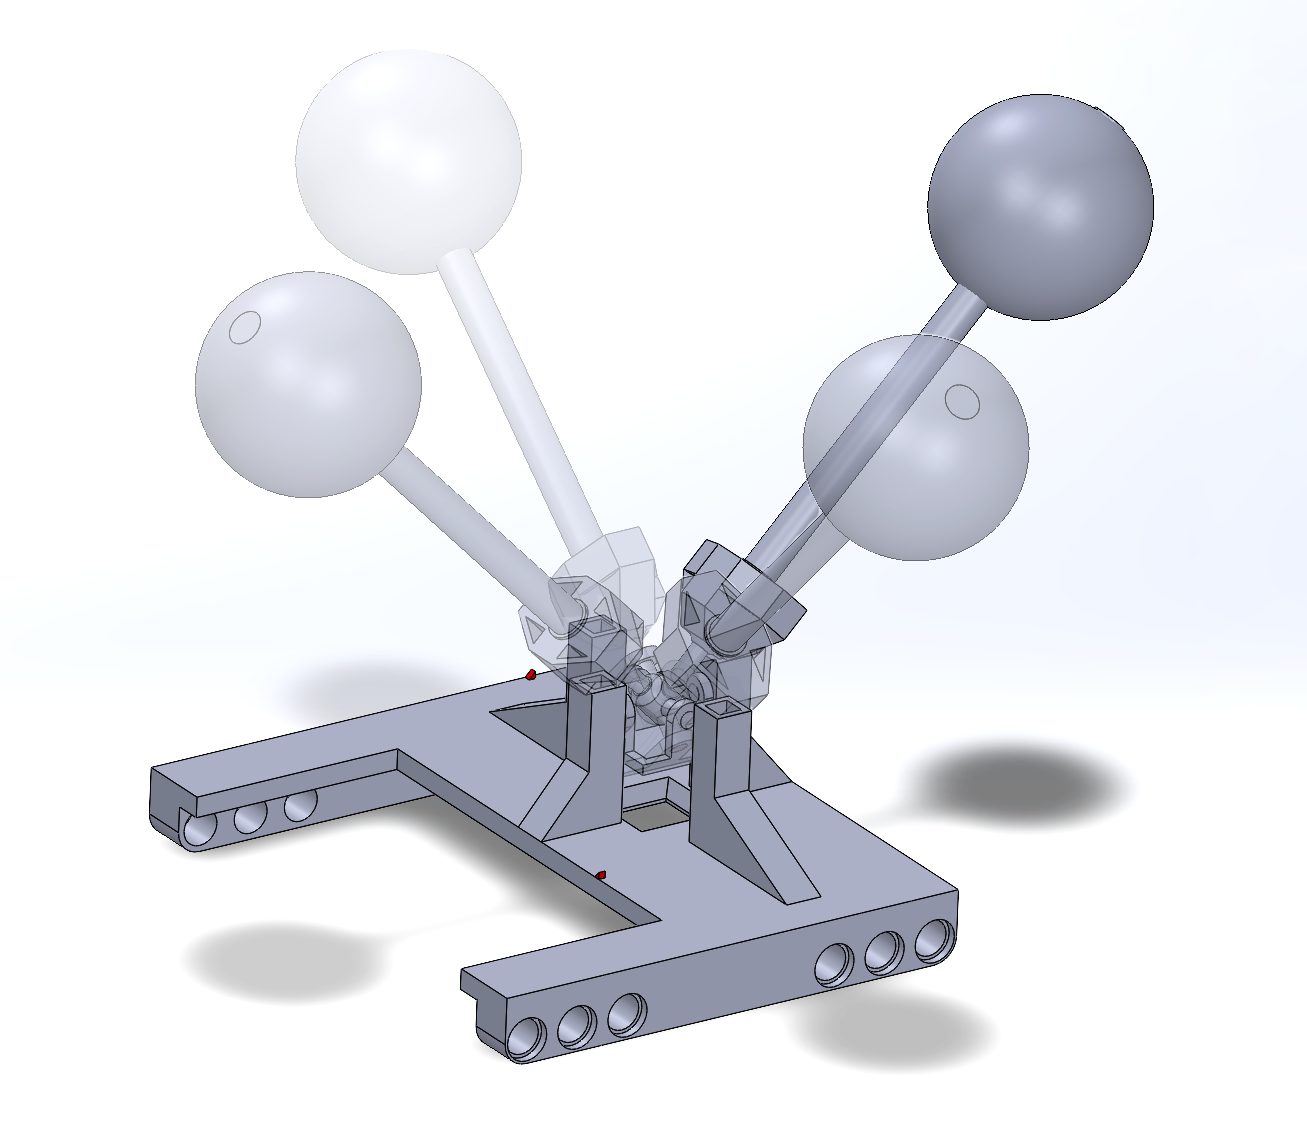
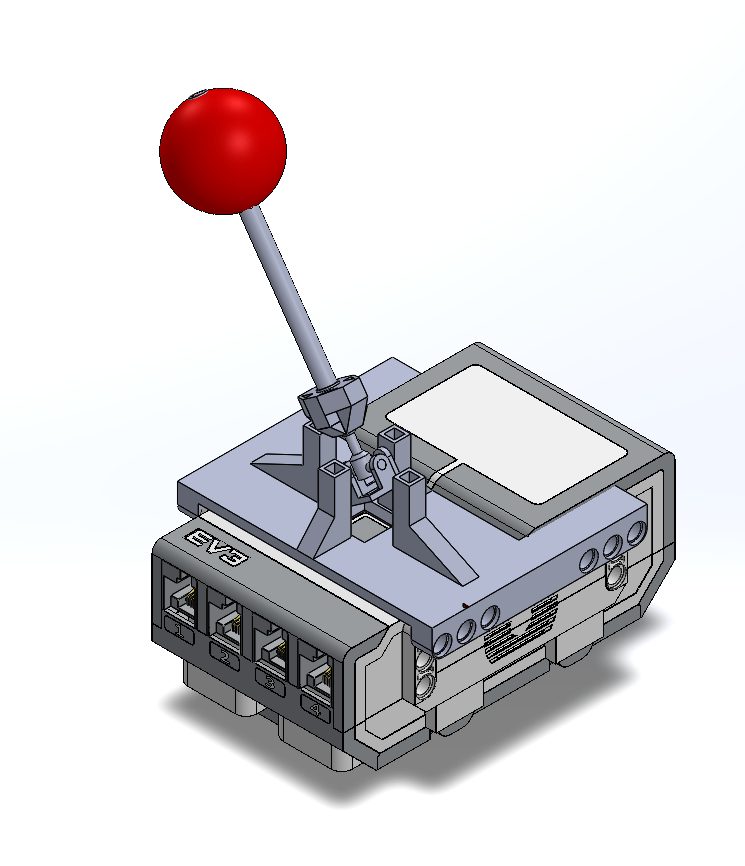
01.1 2-Axis Joystick Kinematics & Ergonomic Modeling
SolidWorks 3D kinematic model of a dual-axis analog joystick mechanism delivering intuitive multi-directional gantry control.
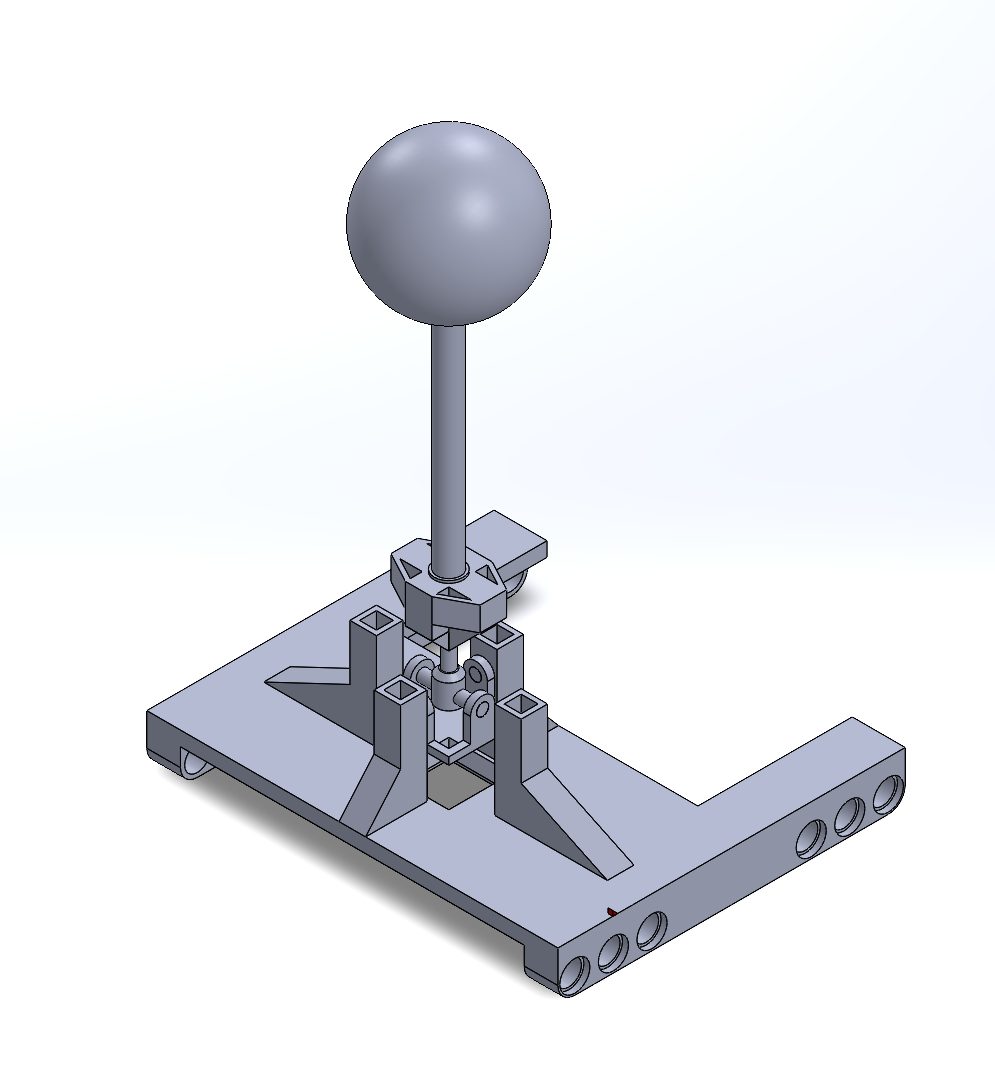
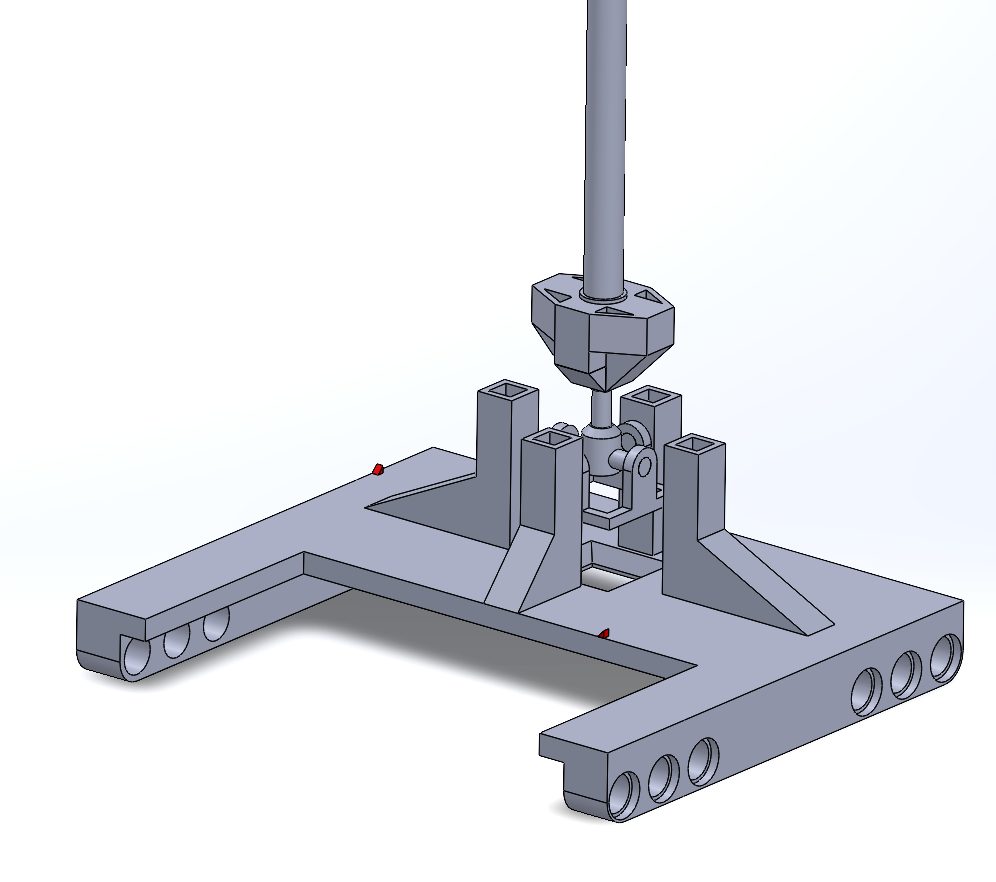
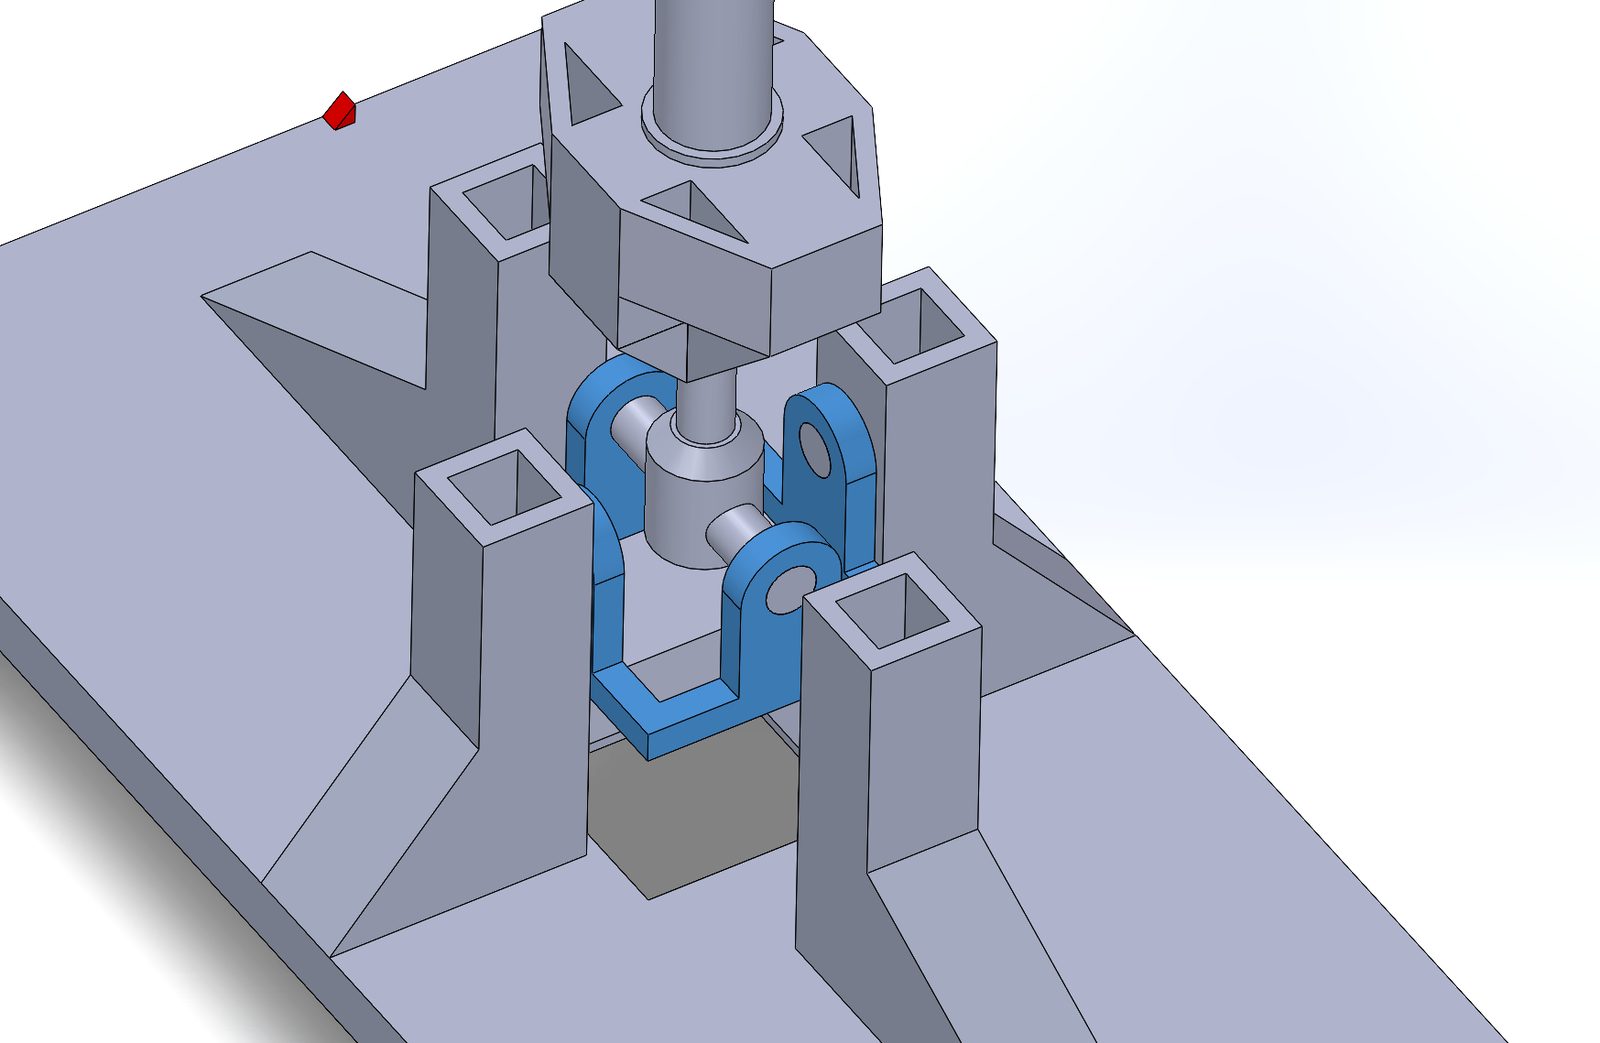
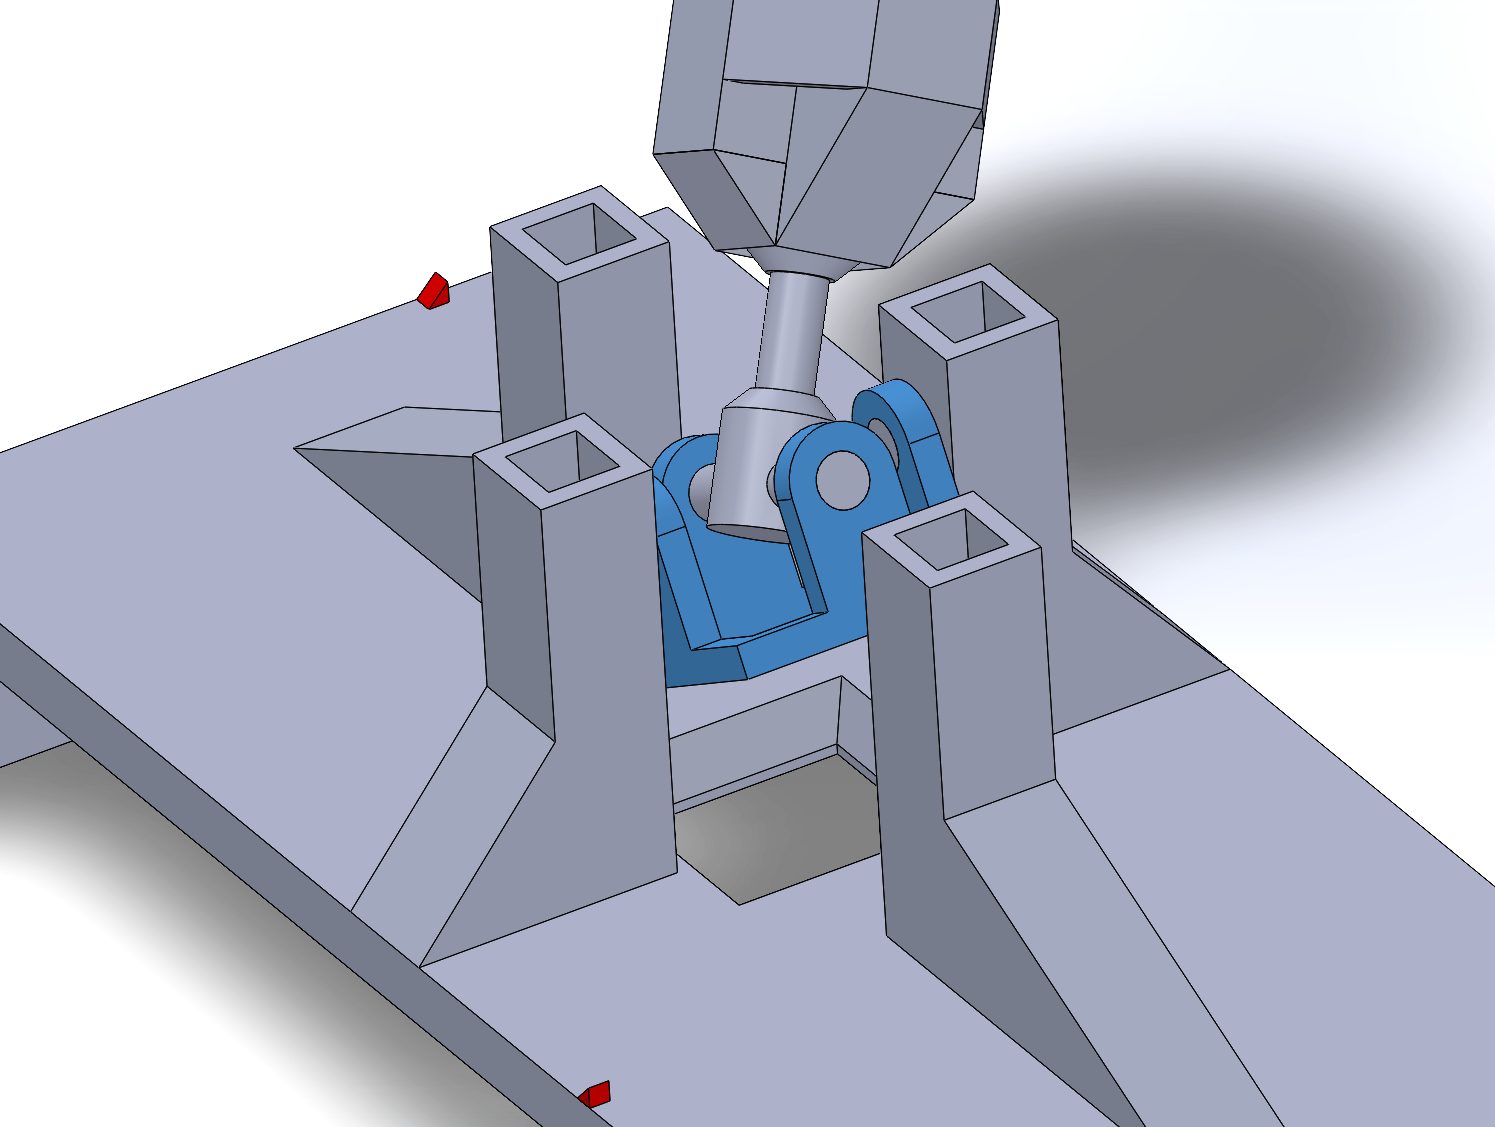
01.2 Dual-Axis Tilting Gimbal Mechanism
Orthogonal pivot plate geometry supporting two independent rotation axes for continuous joystick motion.
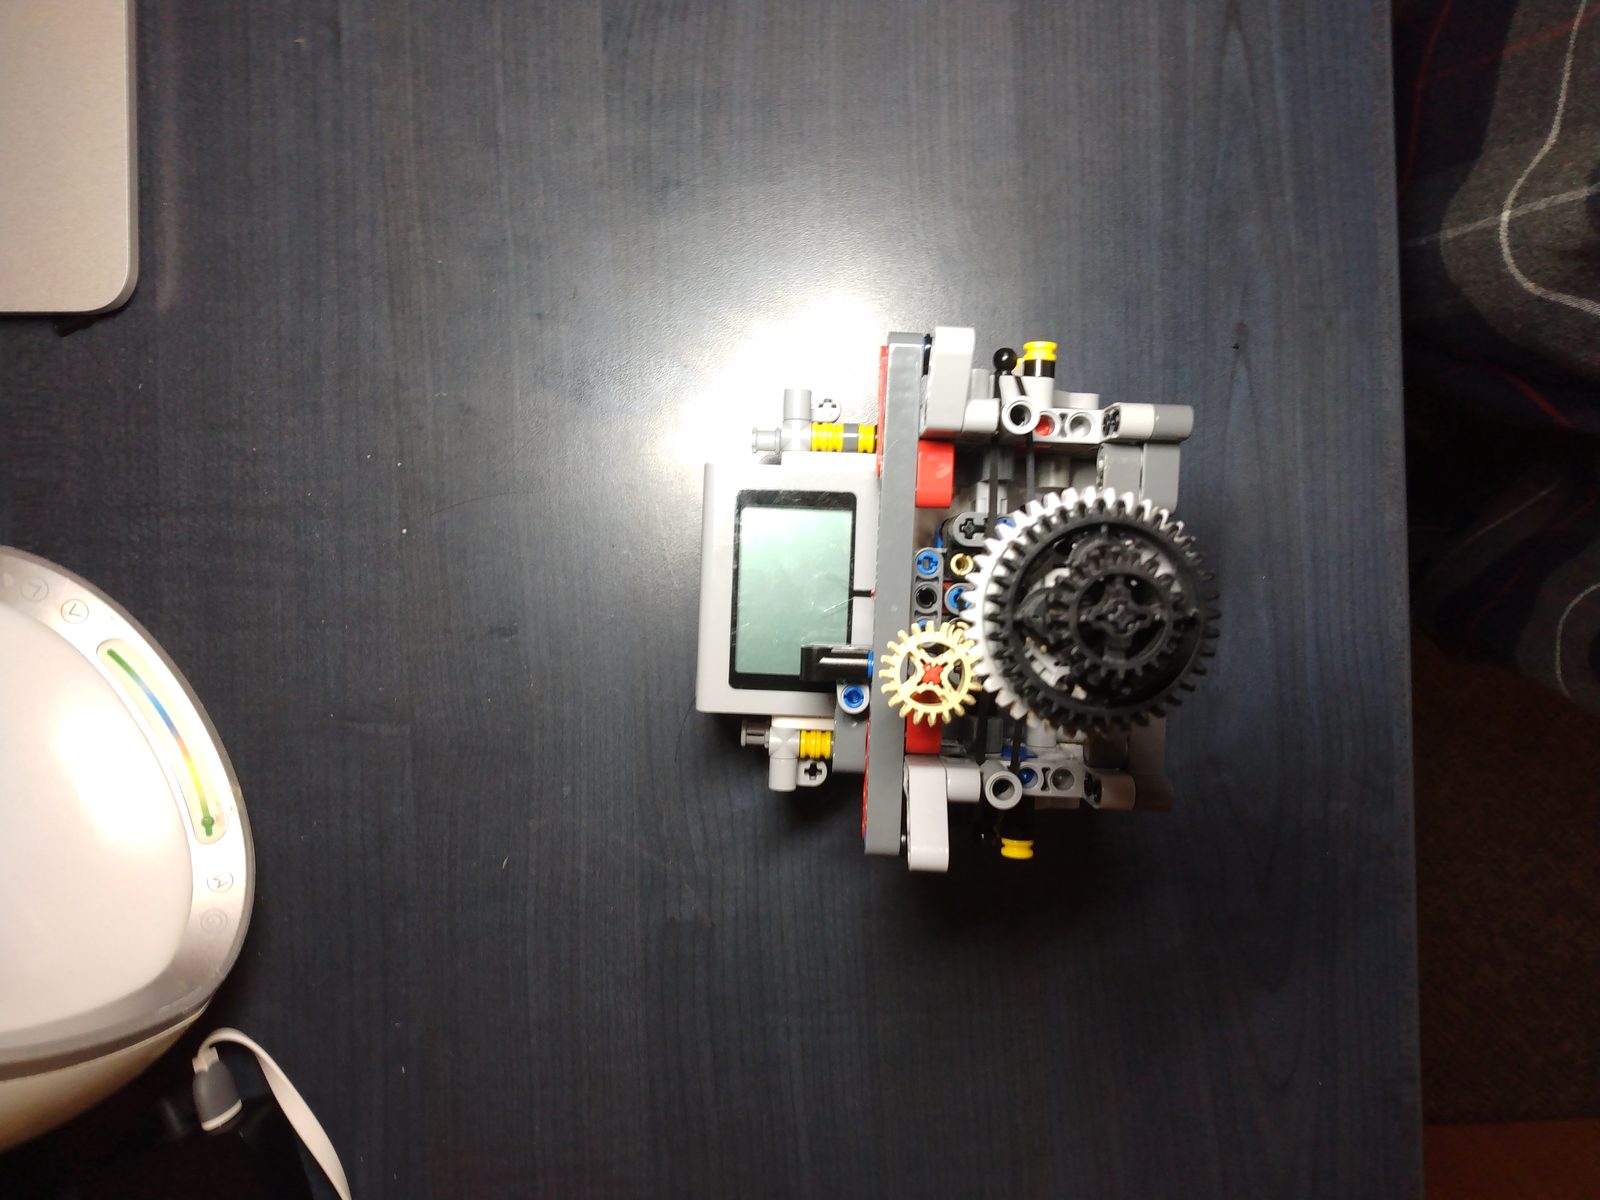
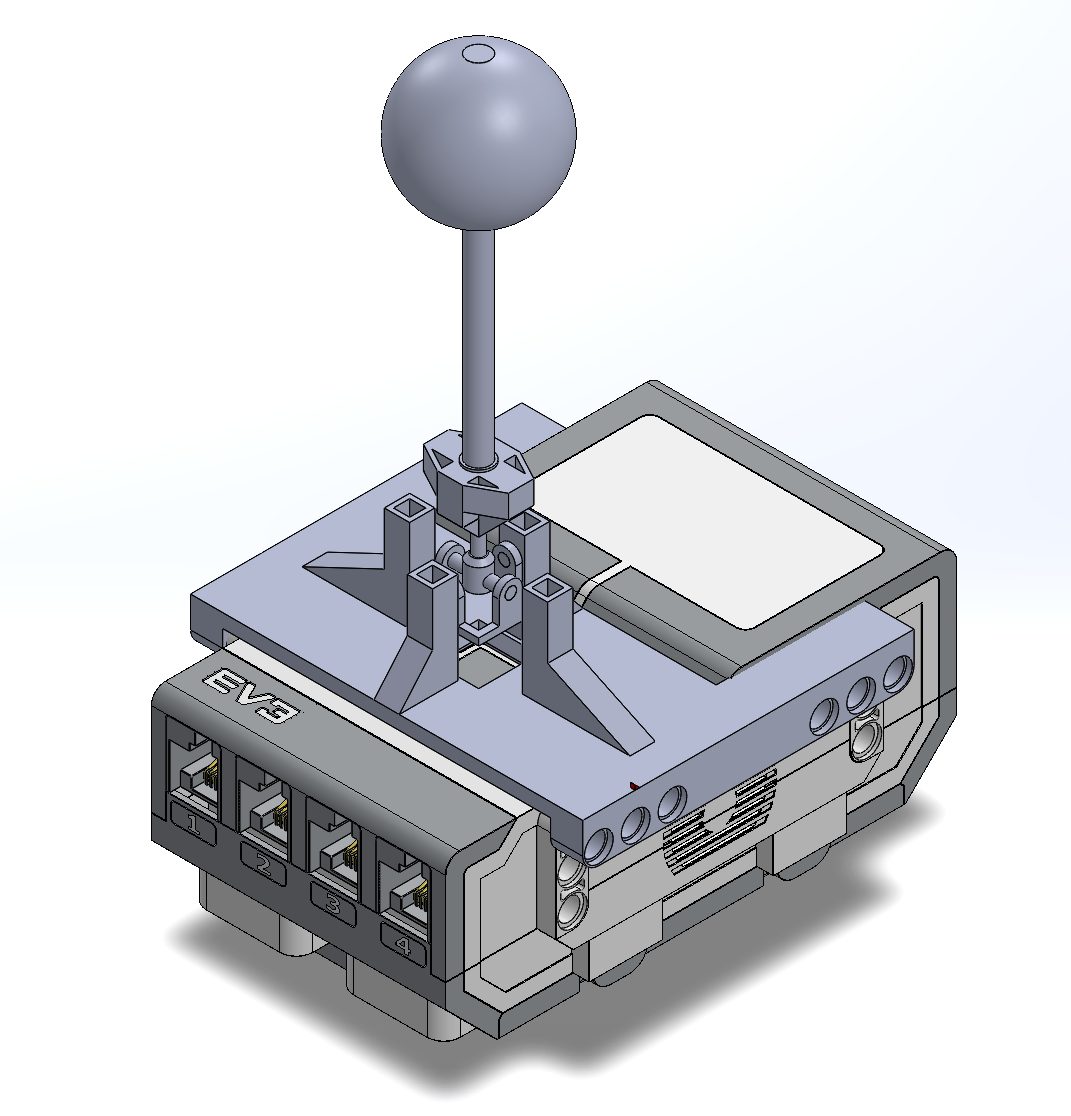
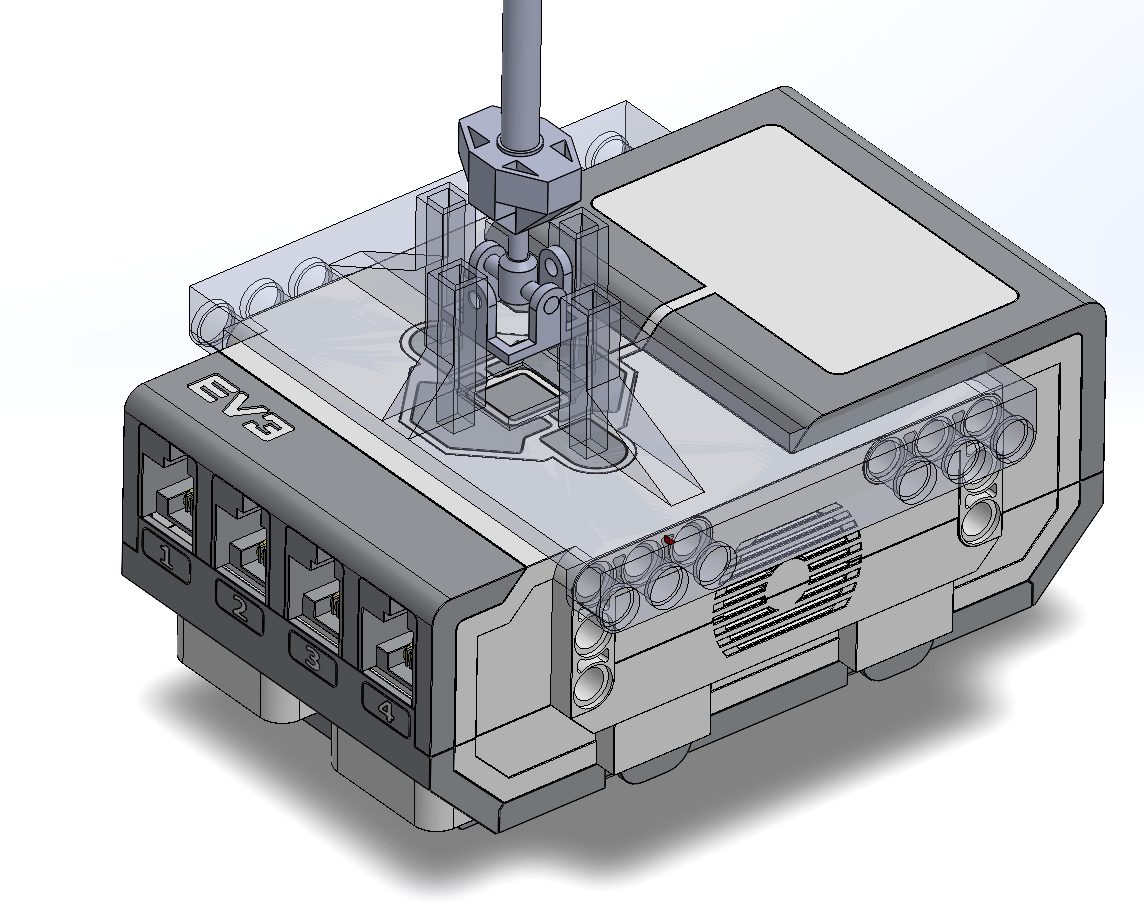
01.3 EV3 Direct-Mount Interface & Button Actuation
Custom bracket mating directly onto the LEGO Mindstorms EV3 brick, aligning mechanical joystick throws with physical push buttons.
02Prototyping, 3D Printing & Fabrication
Rapid prototyping iterations, slicing optimization (Bambu Studio / PrusaSlicer), material selection (PLA / PETG / Carbon Fiber), and precision fit checks.
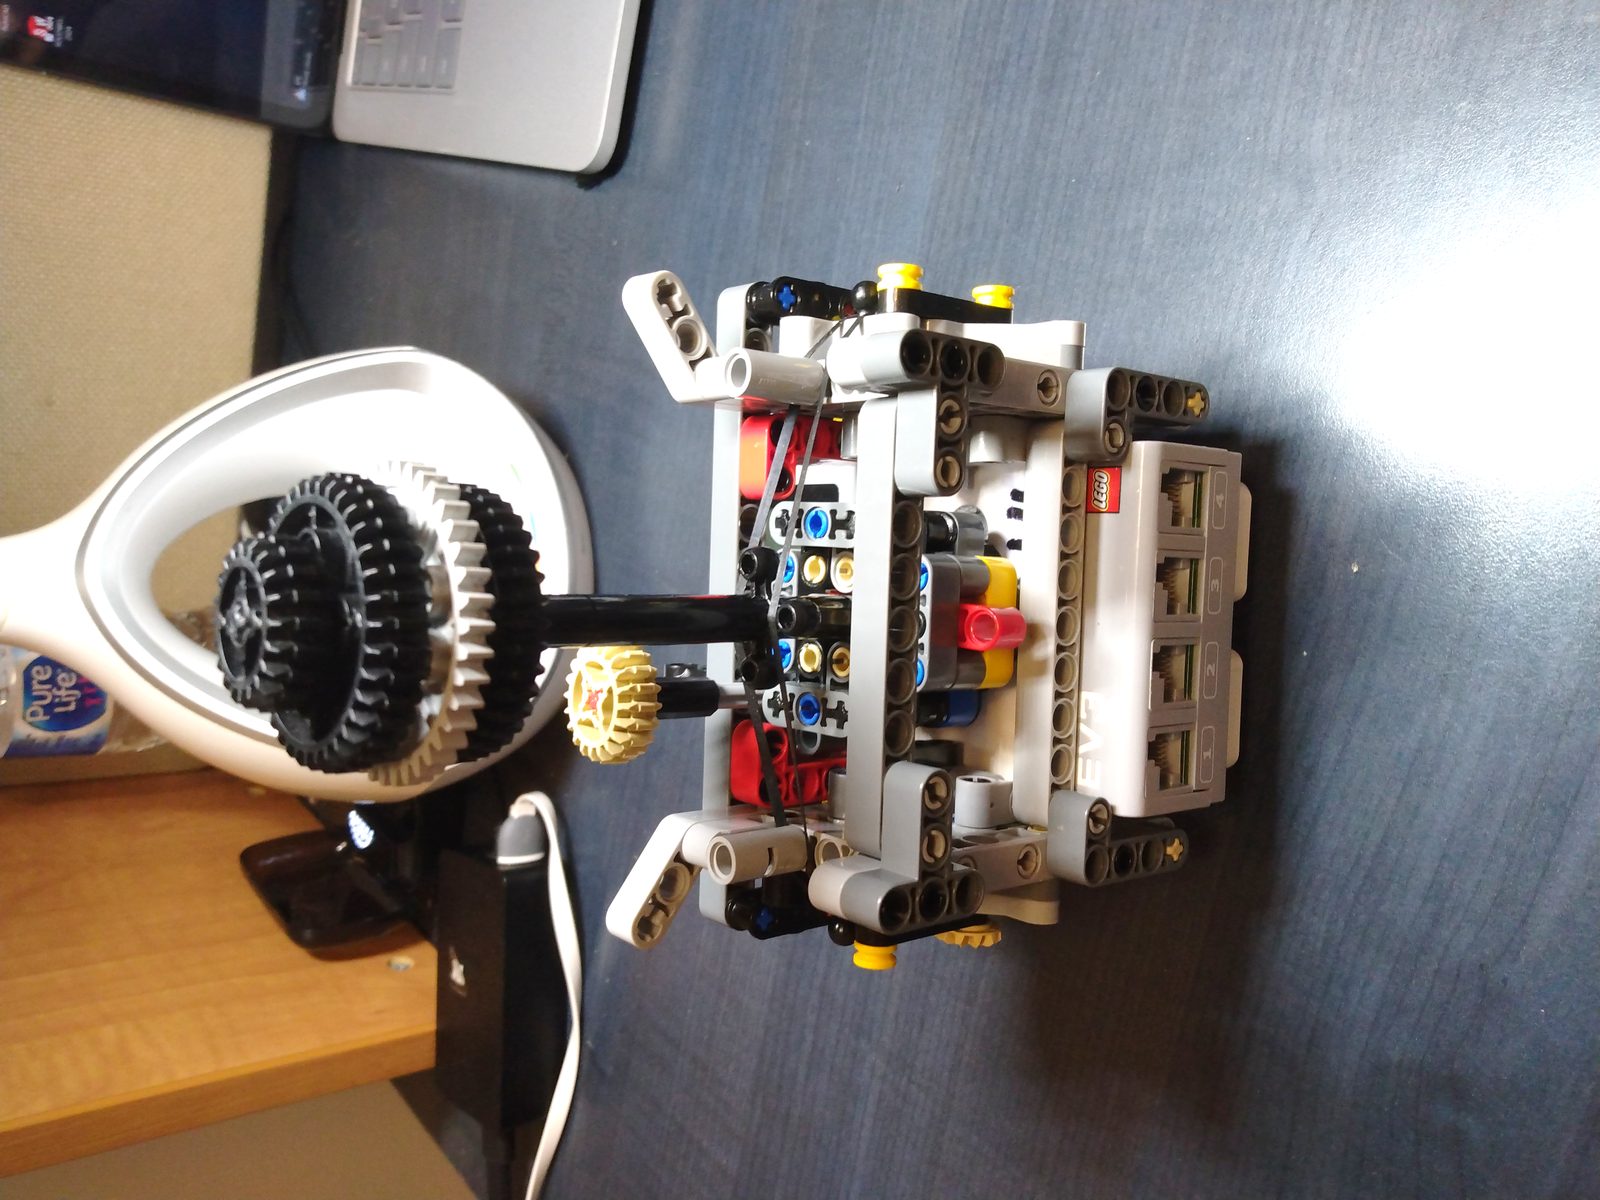
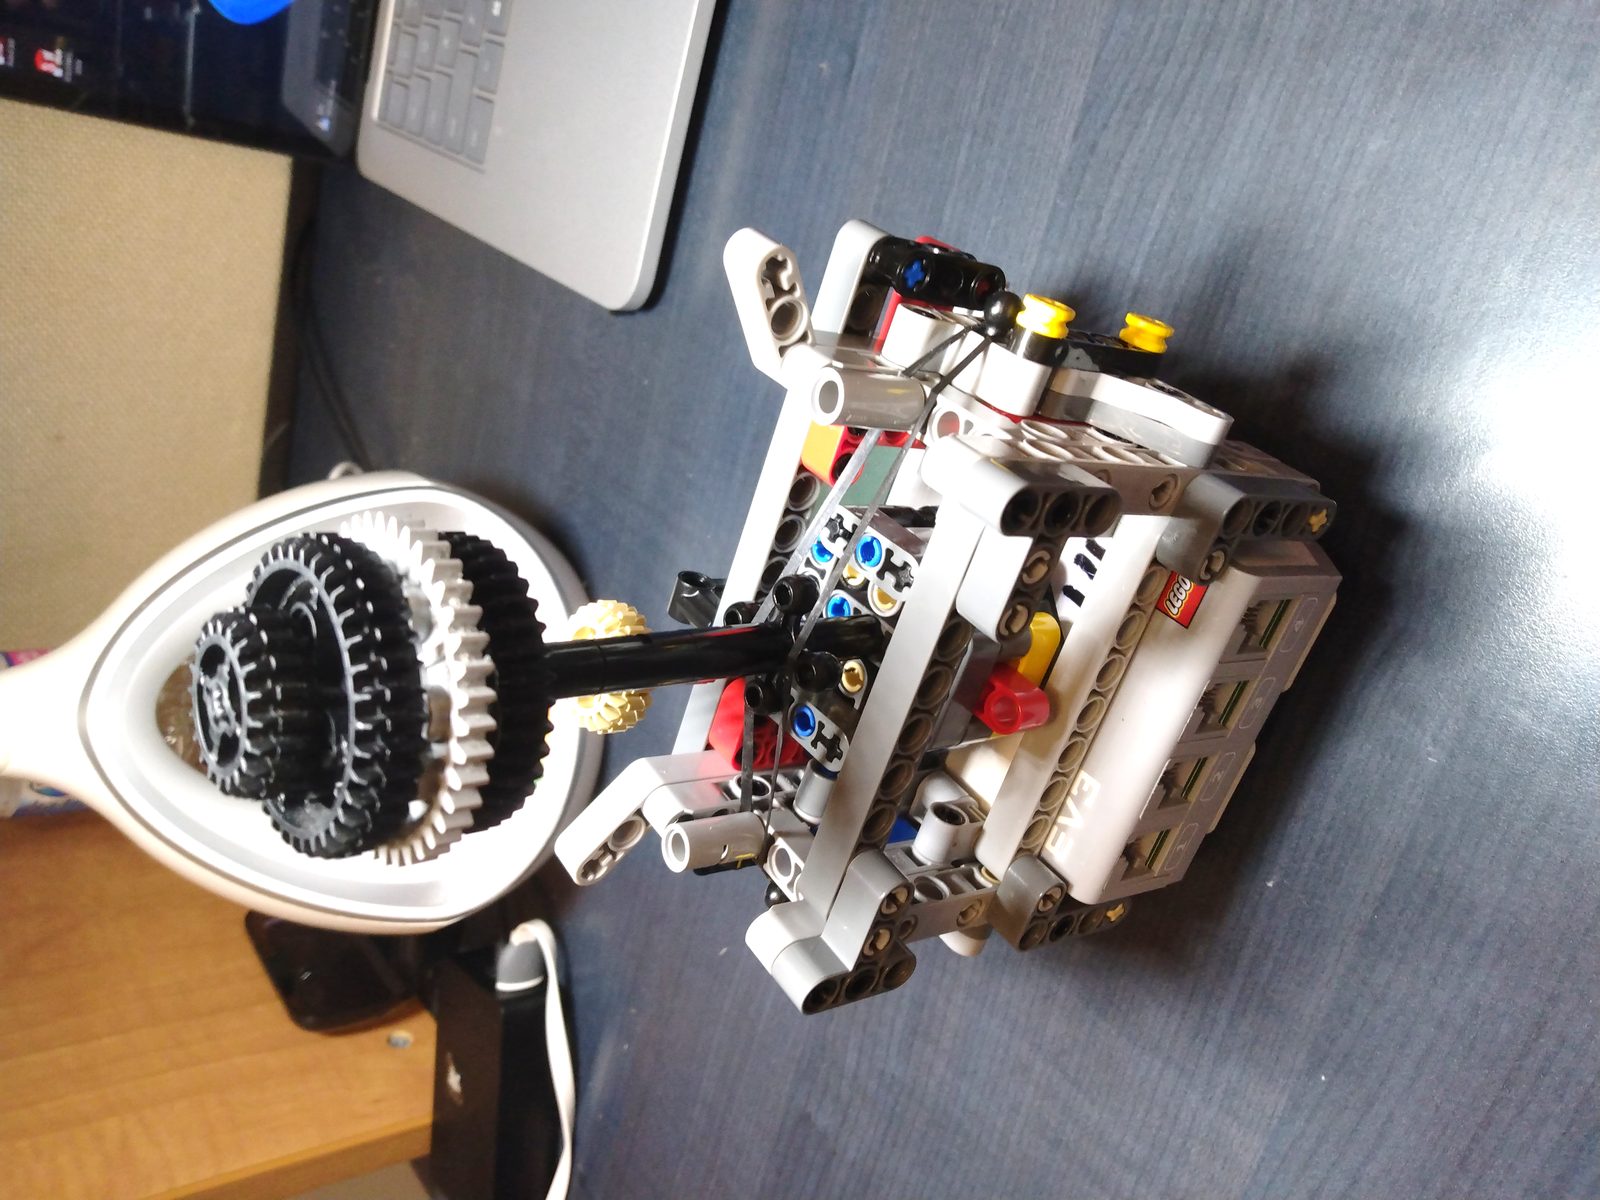
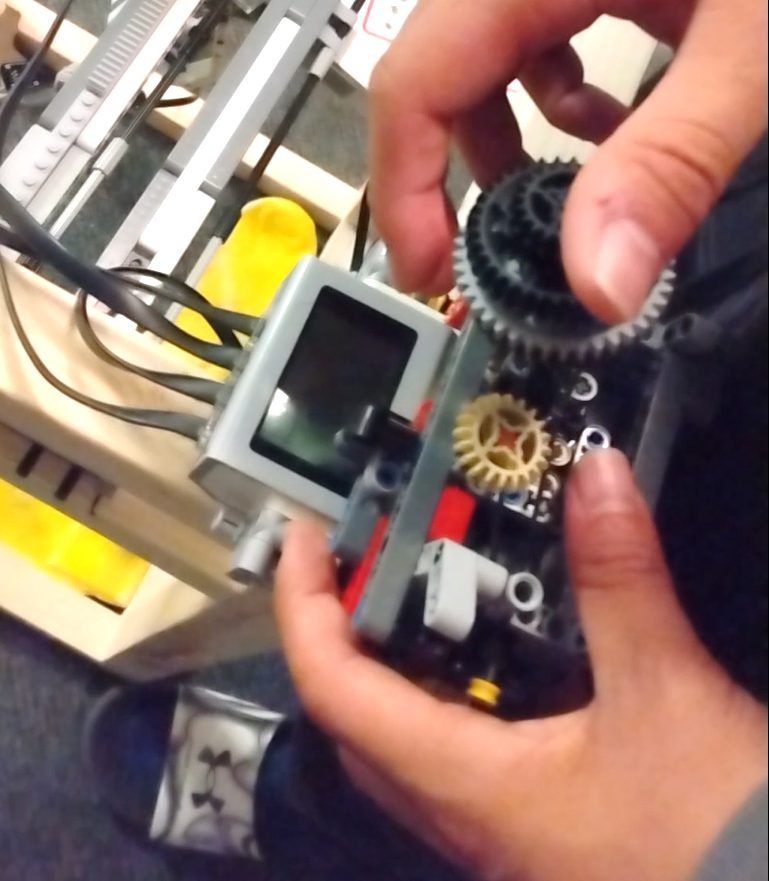
02.1 LEGO Gimbal Joystick Fabrication & Tactile Testing
Constructing physical joystick gimbal assembly from LEGO Technic elements, validating smooth return-to-center and tactile switch actuation.
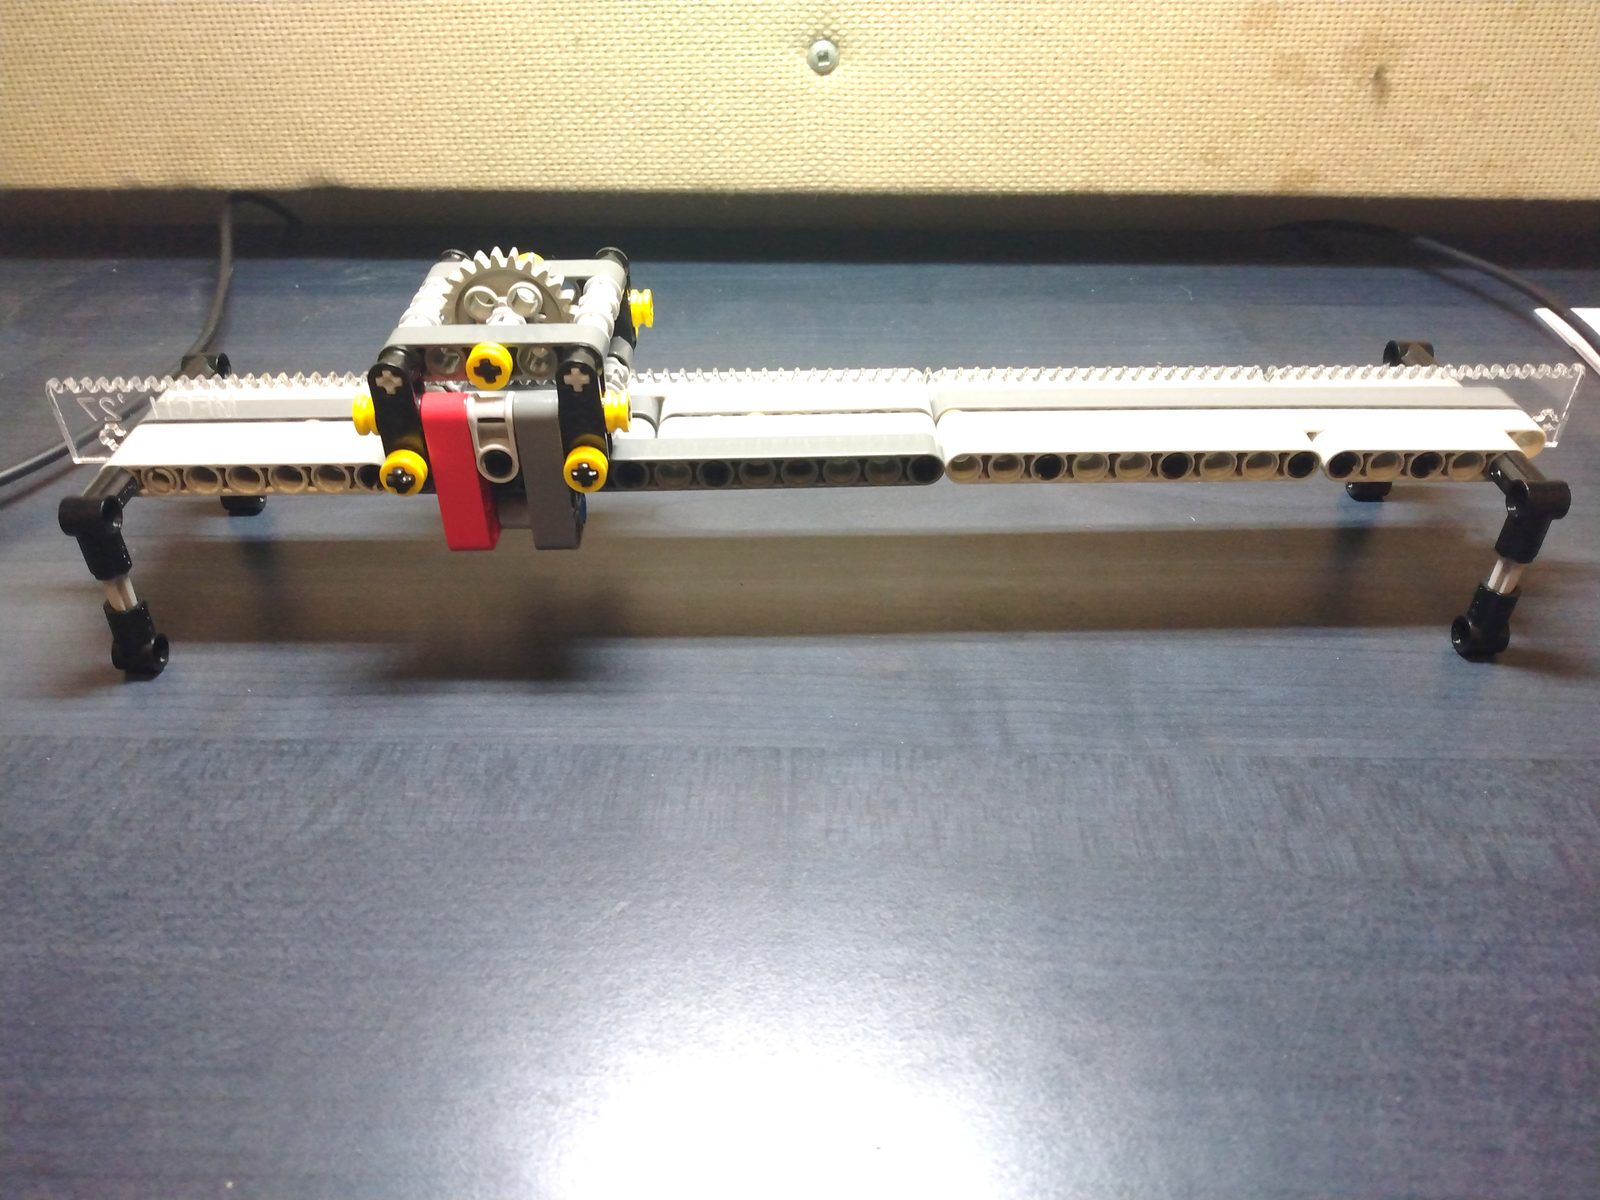
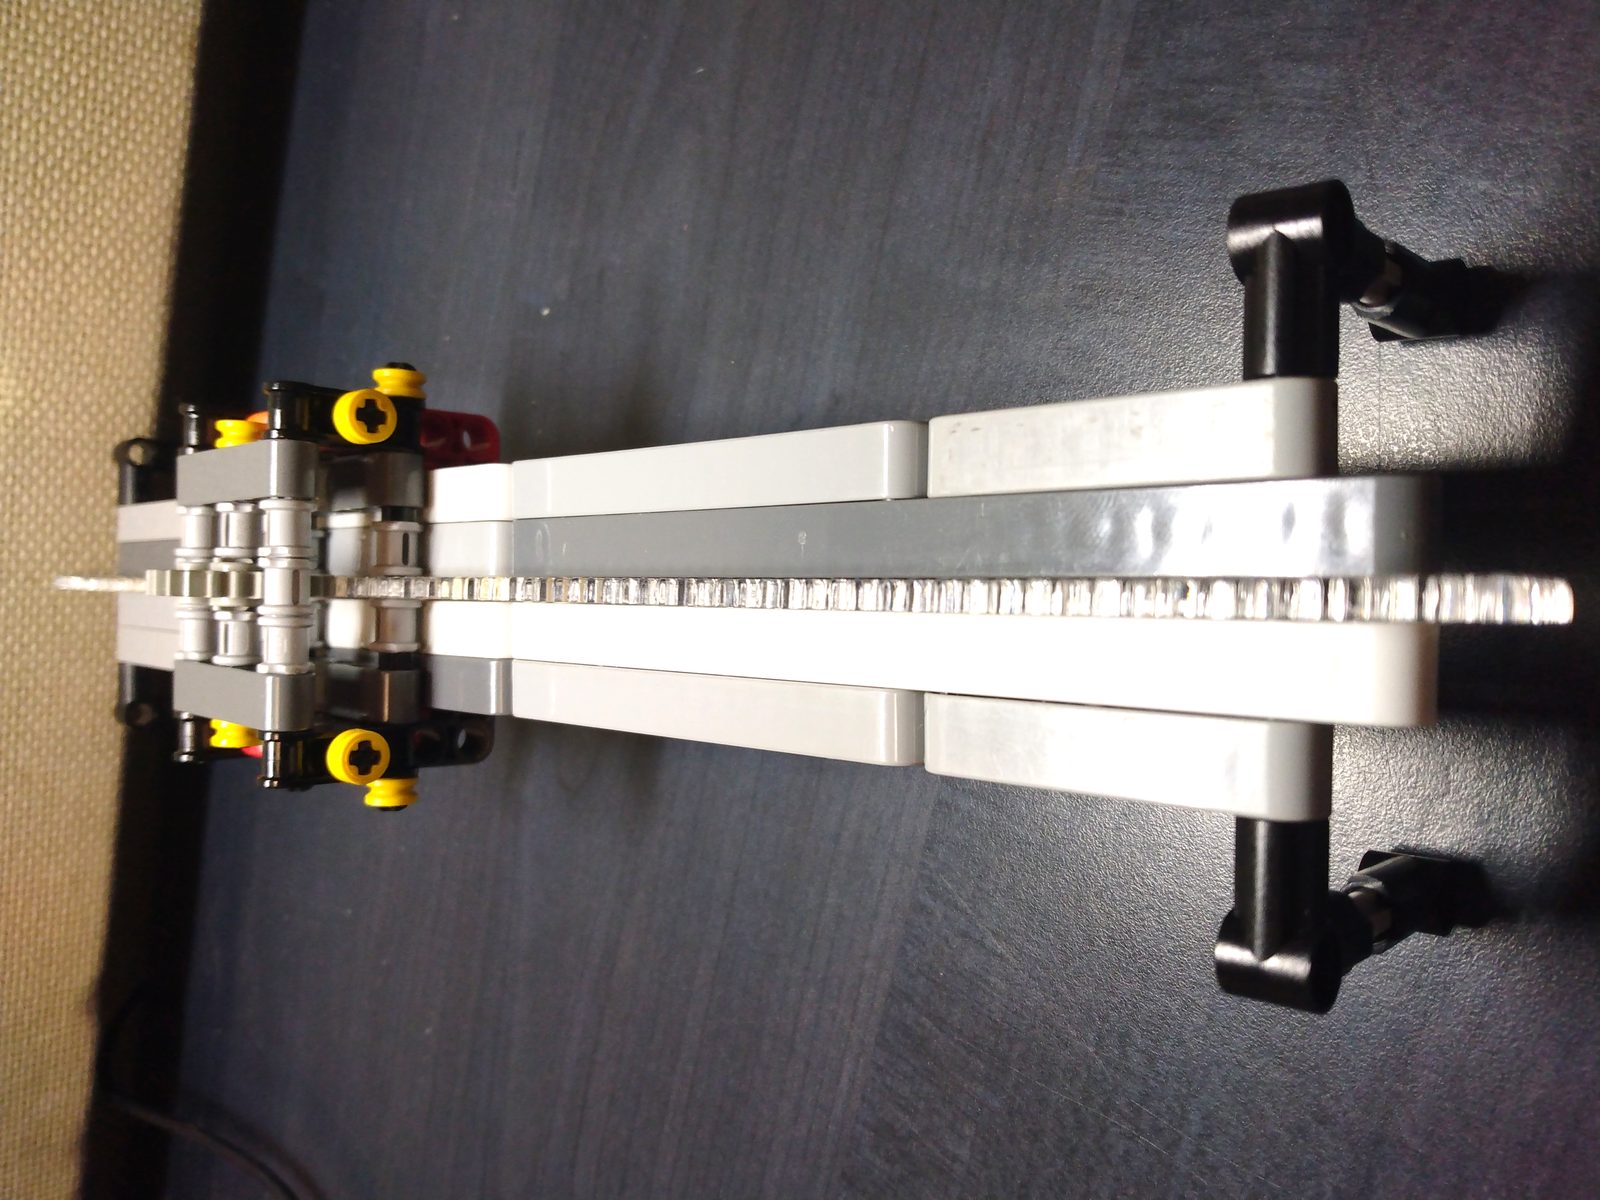
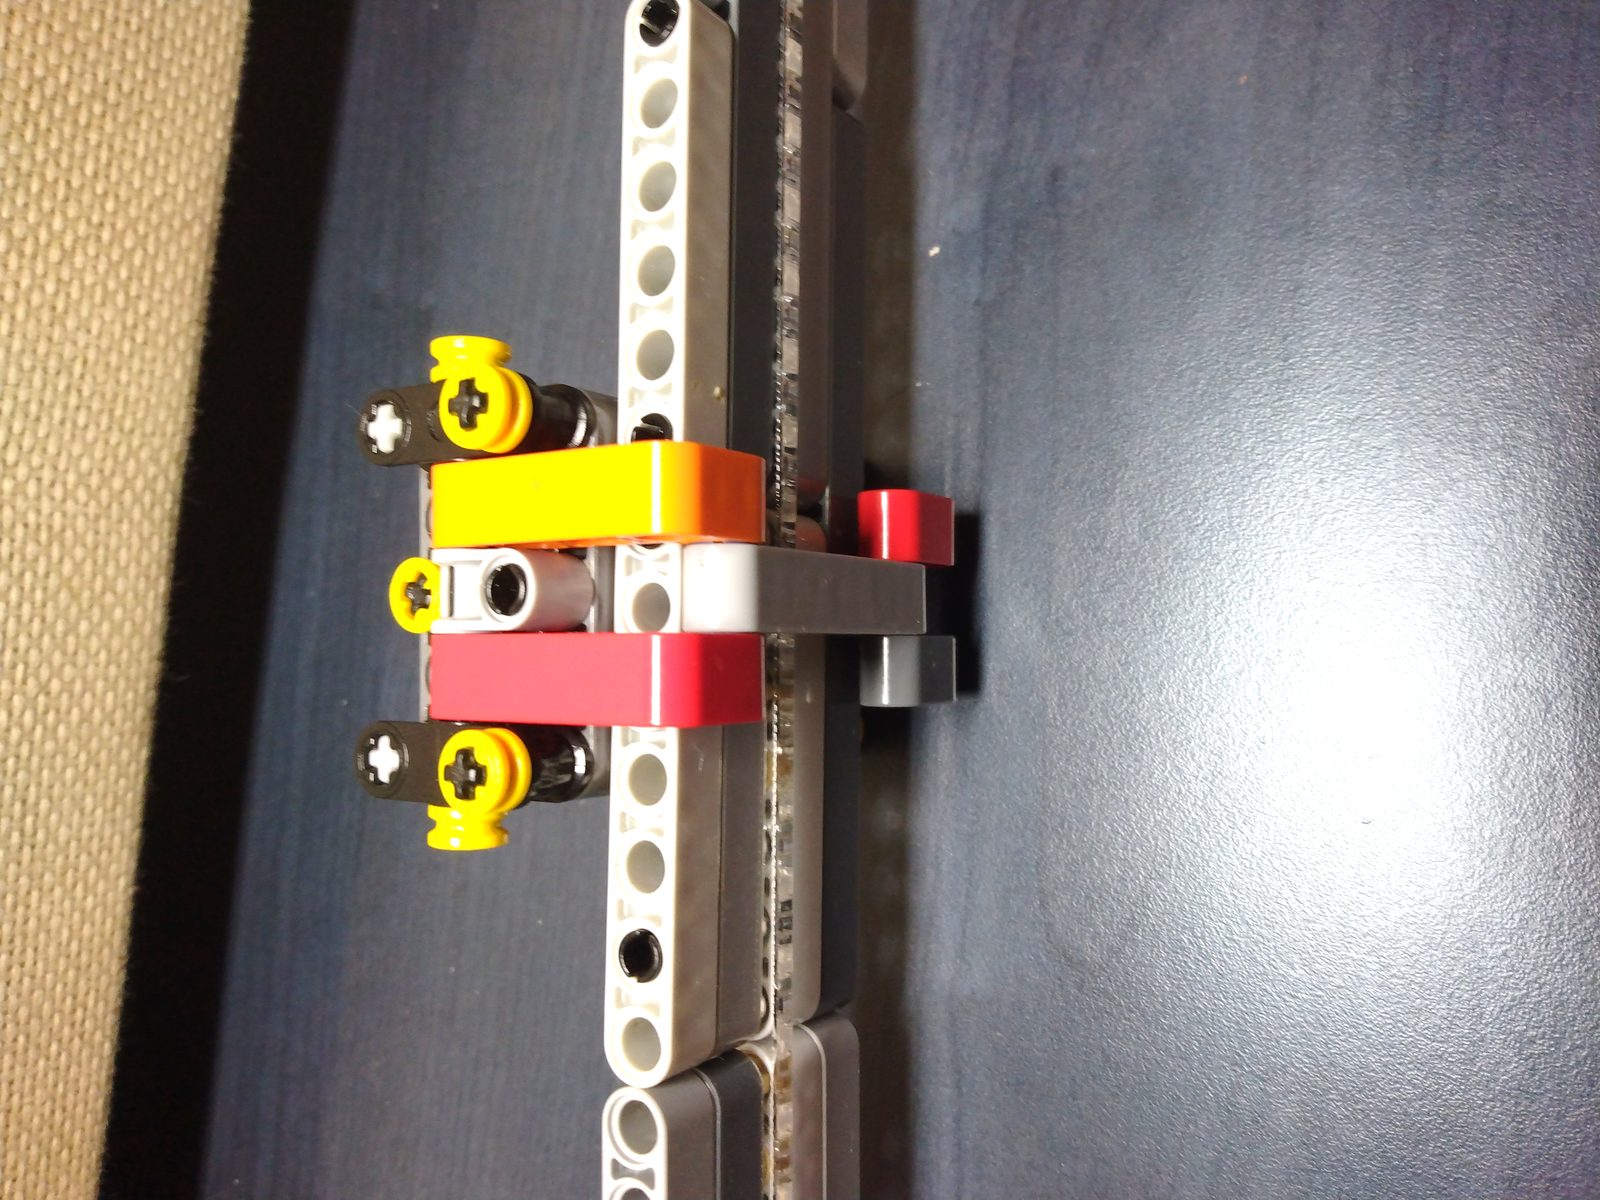
02.2 Cartesian Gantry Rails & Linear Axis Prototyping
Dual-axis motorized gantry carriage running along rigid linear guide rails for responsive XY positioning over the prize bay.
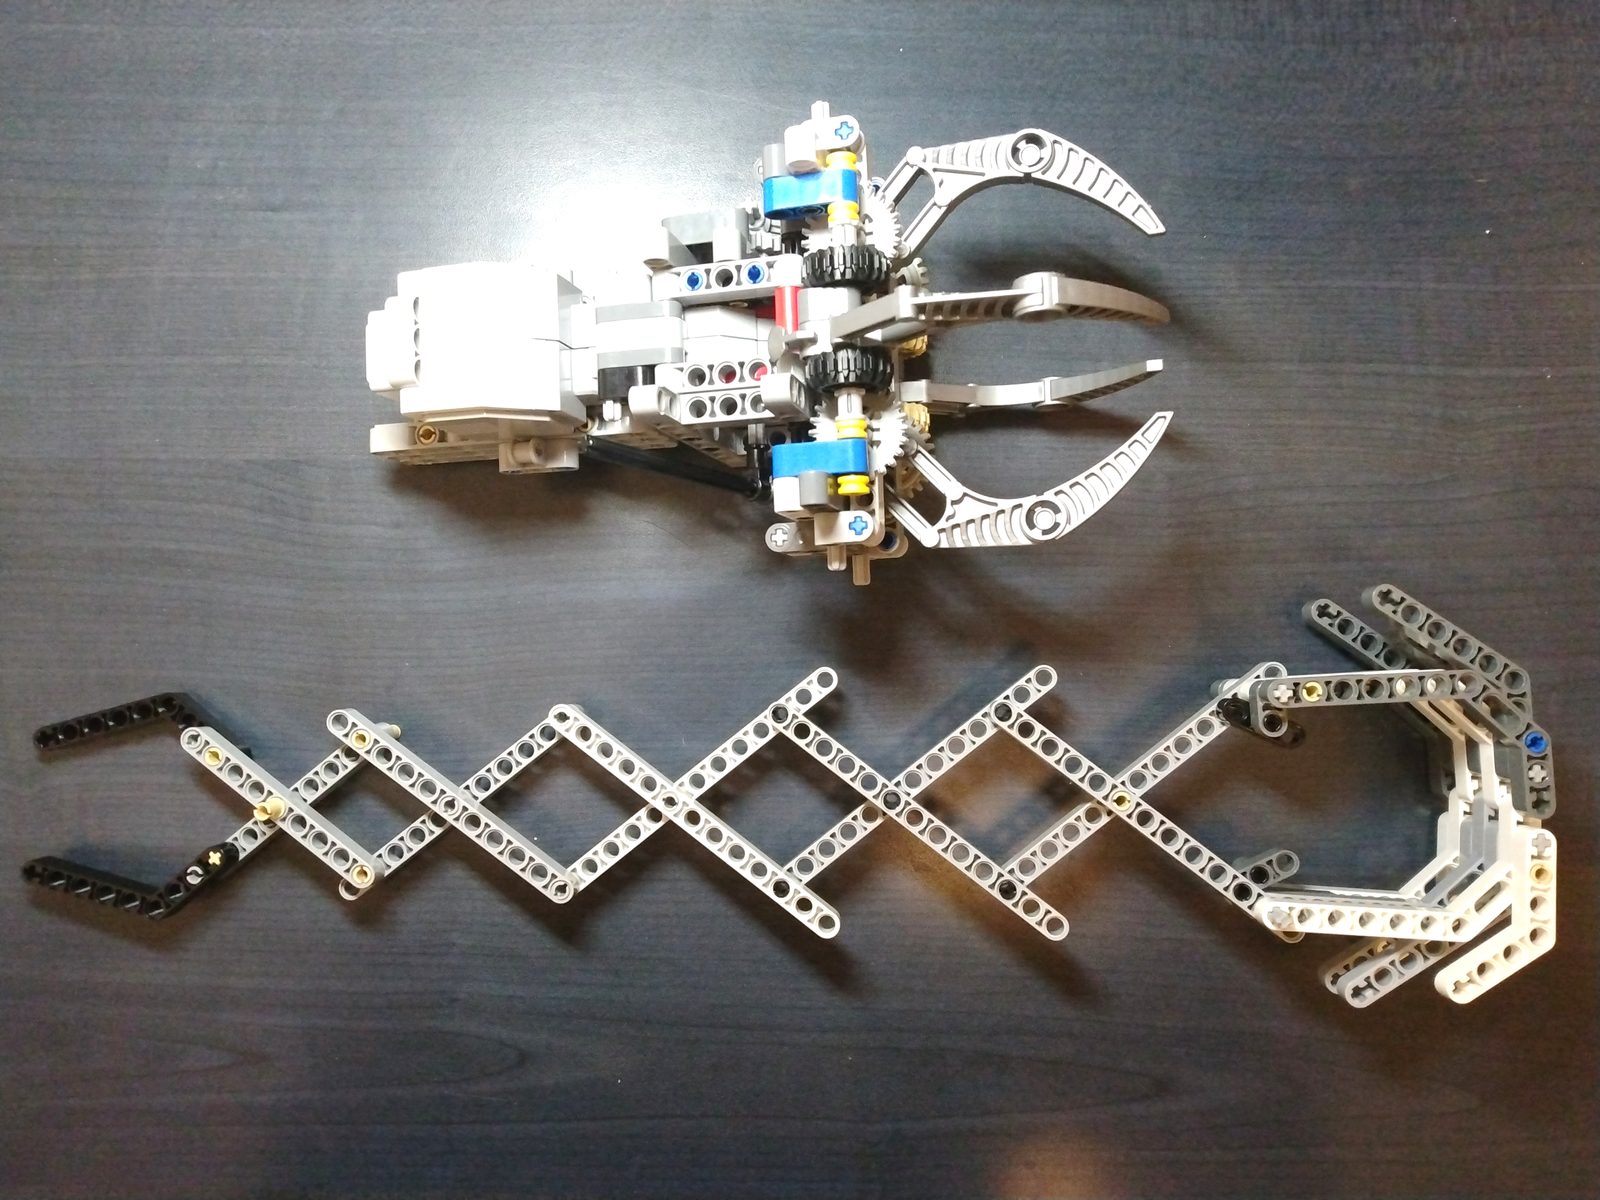
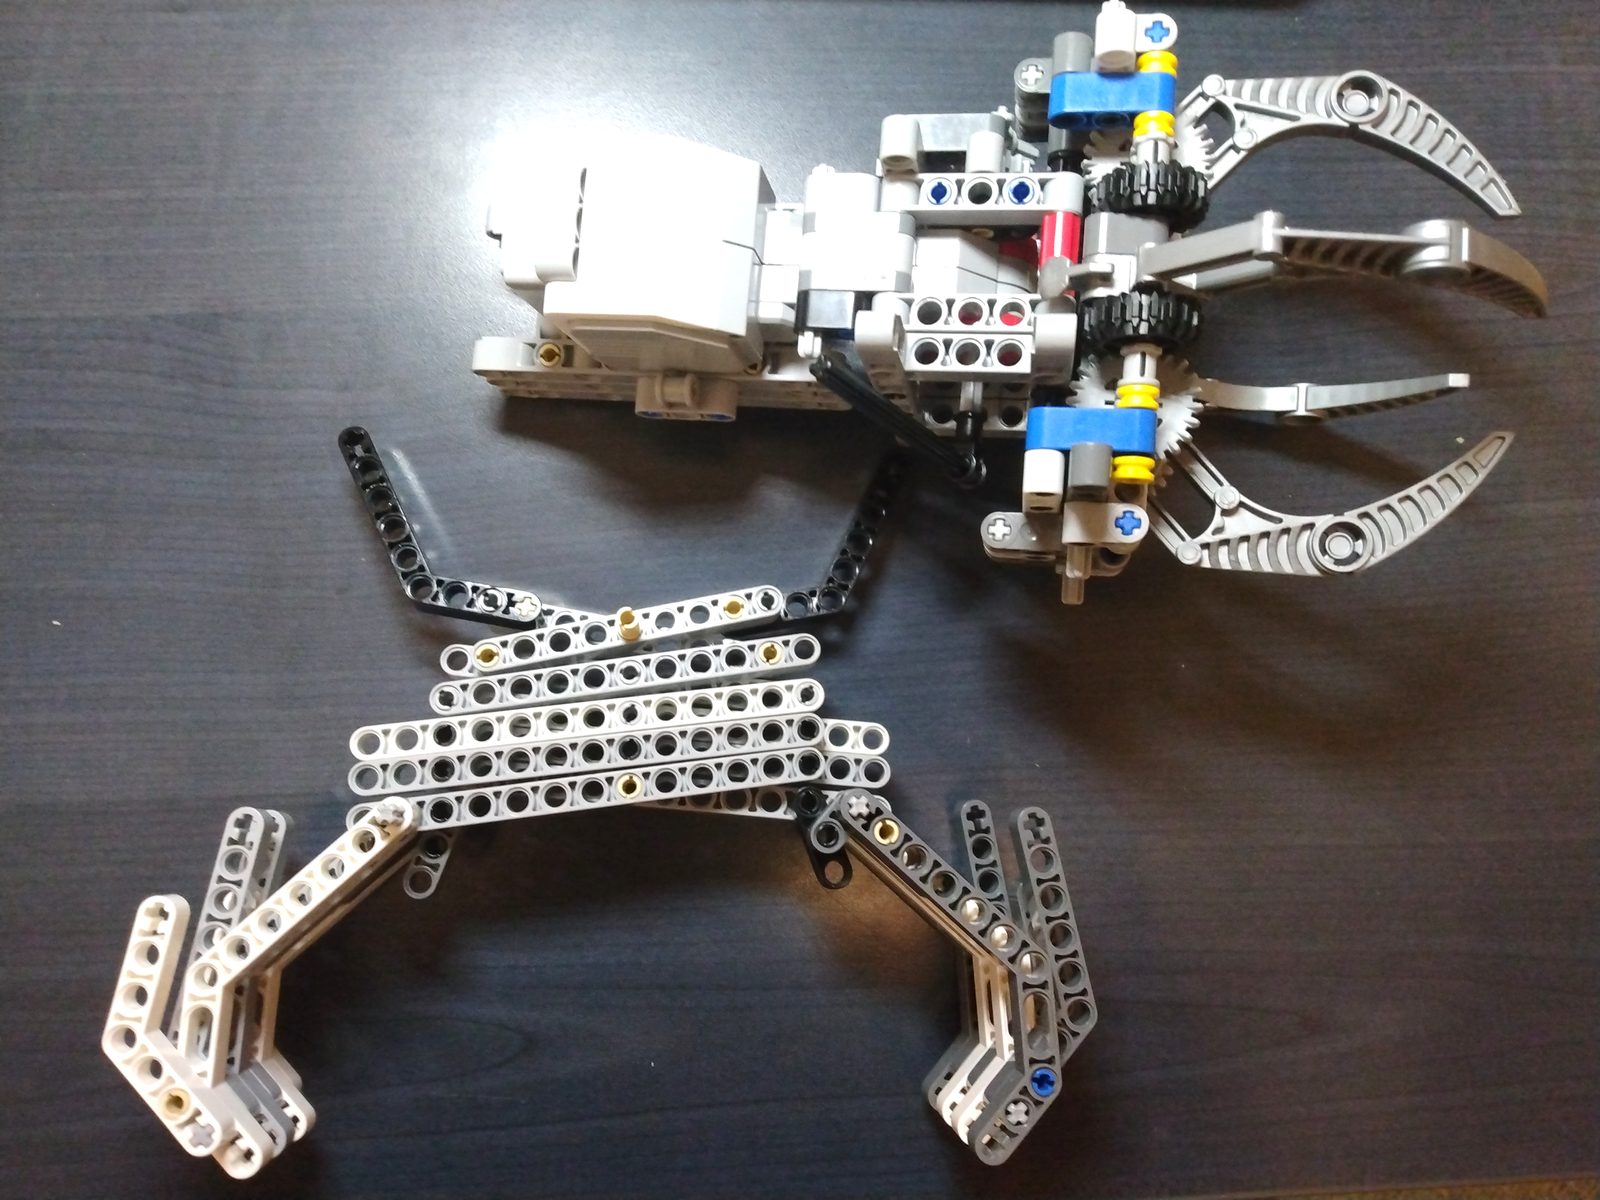
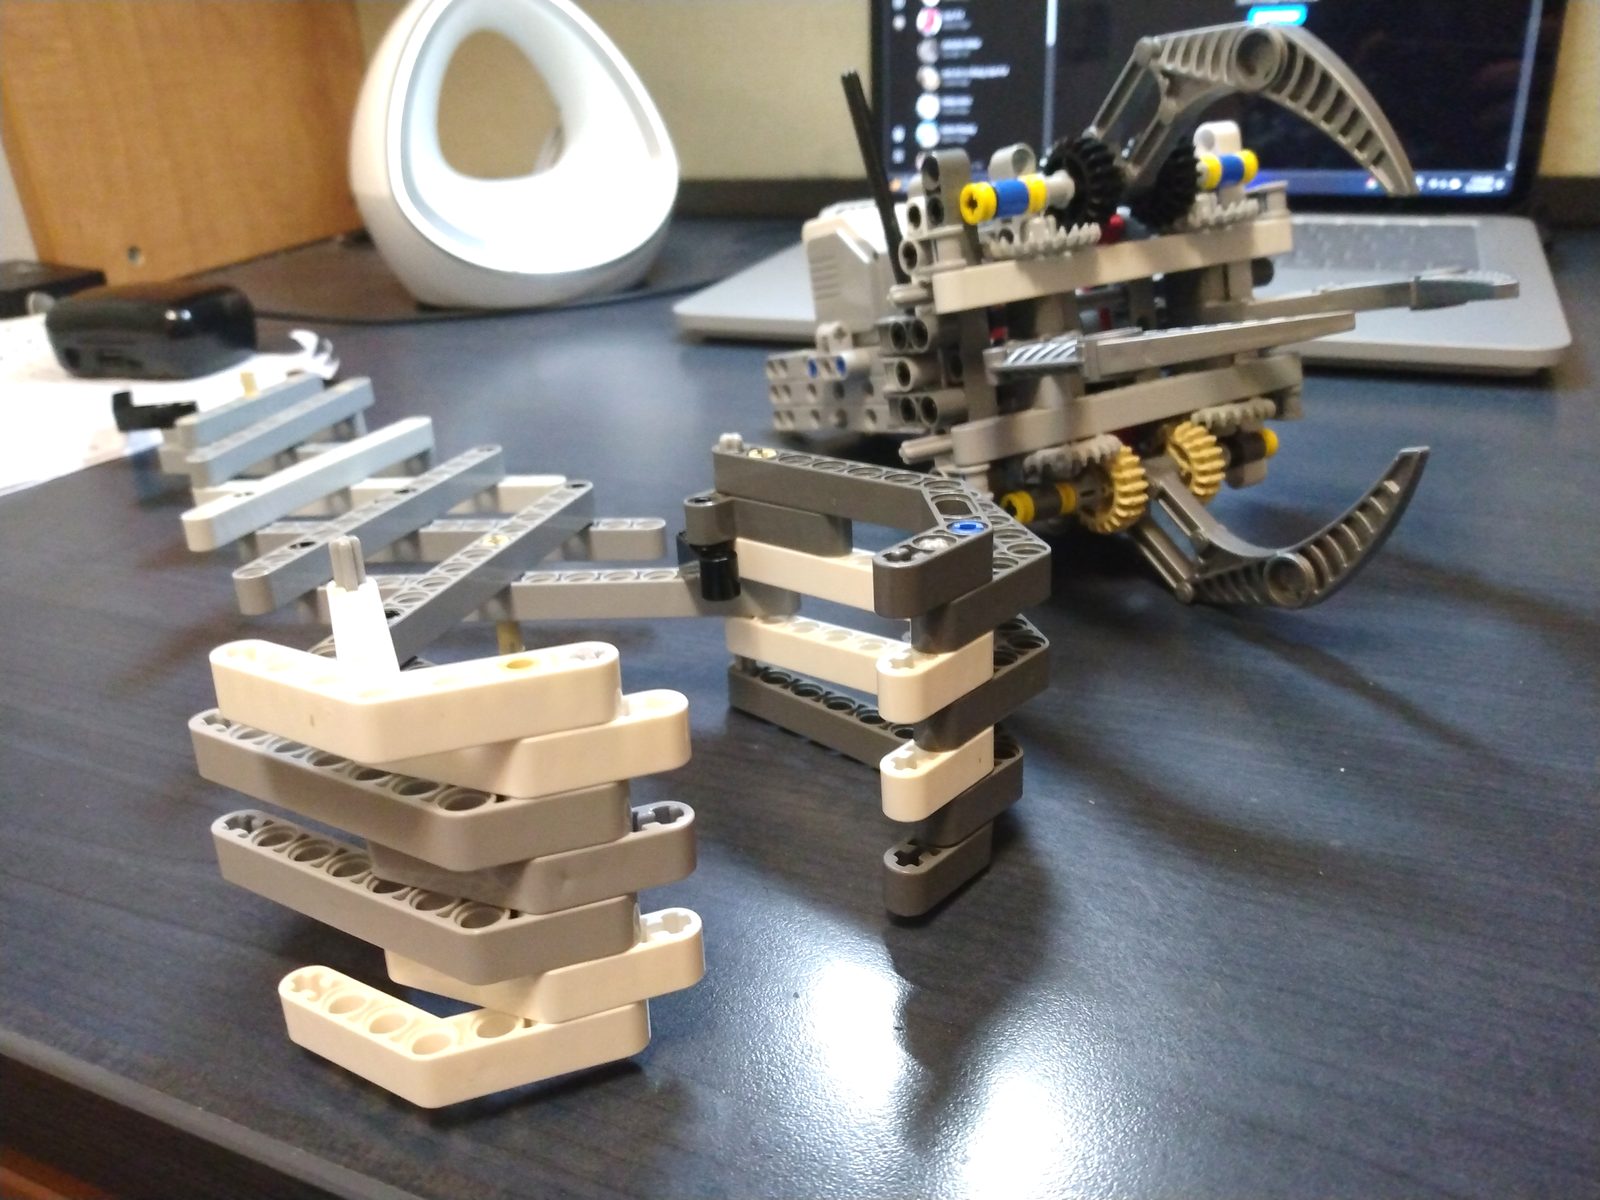
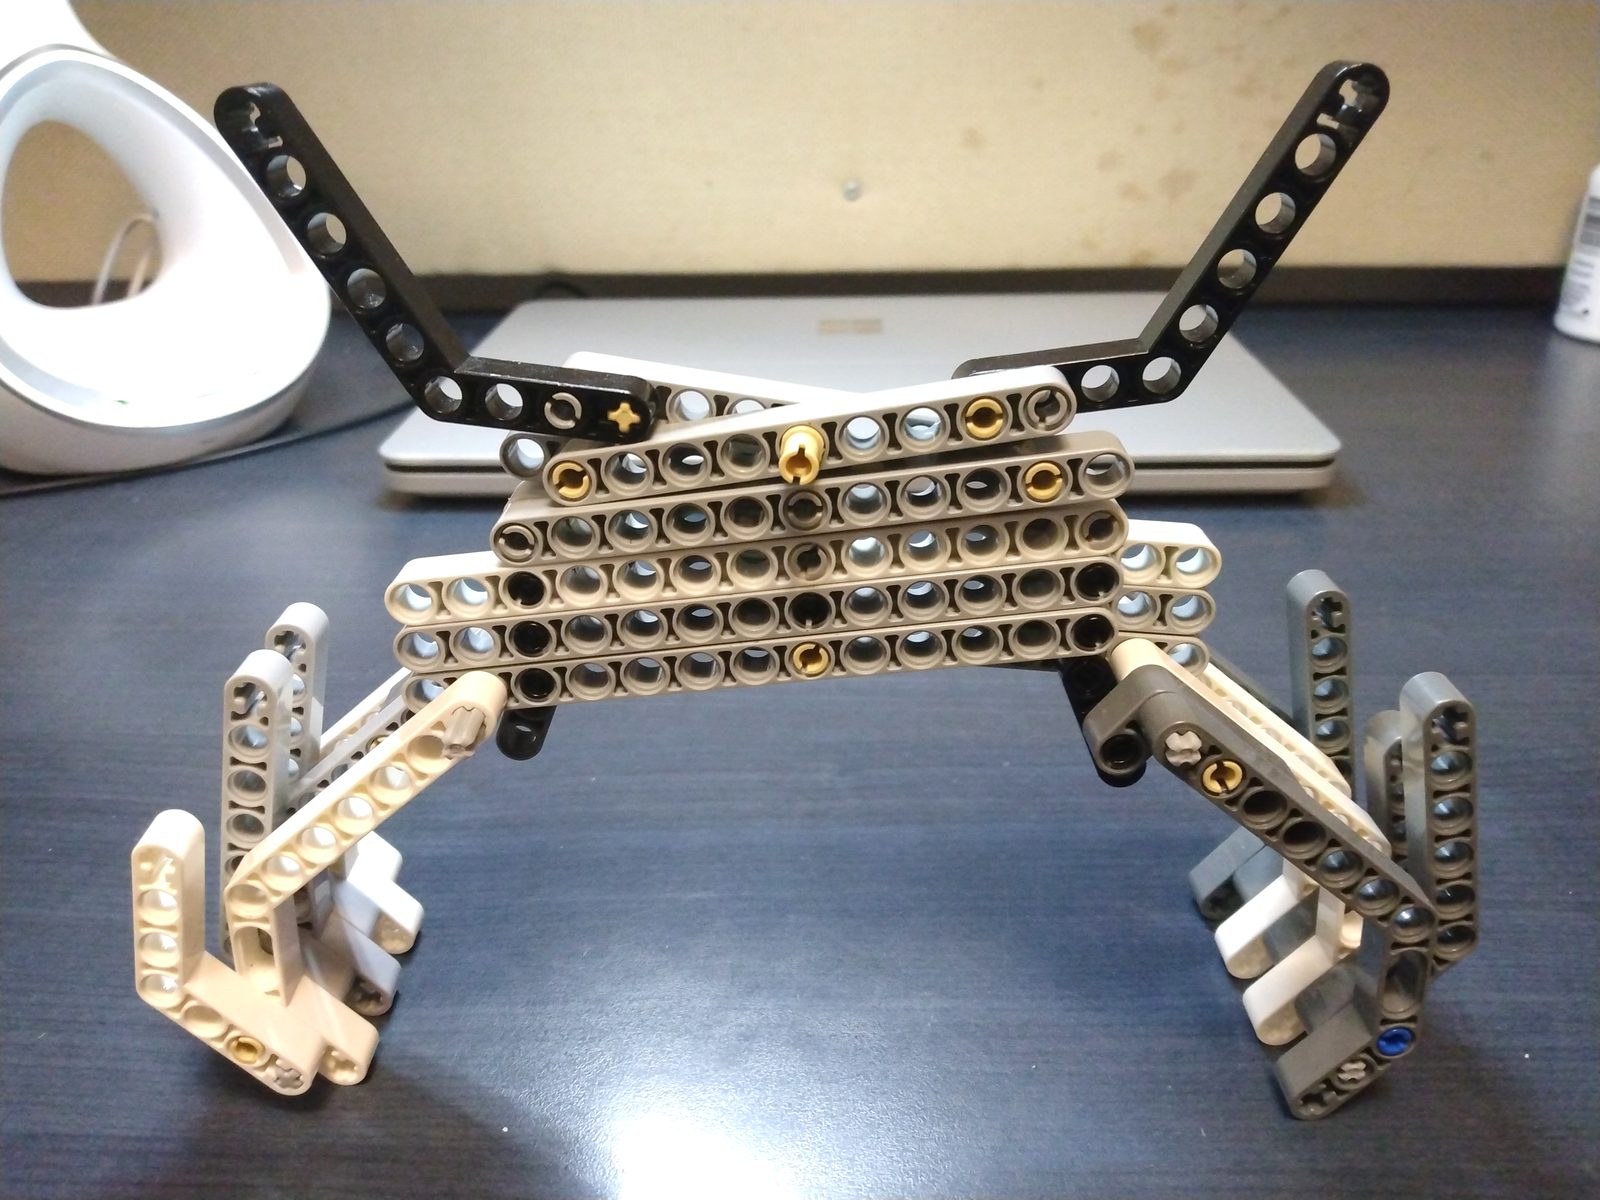
02.3 Claw Gripper Prototypes & Kinematic Evolution
Iterating through single-motor vs dual-motor claws, evaluating four-finger vs two-finger designs for grip strength and payload stability.
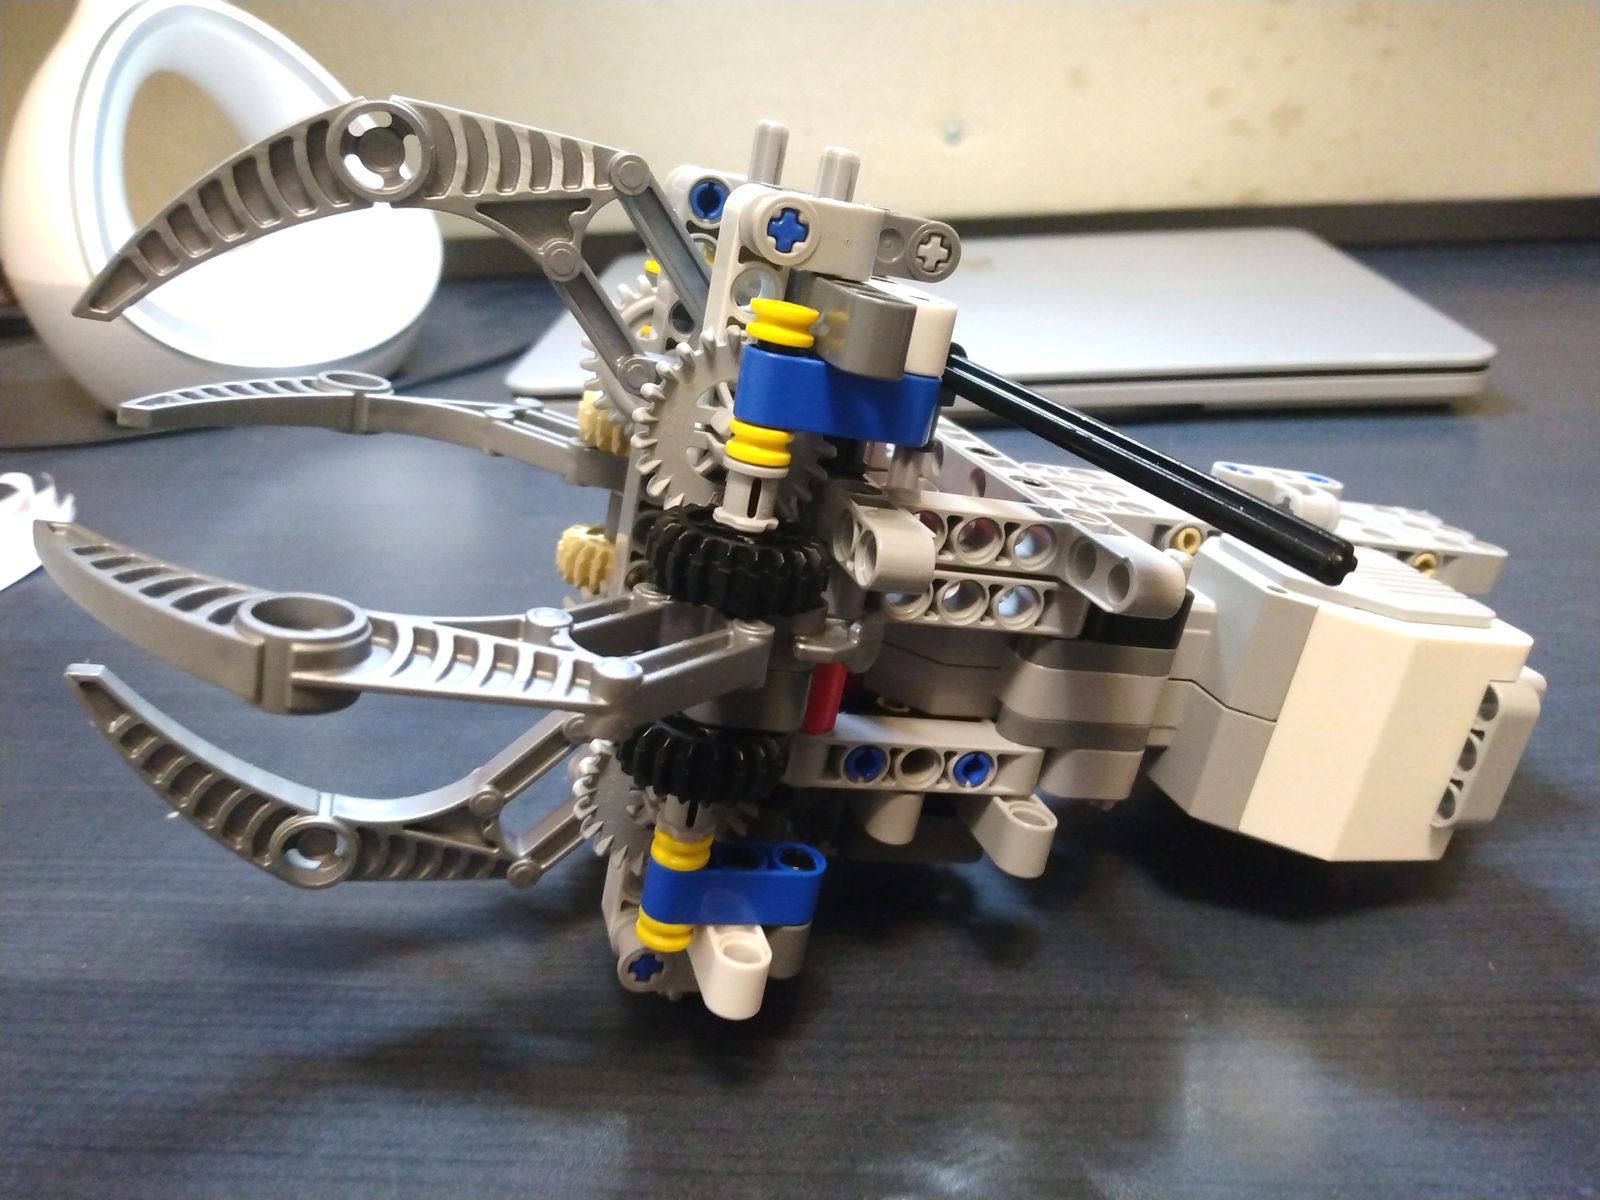
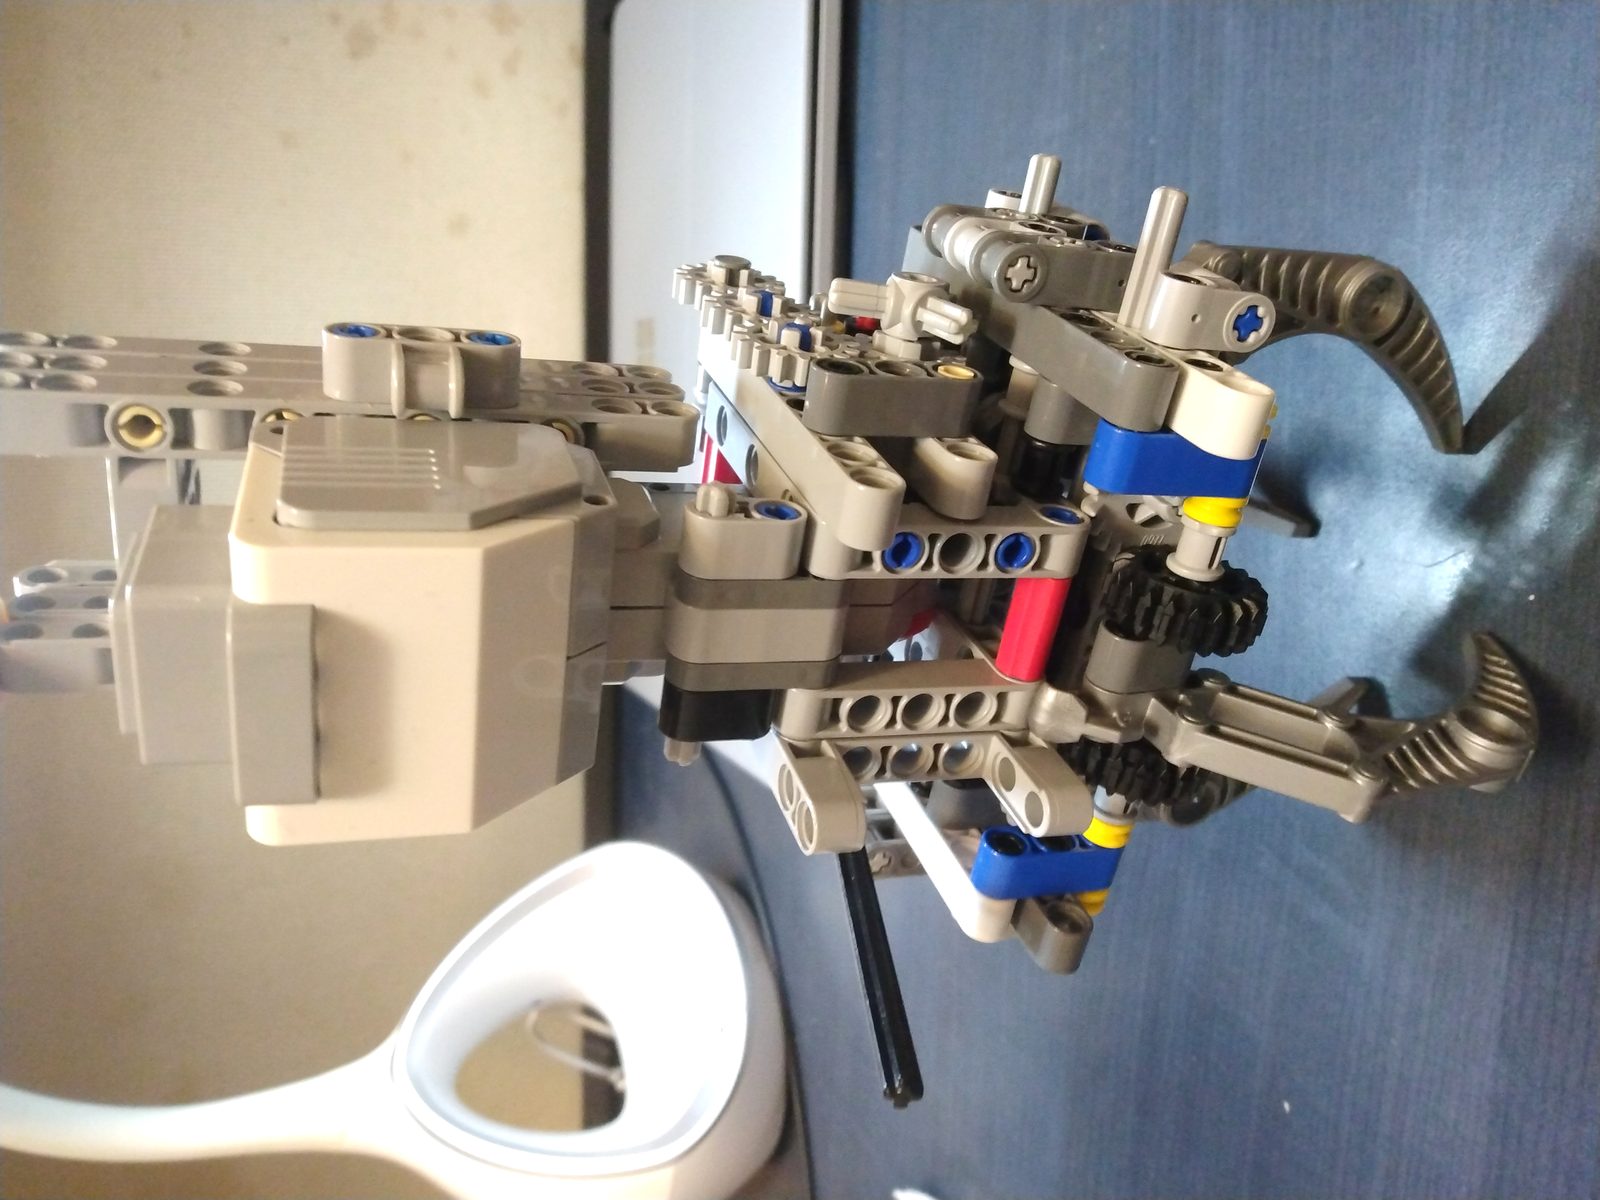
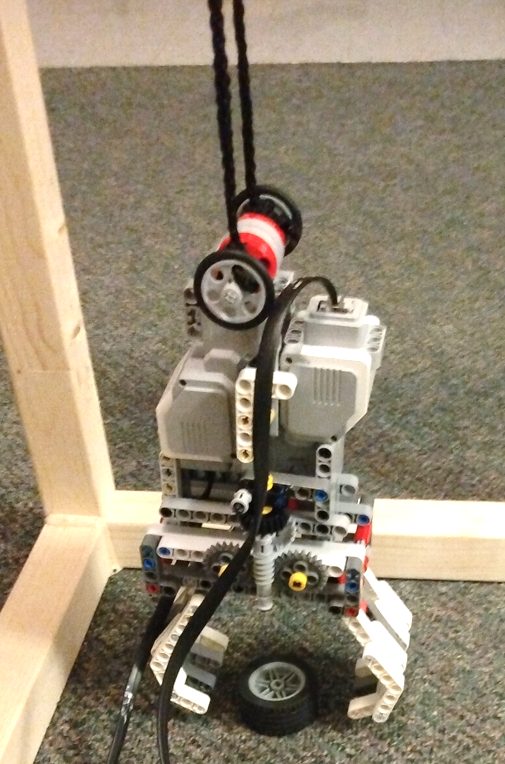
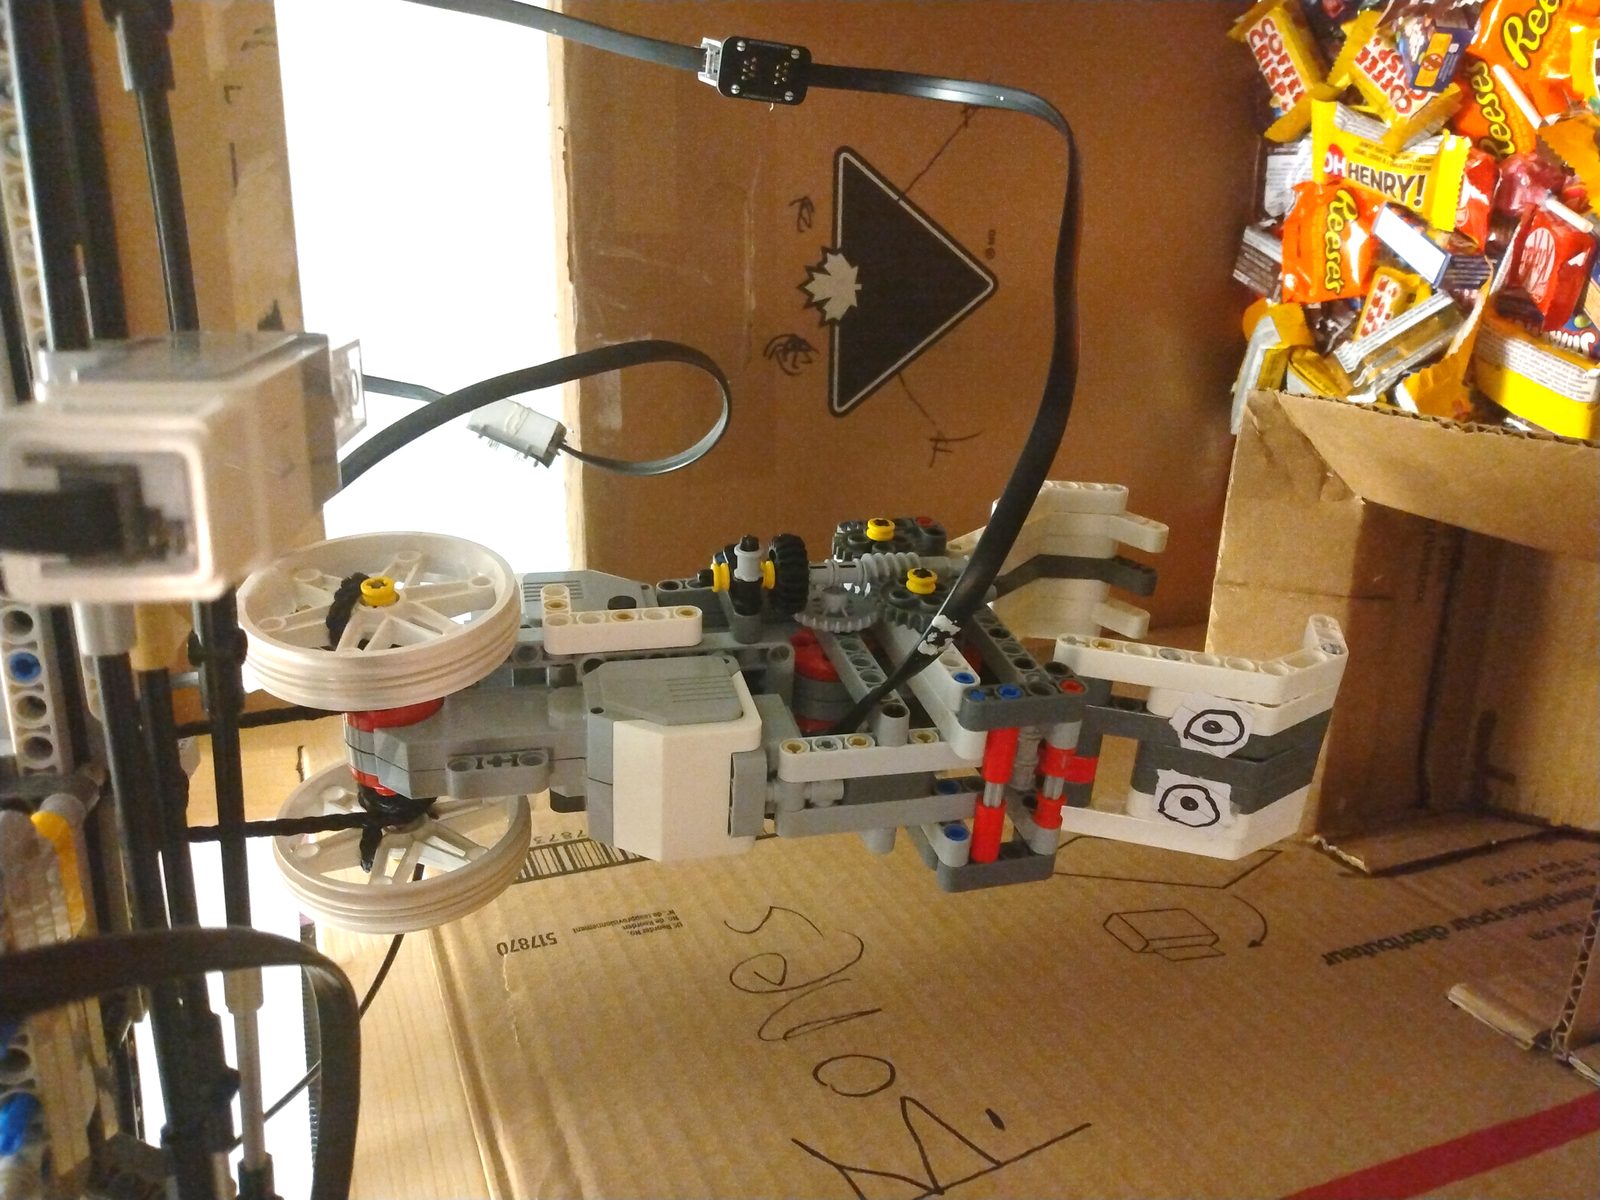
02.4 Dual-Motor Articulated Claw & Pulley Winch Rig
Final winning design featuring independent motors for vertical hoist drop and articulated claw gripping with high-friction silicone pads.
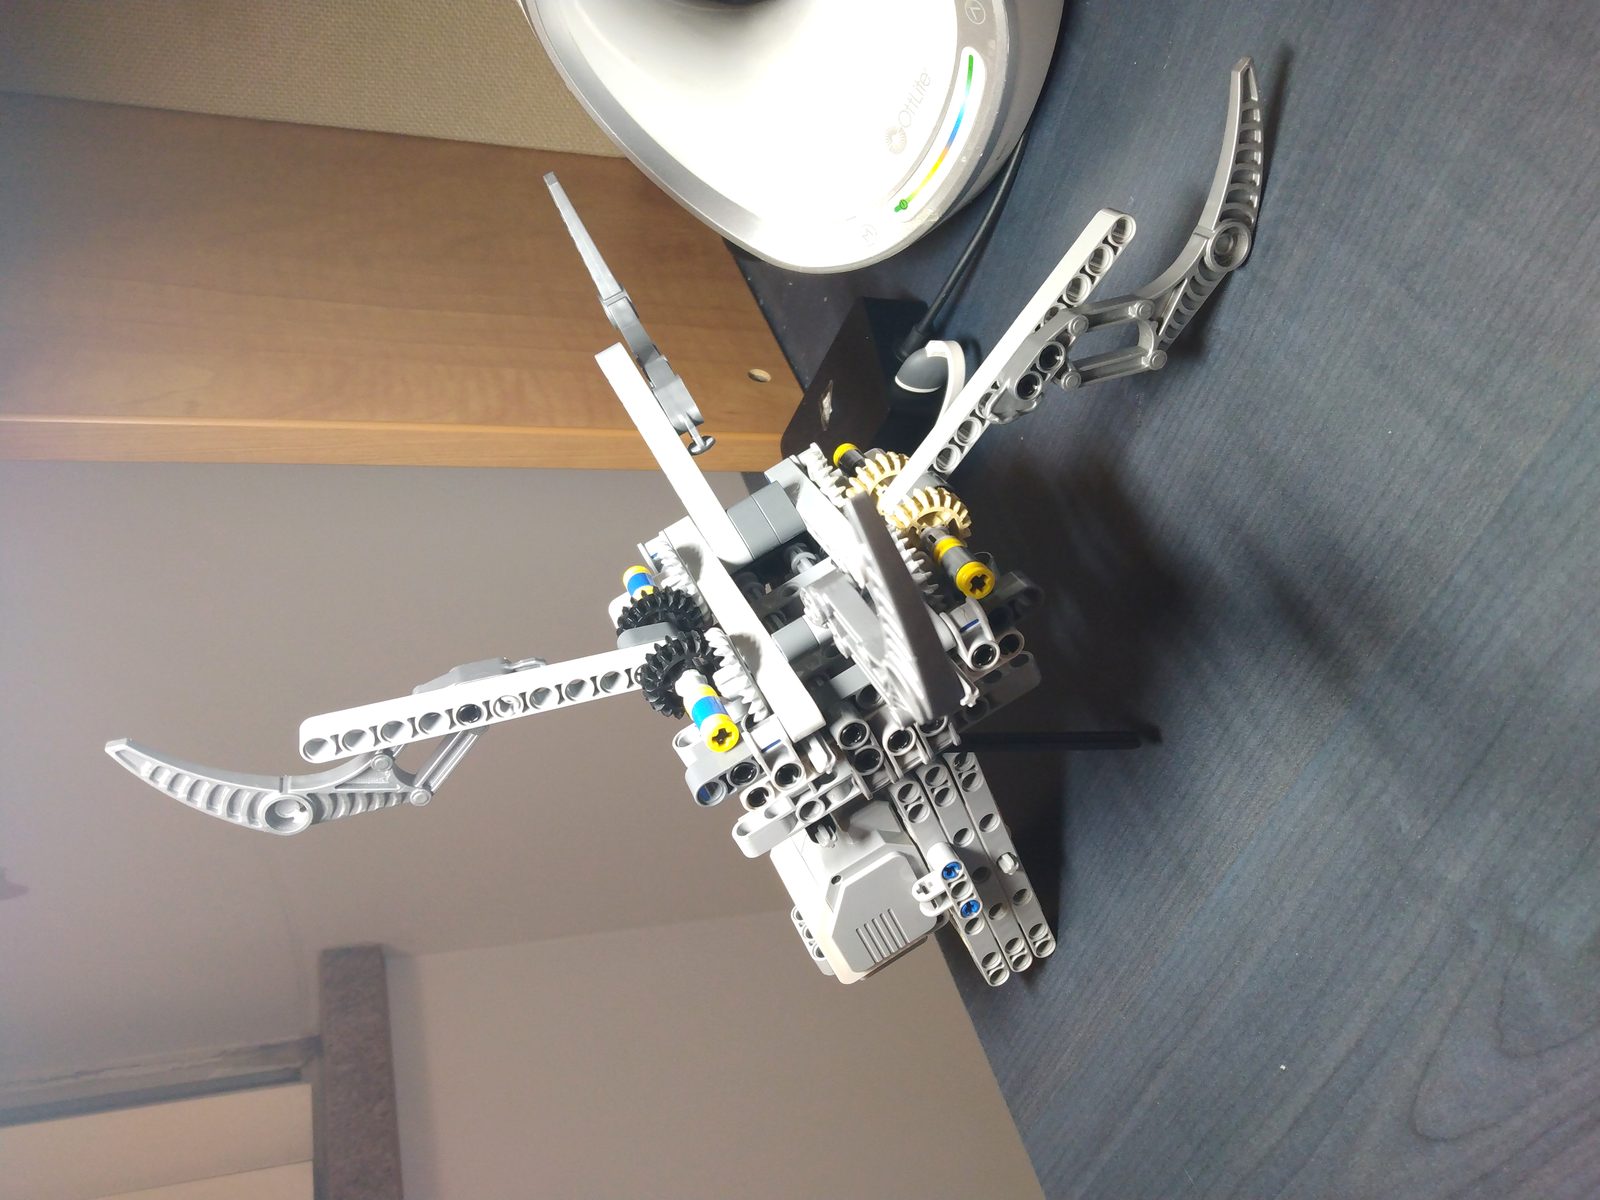
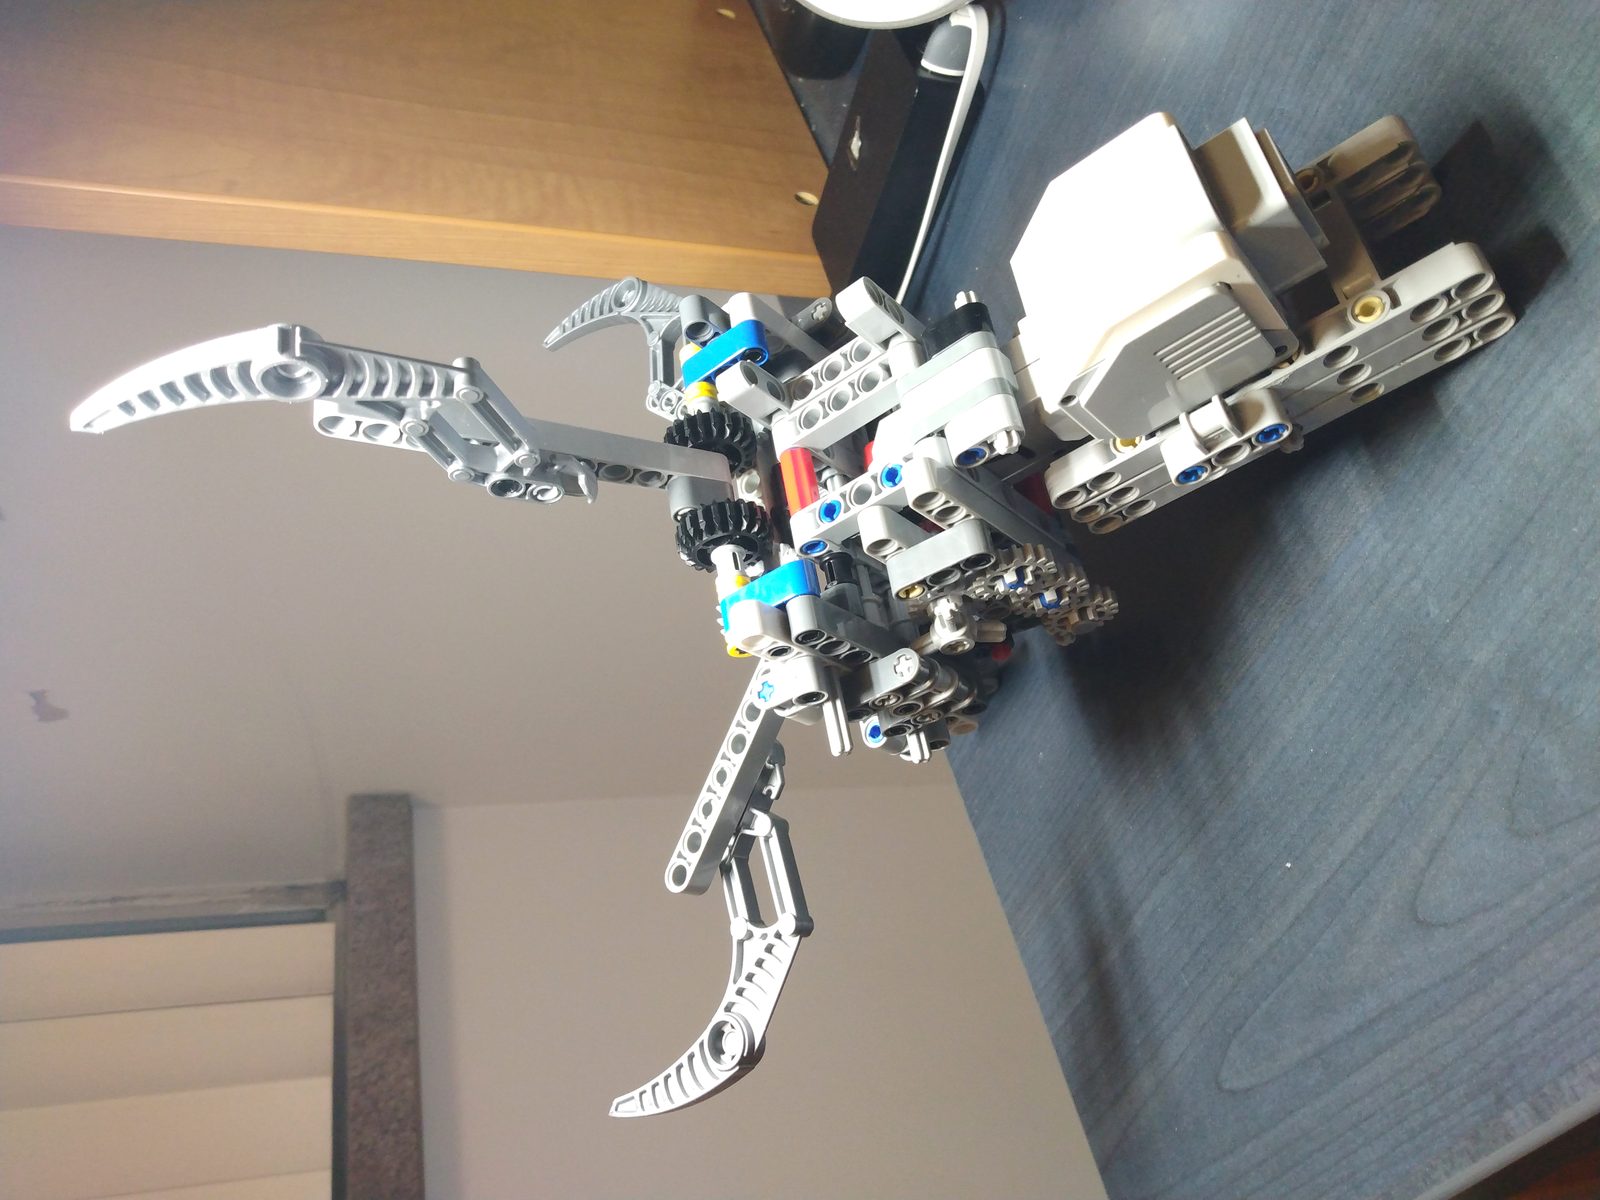
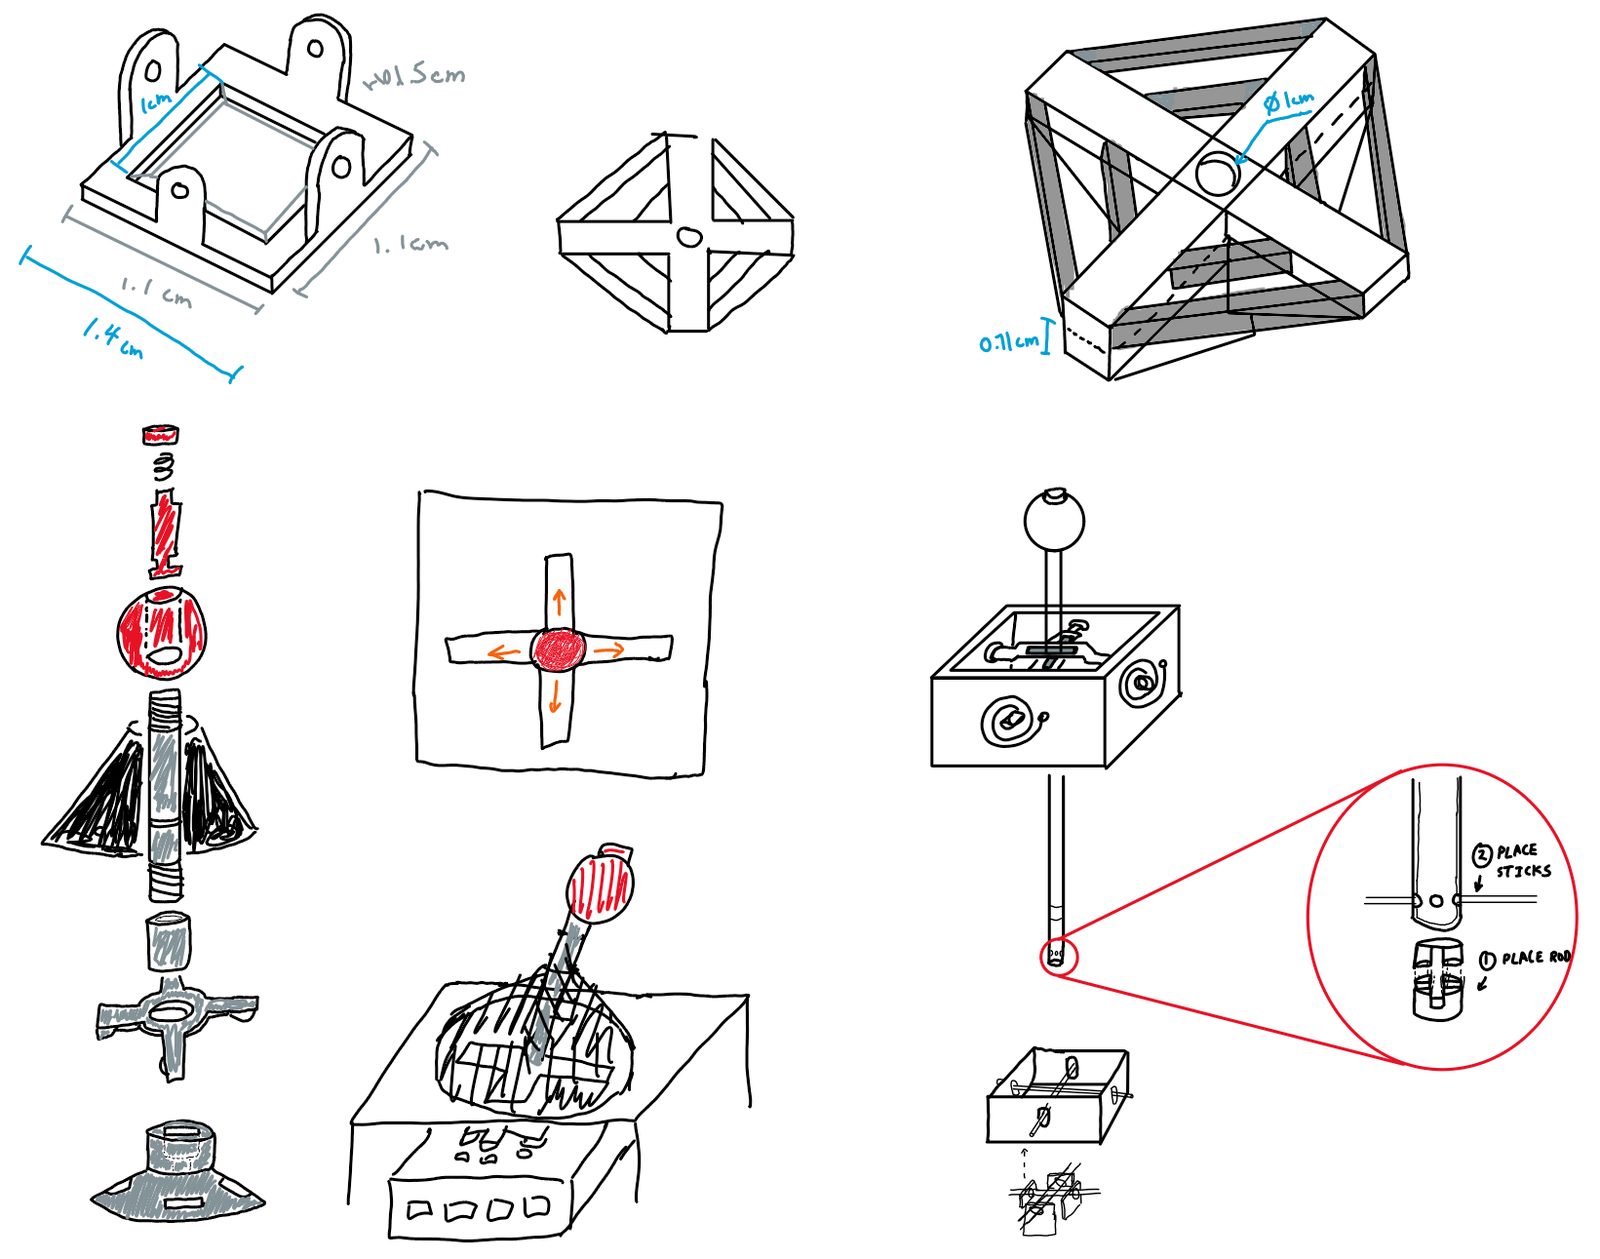
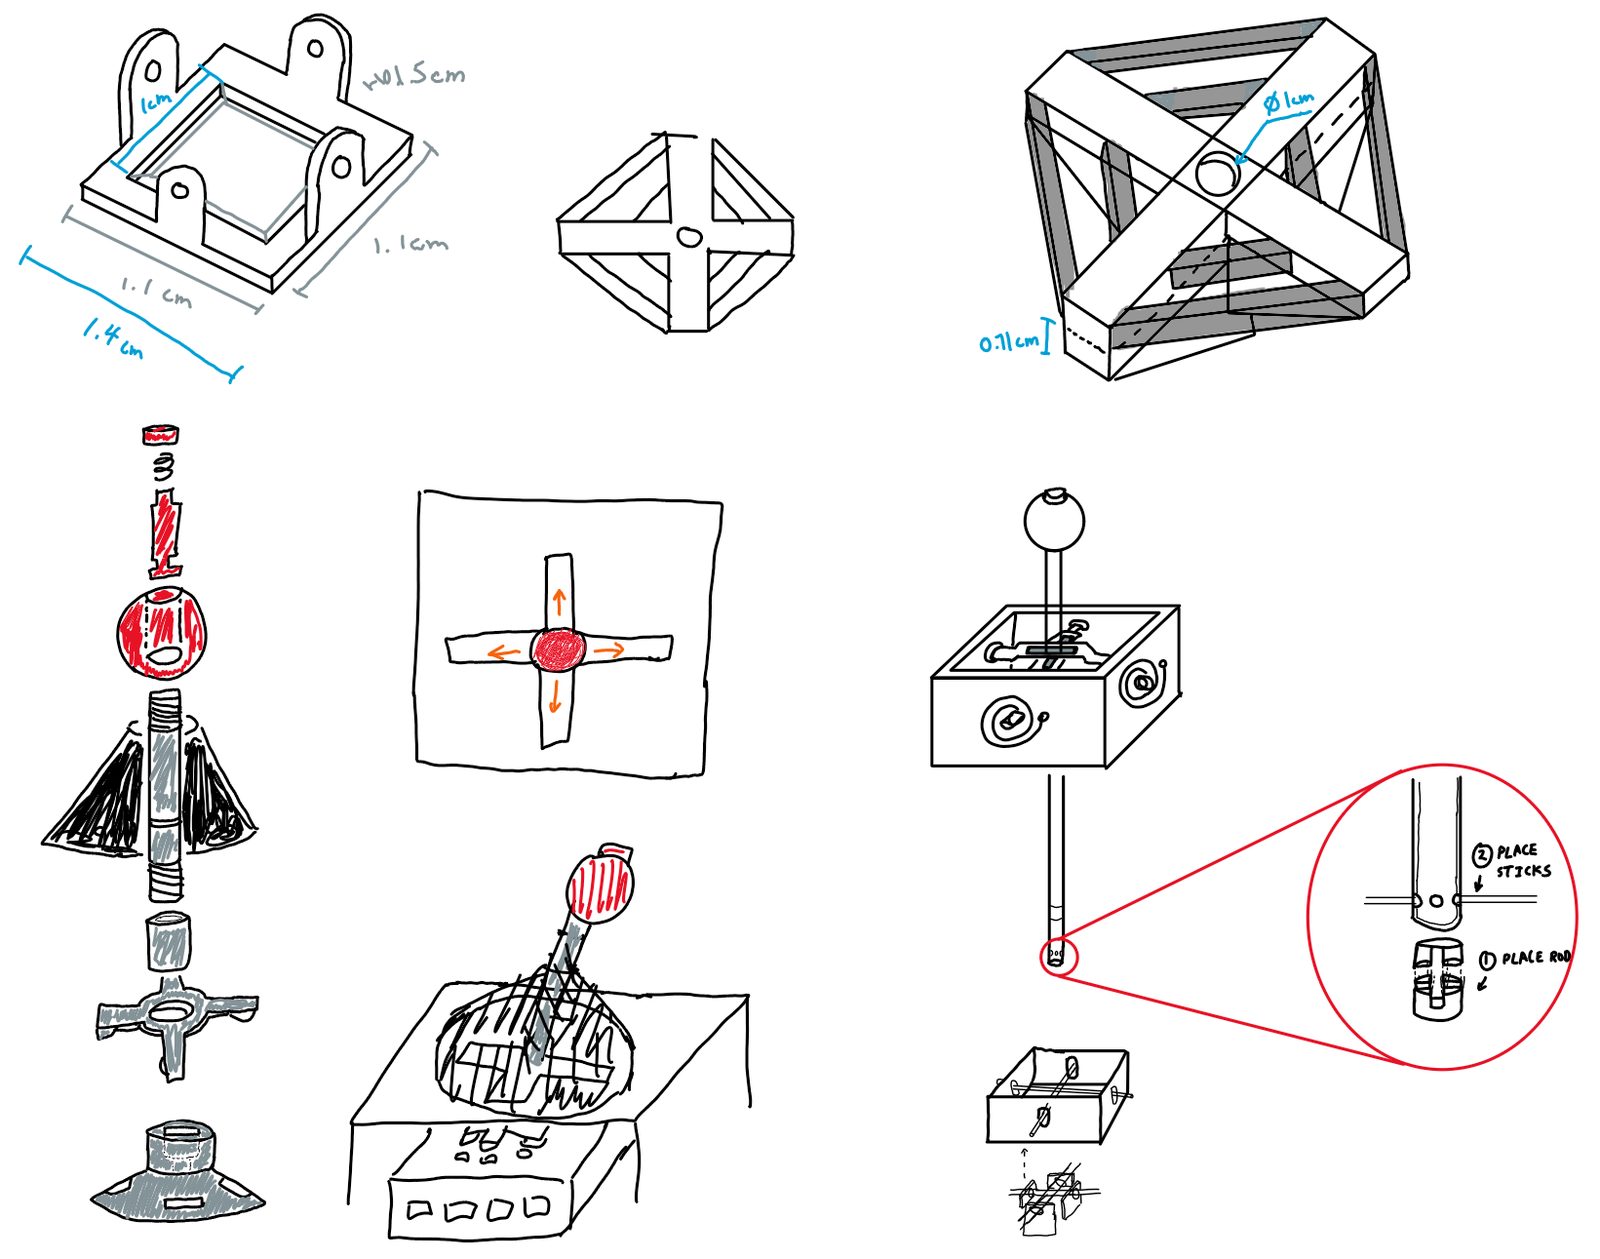
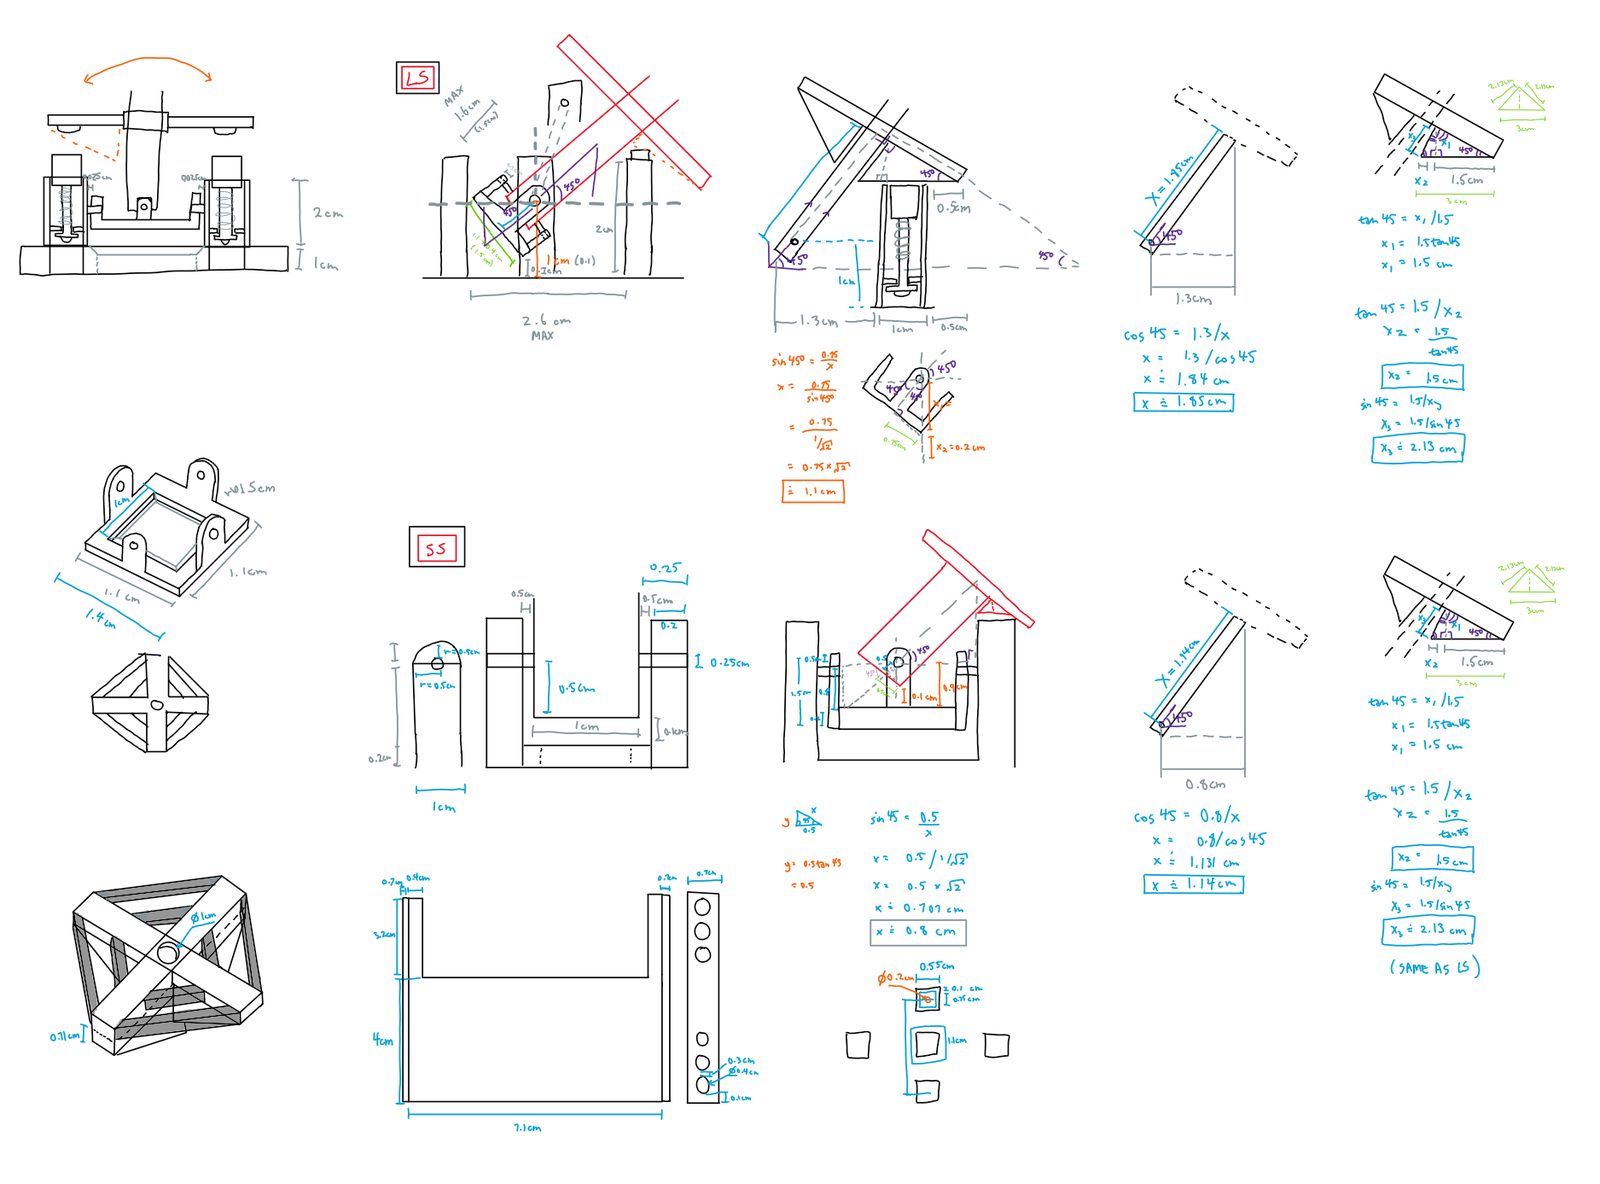
02.5 Mechanism Ideation Sketches & Stroke Geometry
Hand-drawn kinematic diagrams and trigonometric angle calculations optimizing joystick pivot throws and claw finger leverage.
03Electrical, Firmware & Hardware Integration
Schematic capture, PCB routing, sensor interfacing, actuator control, and embedded firmware implementation.
03.1 Multi-Axis Ribbon Harness & Cable Management
Overhead ribbon cable routing with flex loops and anchor brackets to prevent snagging during high-speed gantry travel.
03.2 RobotC Control Firmware & Automated Cycle Testing
Embedded firmware written in RobotC (C++) implementing smooth joystick motor mapping, limit switch homing, and automatic drop sequences.