projects / 2
10-DOF Anthropomorphic Dexterous Hand
A fully articulated 10-degree-of-freedom anthropomorphic robotic hand engineered from first principles. Sculpted with advanced SolidWorks surface modelling to package 10 micro-servos into an ergonomic human-scale palm cavity, driven by antagonistic braided tendon cabling, and powered by an isolated transient-safe 6V/10A power rail.
Live bench actuation demo: DOIT ESP32 DevKit controlling coordinated multi-digit finger spread (abduction/adduction) and independent thumb opposition via I²C register offloading.
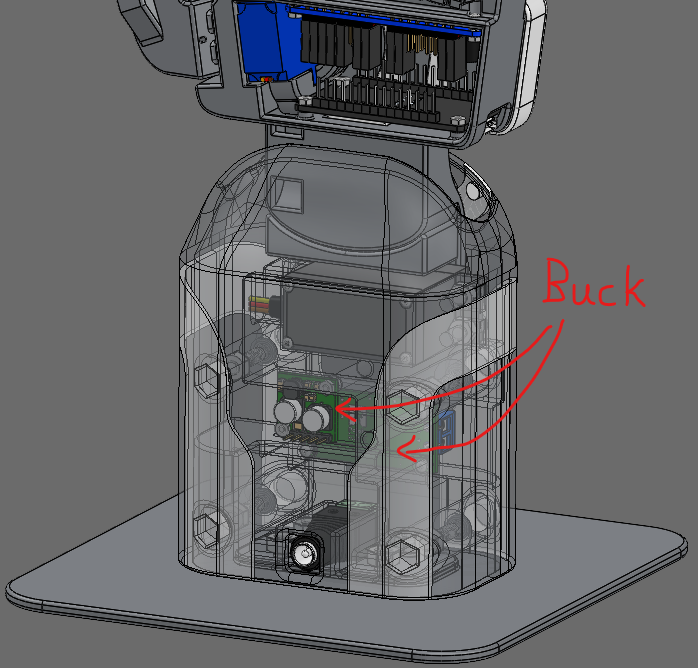
- Engineered a high-transient power architecture with dual XL4015 buck converters and 4,700 µF bulk decoupling capacitance that effortlessly absorbs 10 A simultaneous stall surges across 10 servos without dropping logic rails.
- Eliminated PWM timing jitter by offloading 10 channels of 50 Hz pulse generation to an NXP PCA9685 12-bit hardware driver over I²C (400 kHz Fast-mode), ensuring zero interference from RTOS context switches.
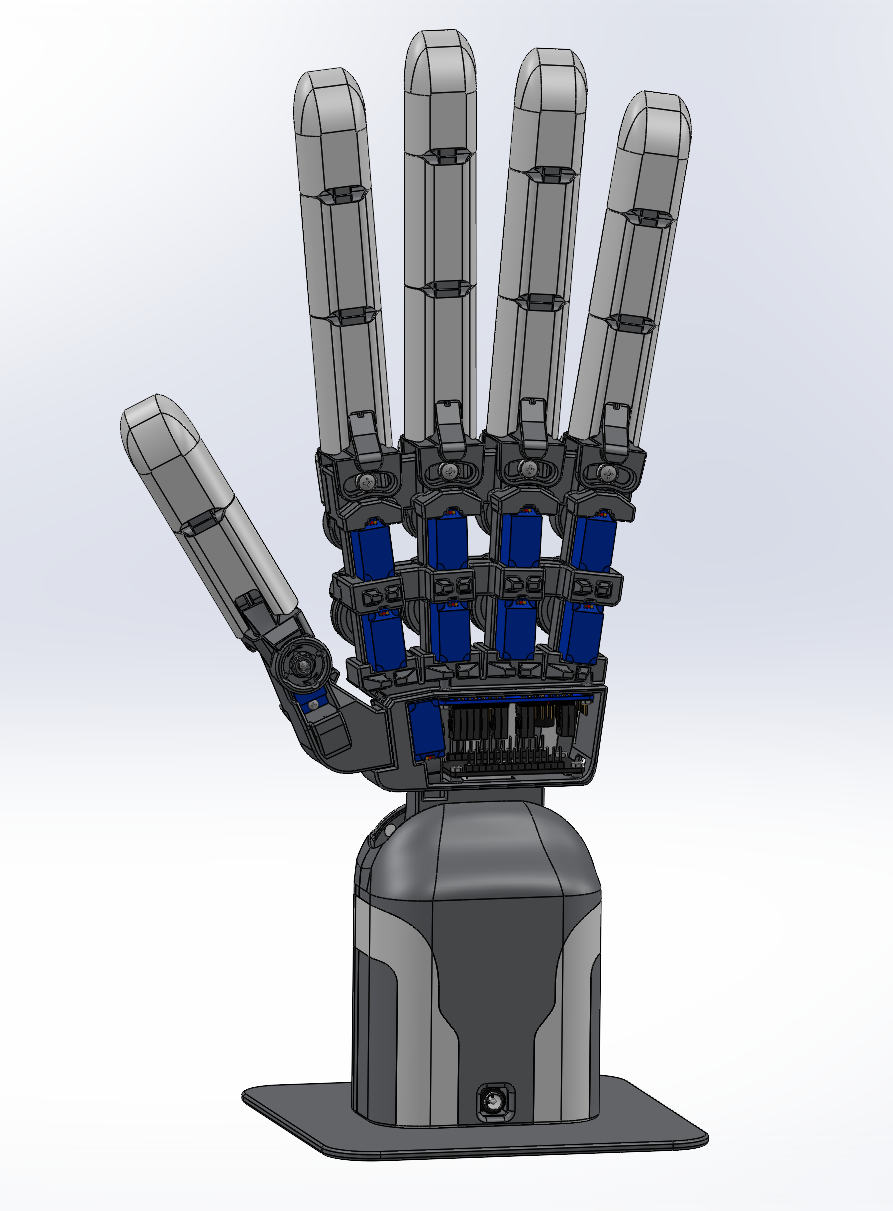
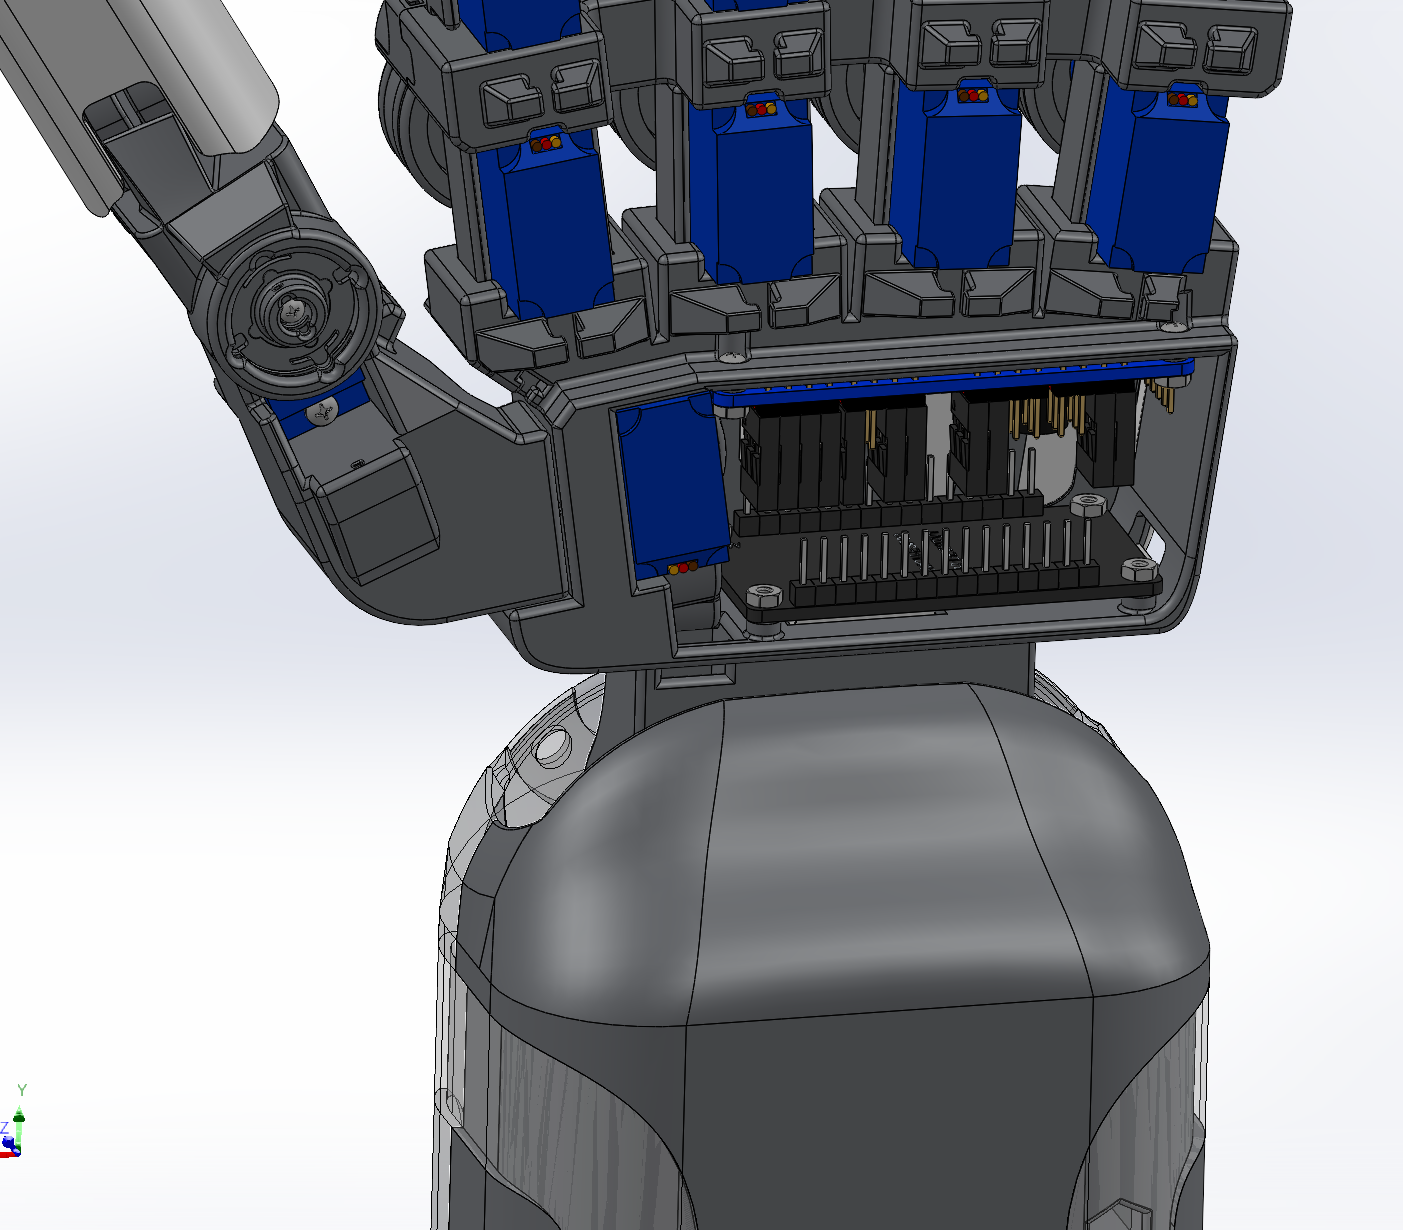
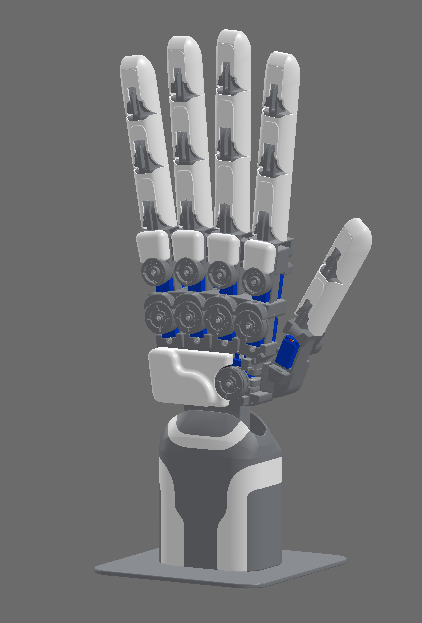
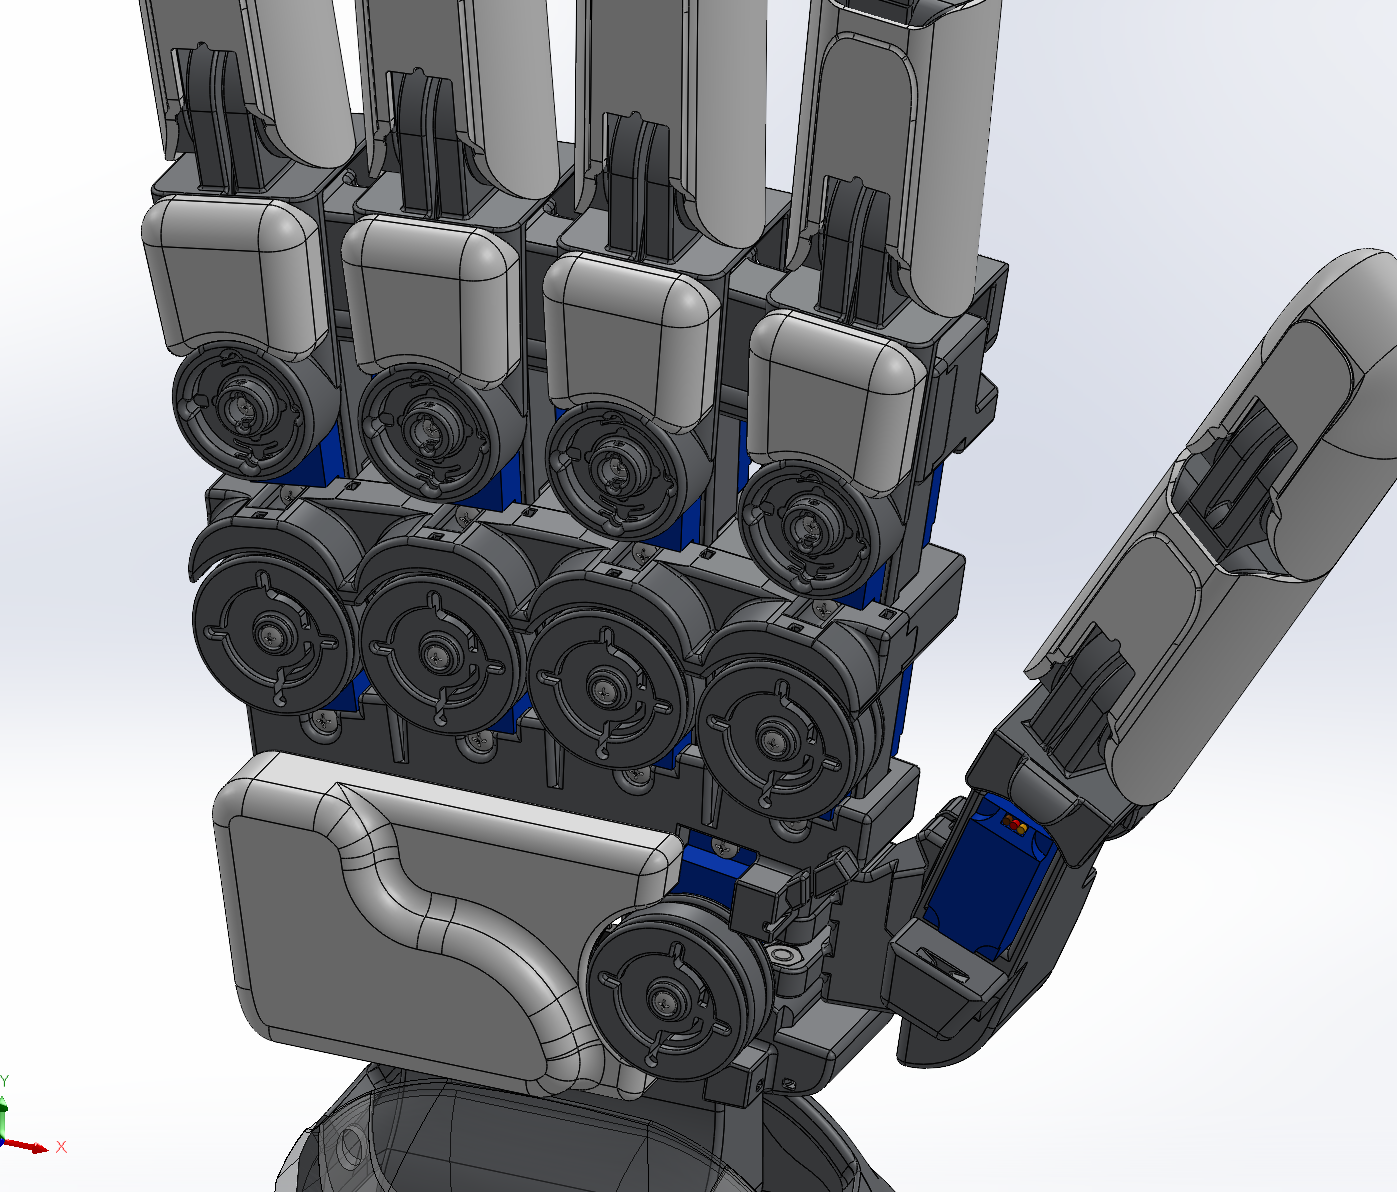
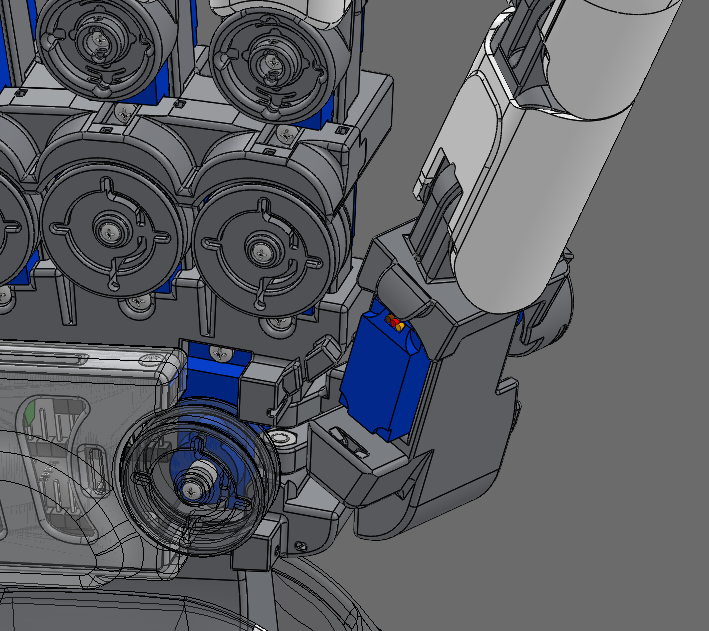
- Packed 10 independent actuators into an anthropomorphic palm using advanced SolidWorks surface modelling (boundary surfacing and continuous lofts) to maintain human proportions with sub-millimeter internal clearances.
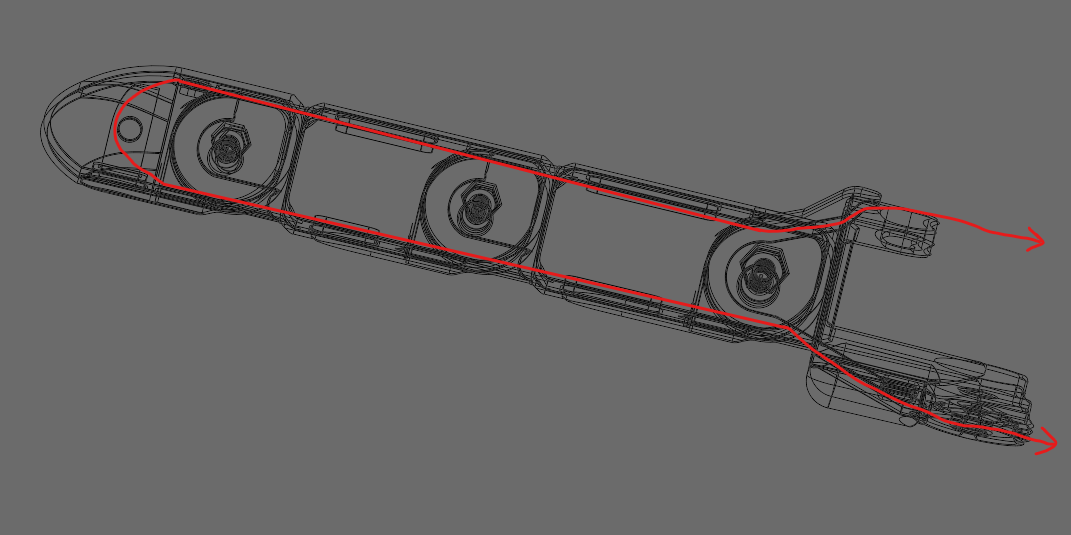
- Designed a low-friction antagonistic tendon transmission utilizing braided high-tensile fishing wire routed around custom idler spools and knuckle hinge pivots for zero-backlash bidirectional control.
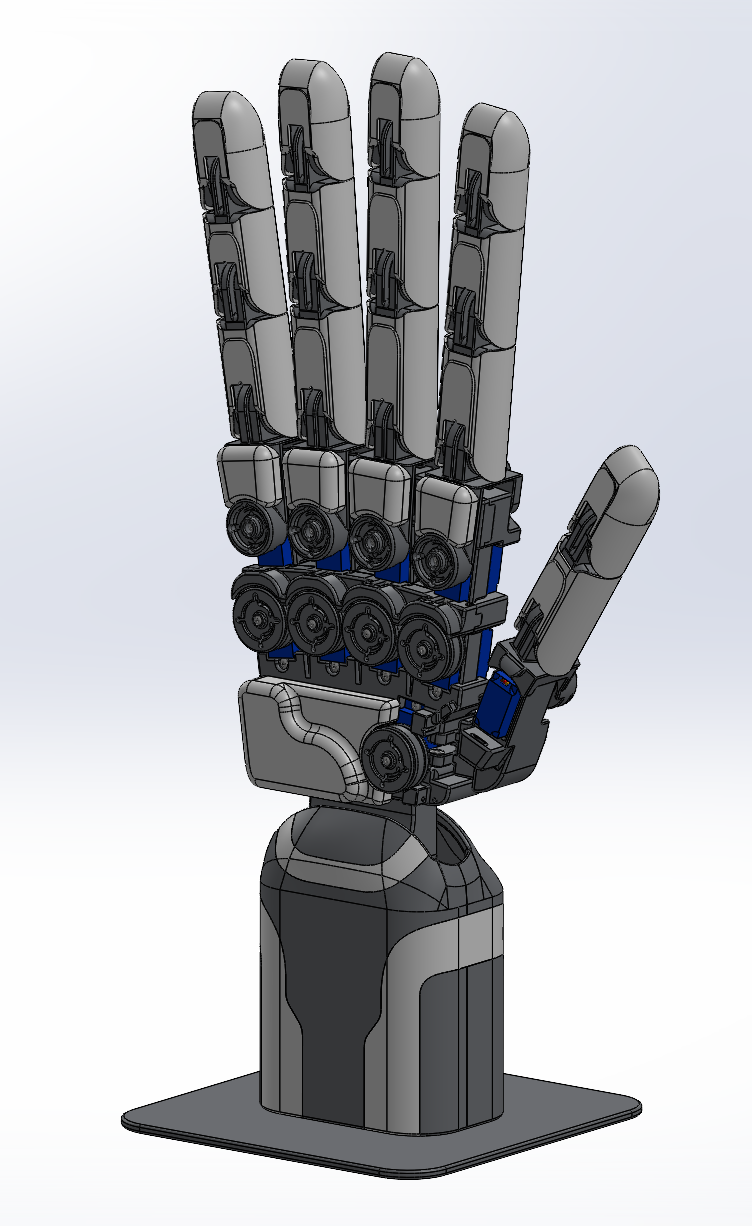
01CAD / Mechanical Design
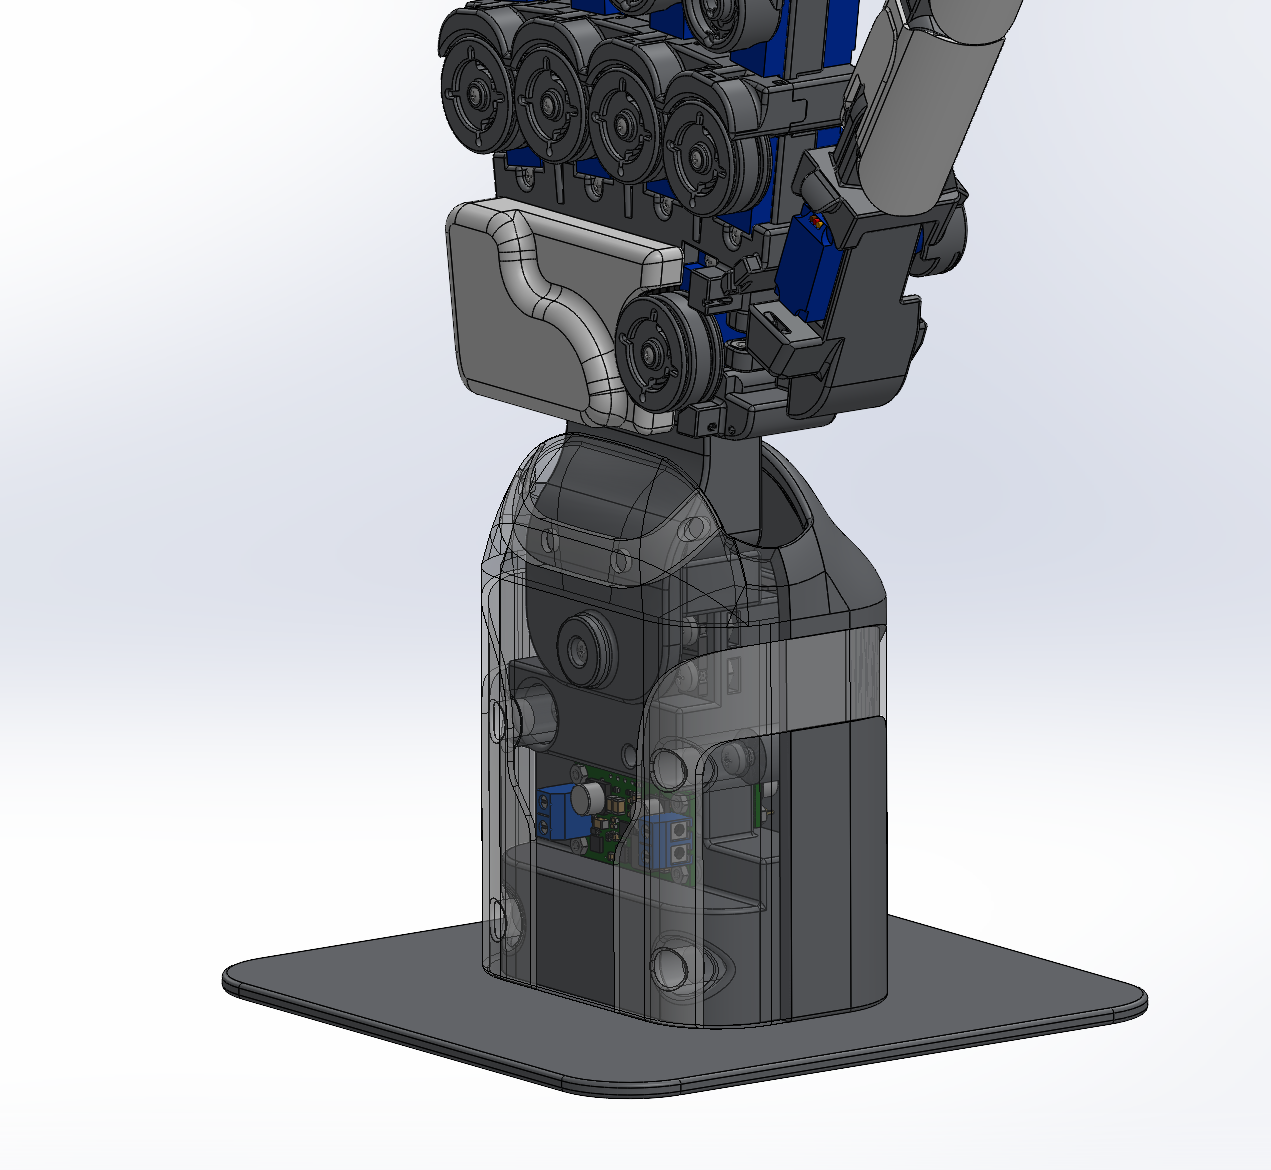
Sculpted in SolidWorks using multi-guide boundary surfaces and lofts to package ten MG90S micro-servos into an anthropomorphic palm cavity with sub-millimeter clearances. Antagonistic tendon guides, knuckle hinge clevises, and a contoured bottom wrist case were modelled for low-friction articulation and rigid pedestal integration.
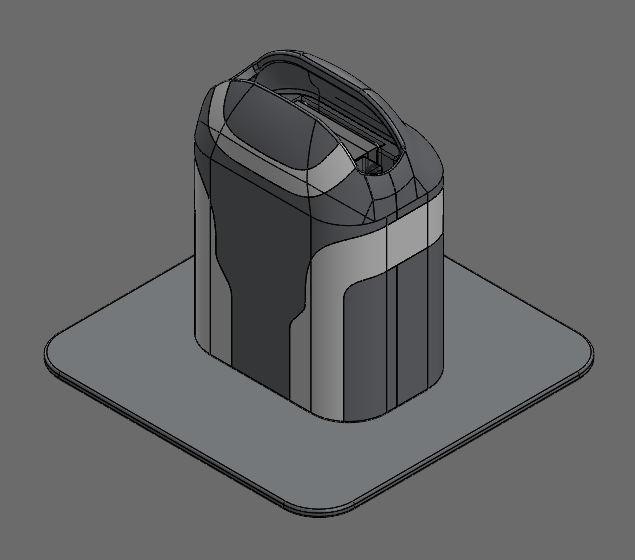
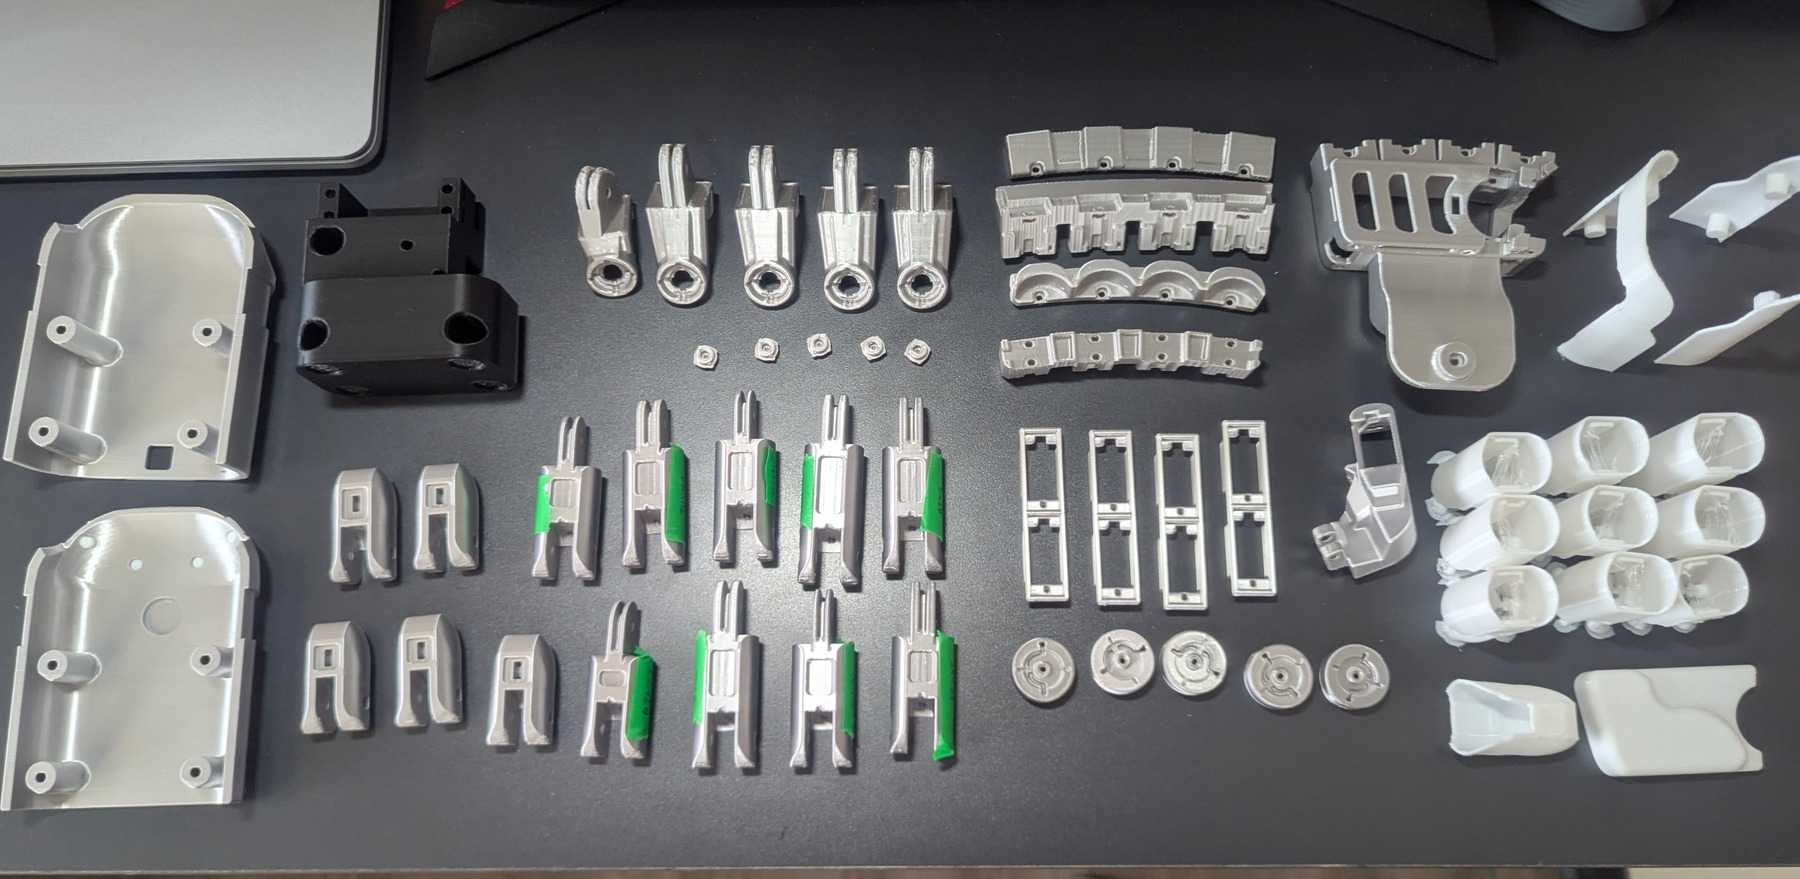
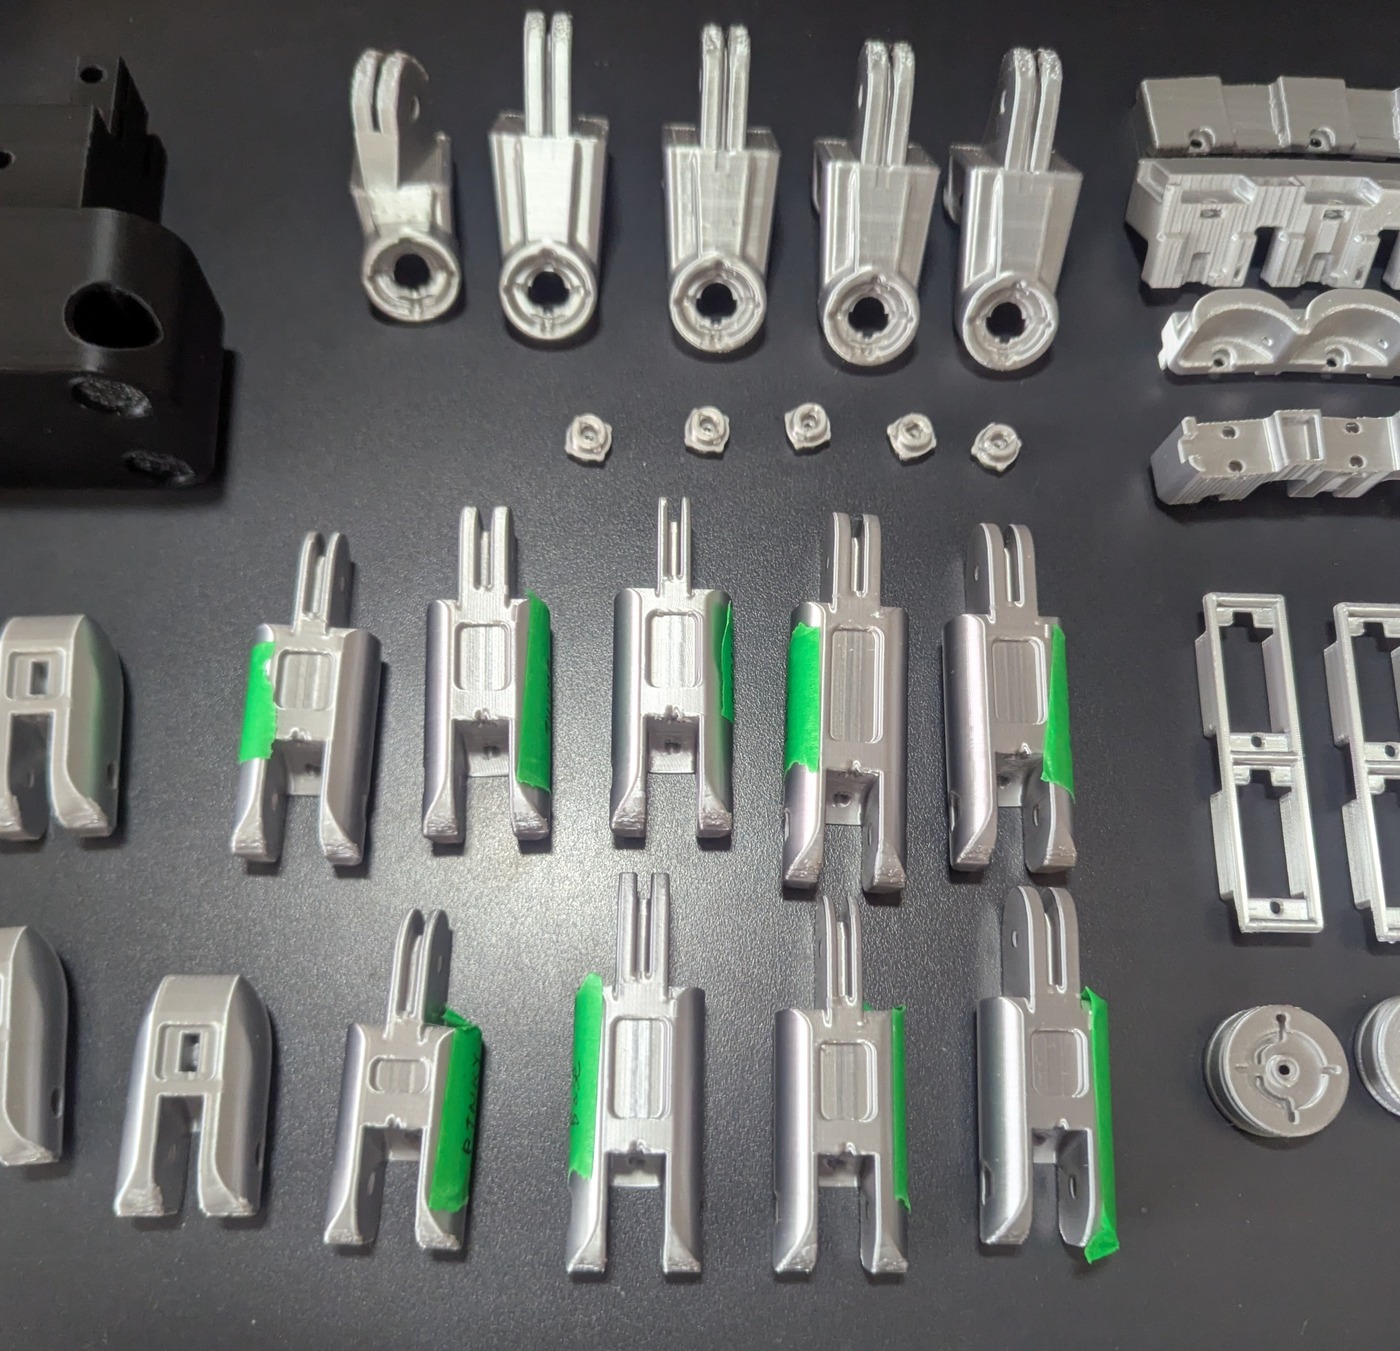
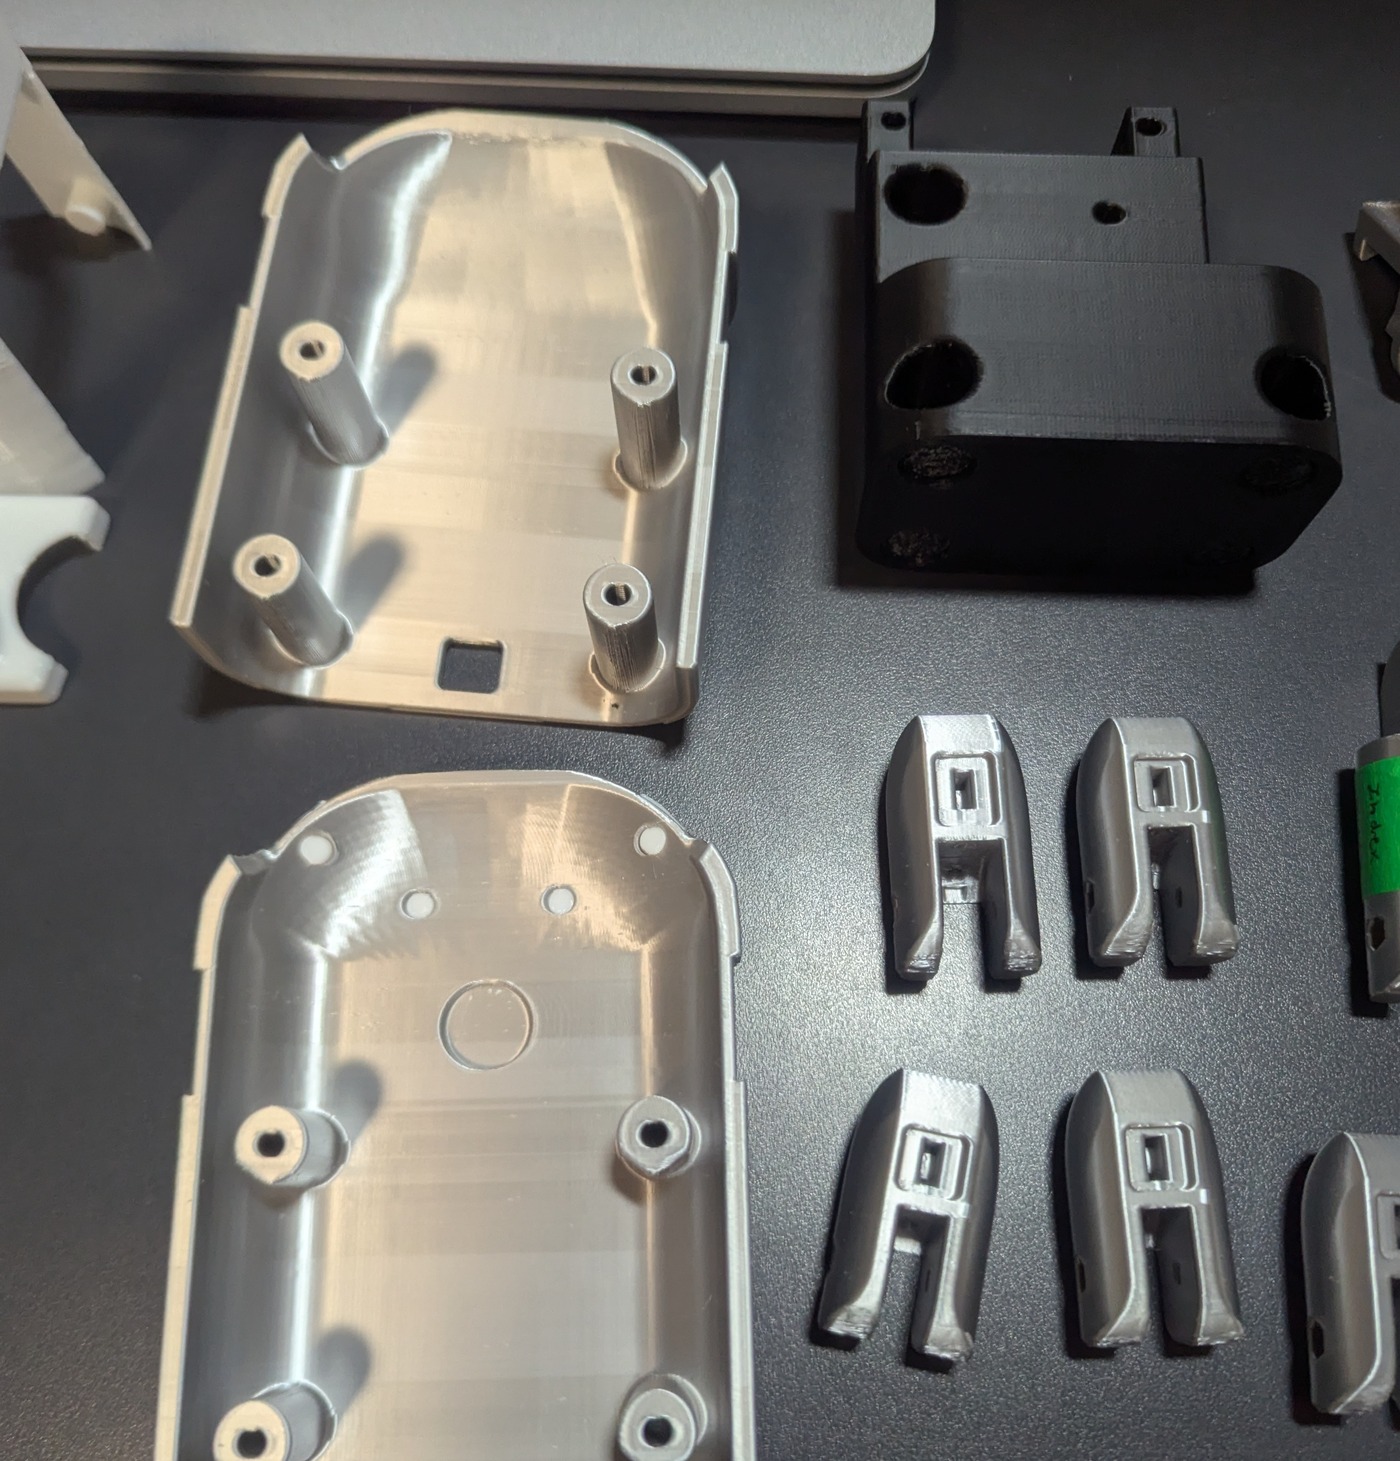
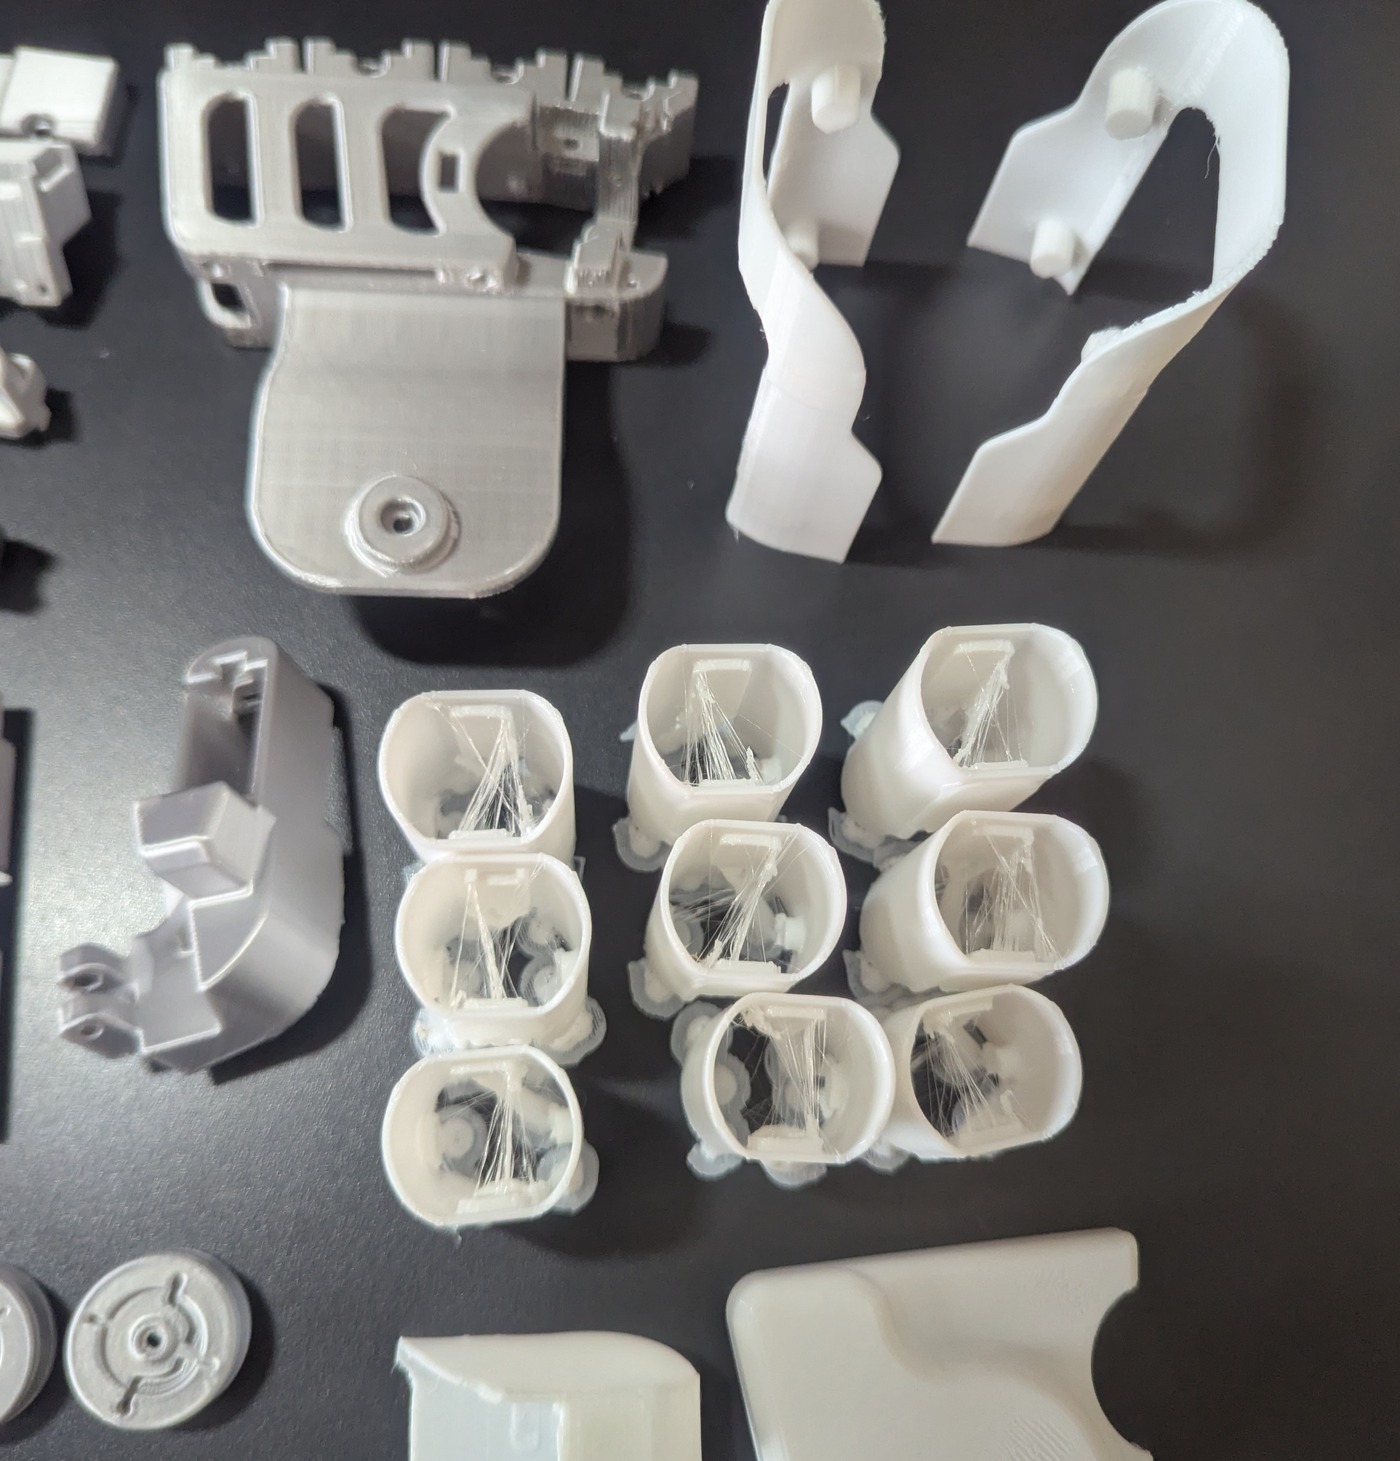
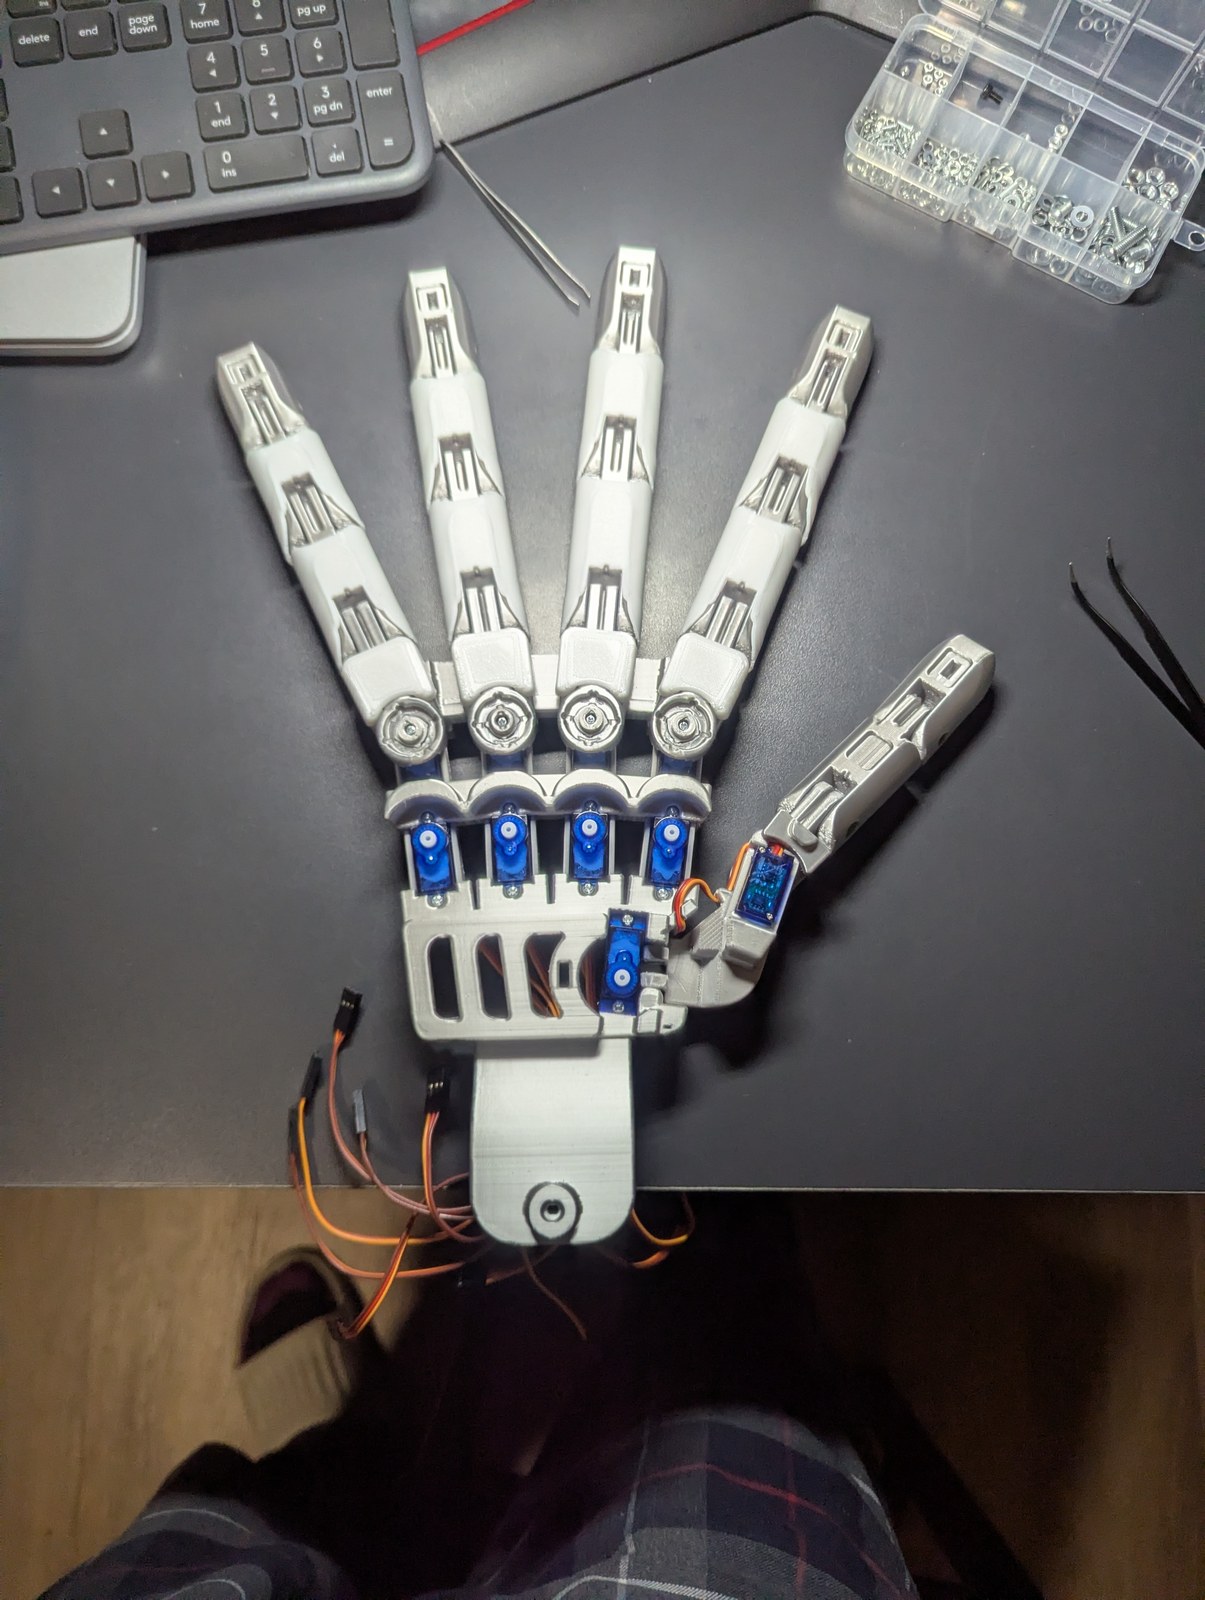
02Manufacturing — Additive Fabrication & Knolling
All mechanical components — including finger phalanges, knuckle pivots, palm chassis halves, and forearm housings — were fabricated via high-resolution FDM 3D printing on an Elegoo build platform using organic tree supports. Following post-processing and brass heat-set insert installation, all mechanical components were knolled to verify assembly clearances.
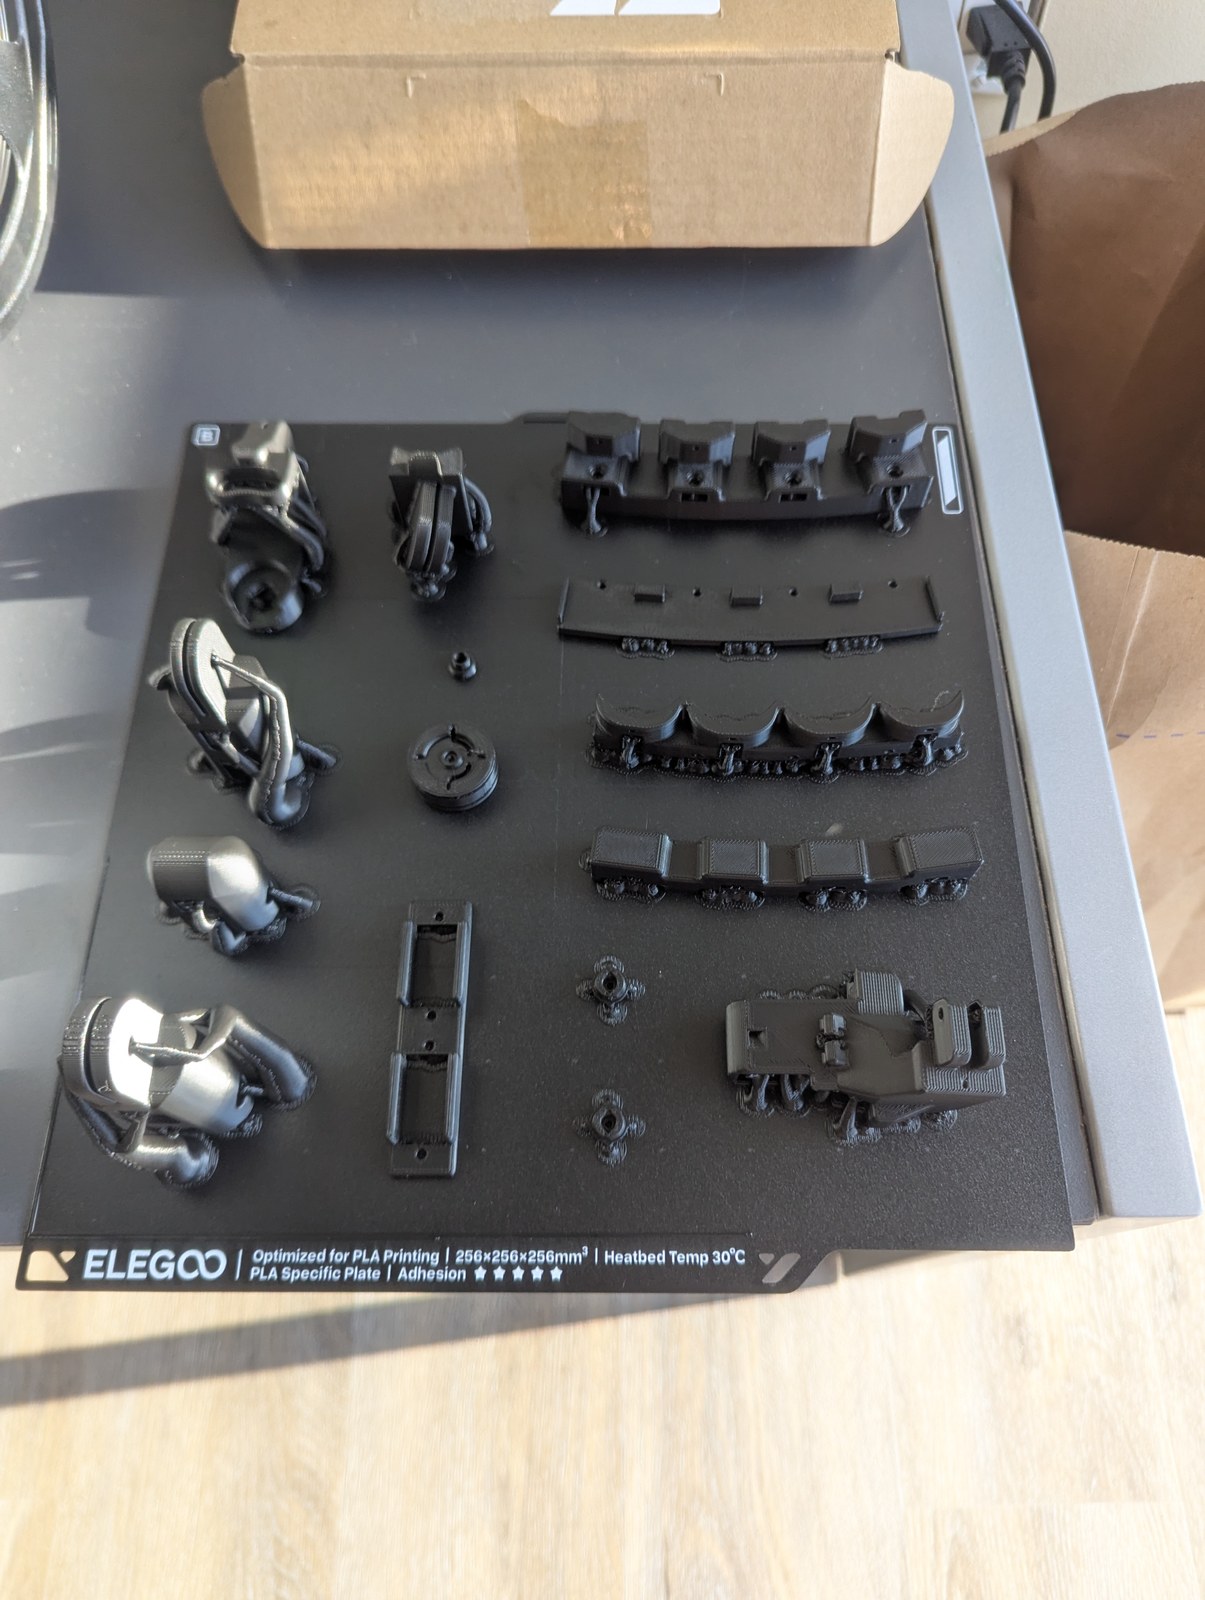
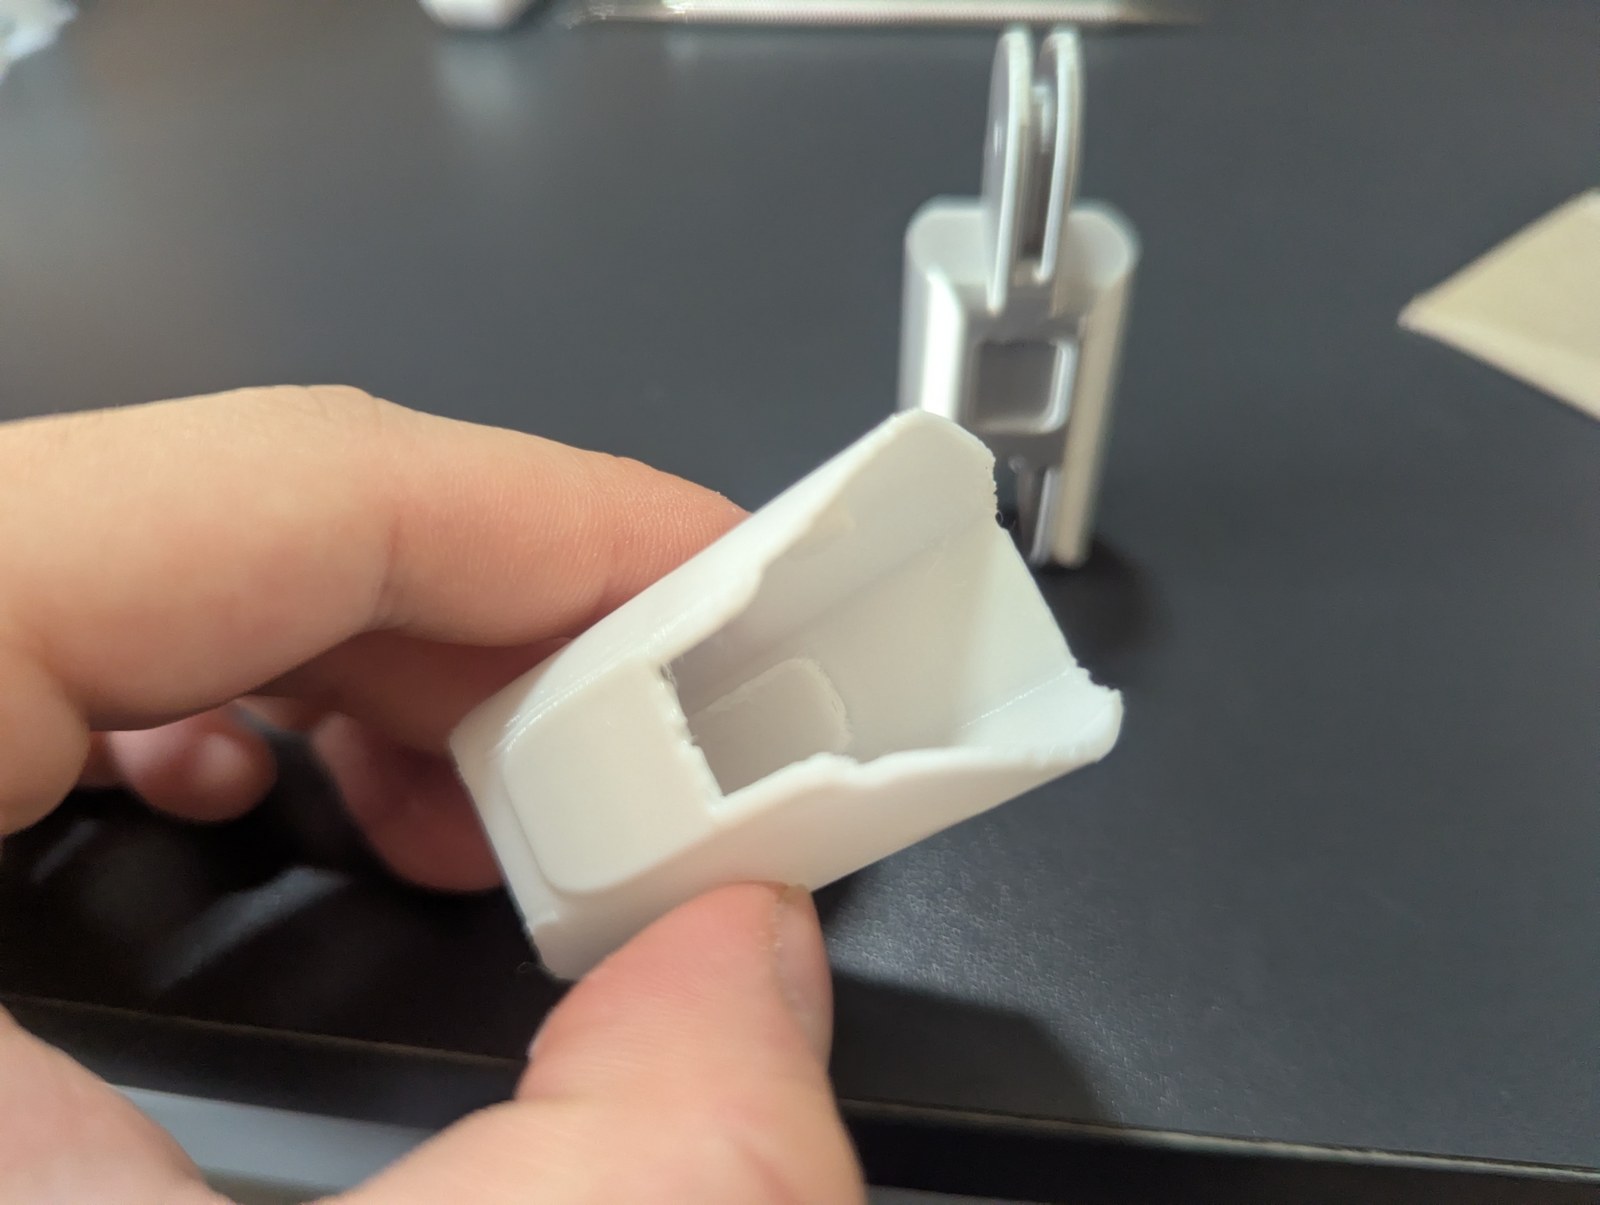
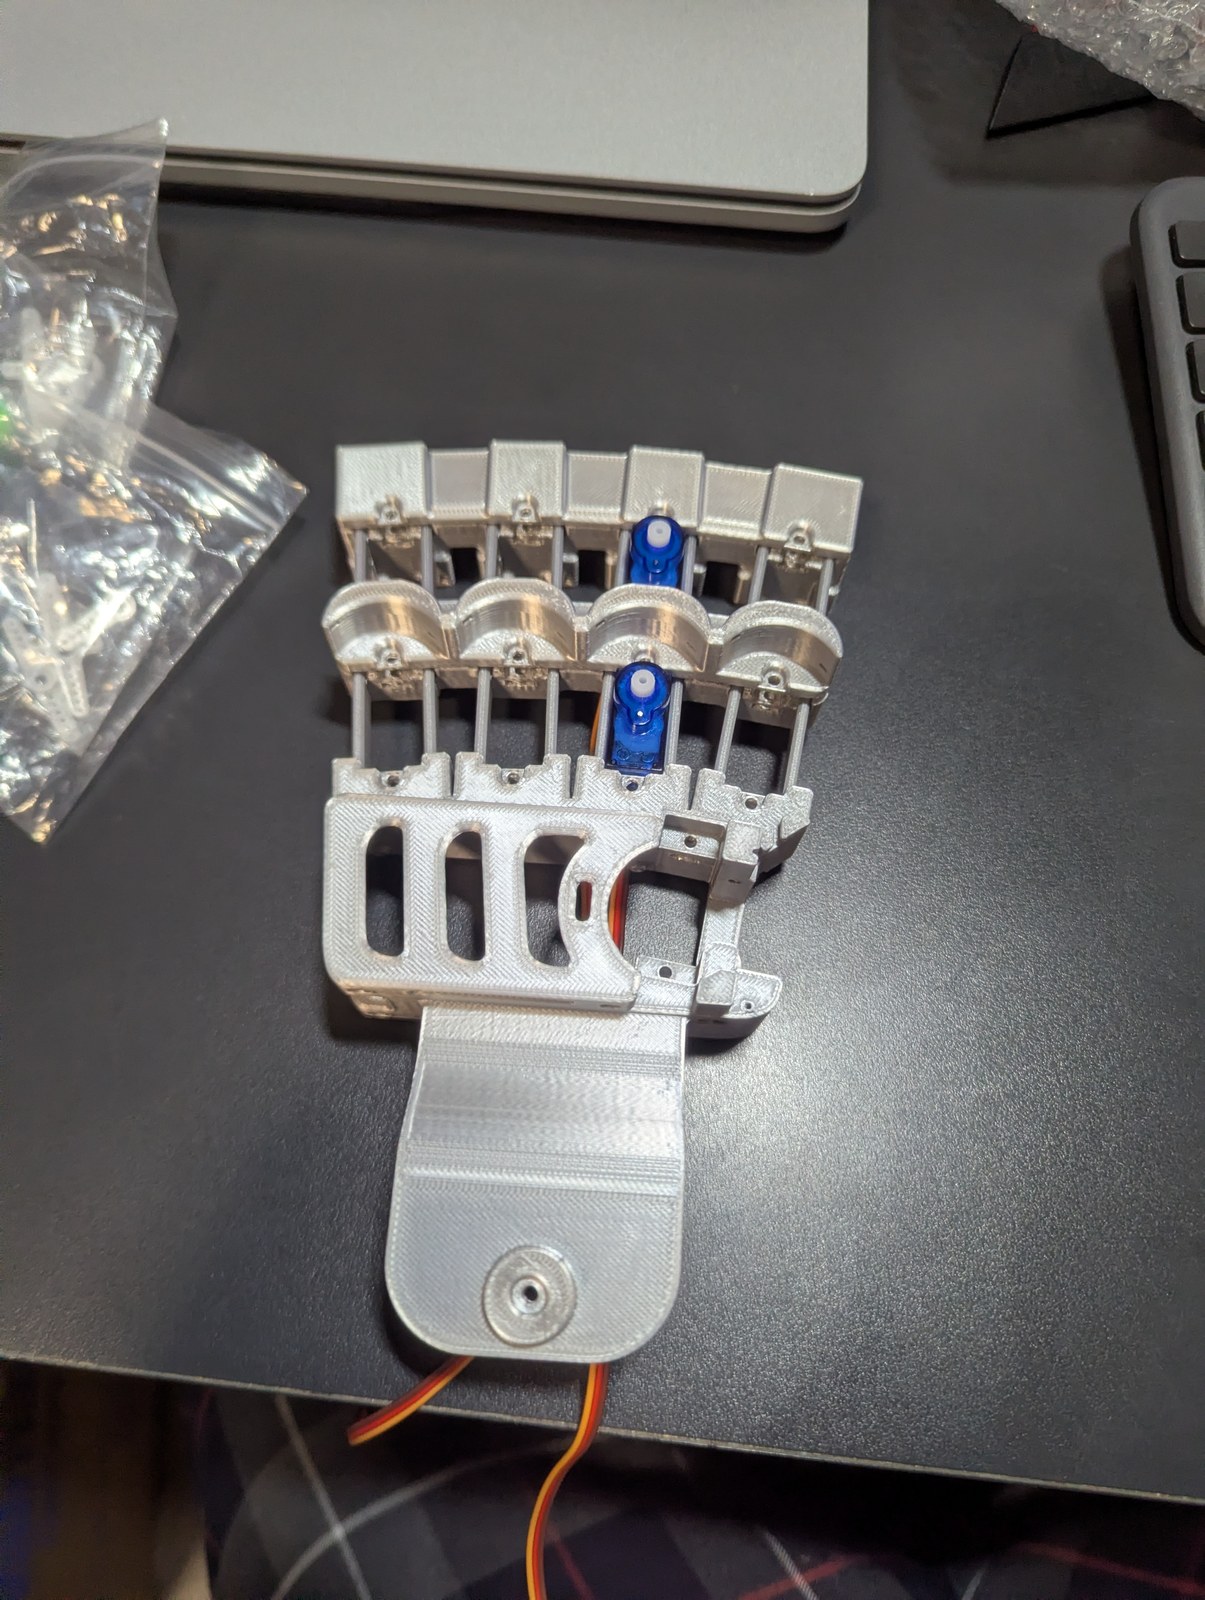
03Physical Assembly — Fast-Paced Build Progression
Mechanical integration progressed chronologically from phalanx pin press-fitting and knuckle bracket fastening to multi-tiered servo nesting in the palm skeleton. Live build recordings were processed into high-speed (1.75×–2.0×) animated GIFs to capture the entire hardware assembly workflow.


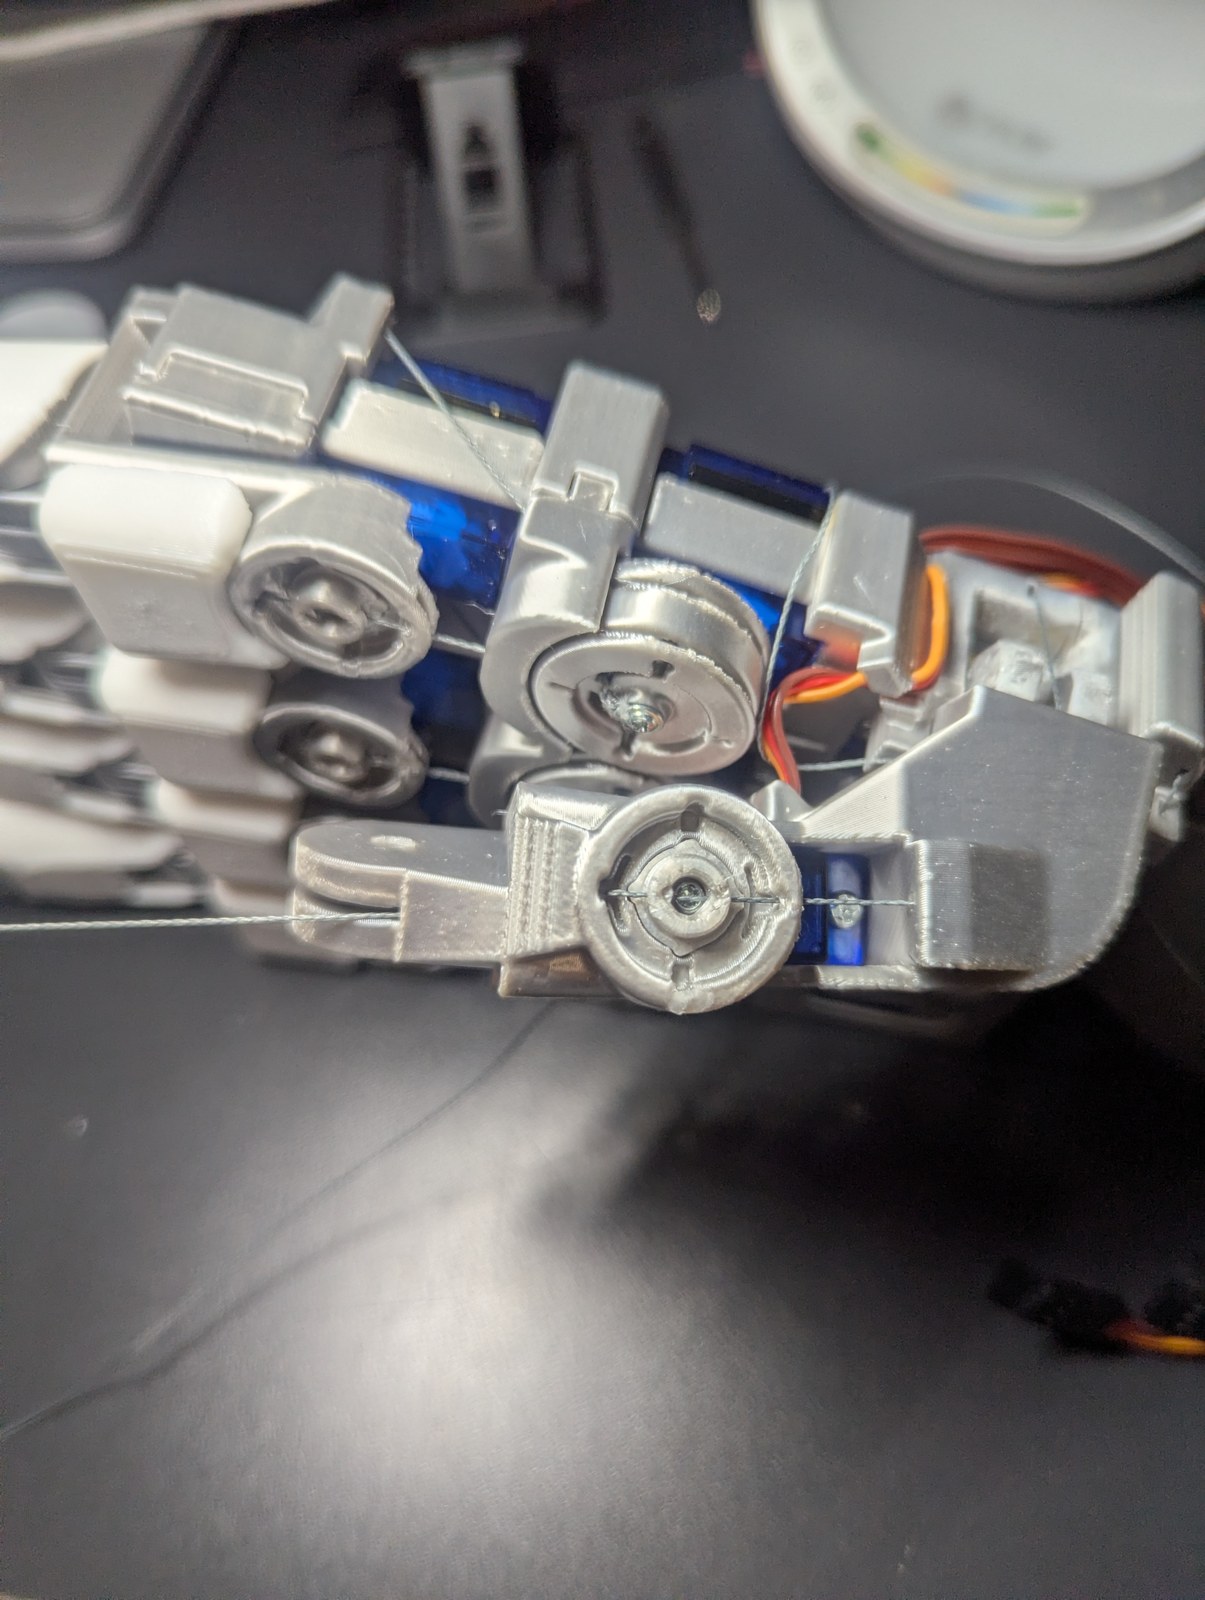
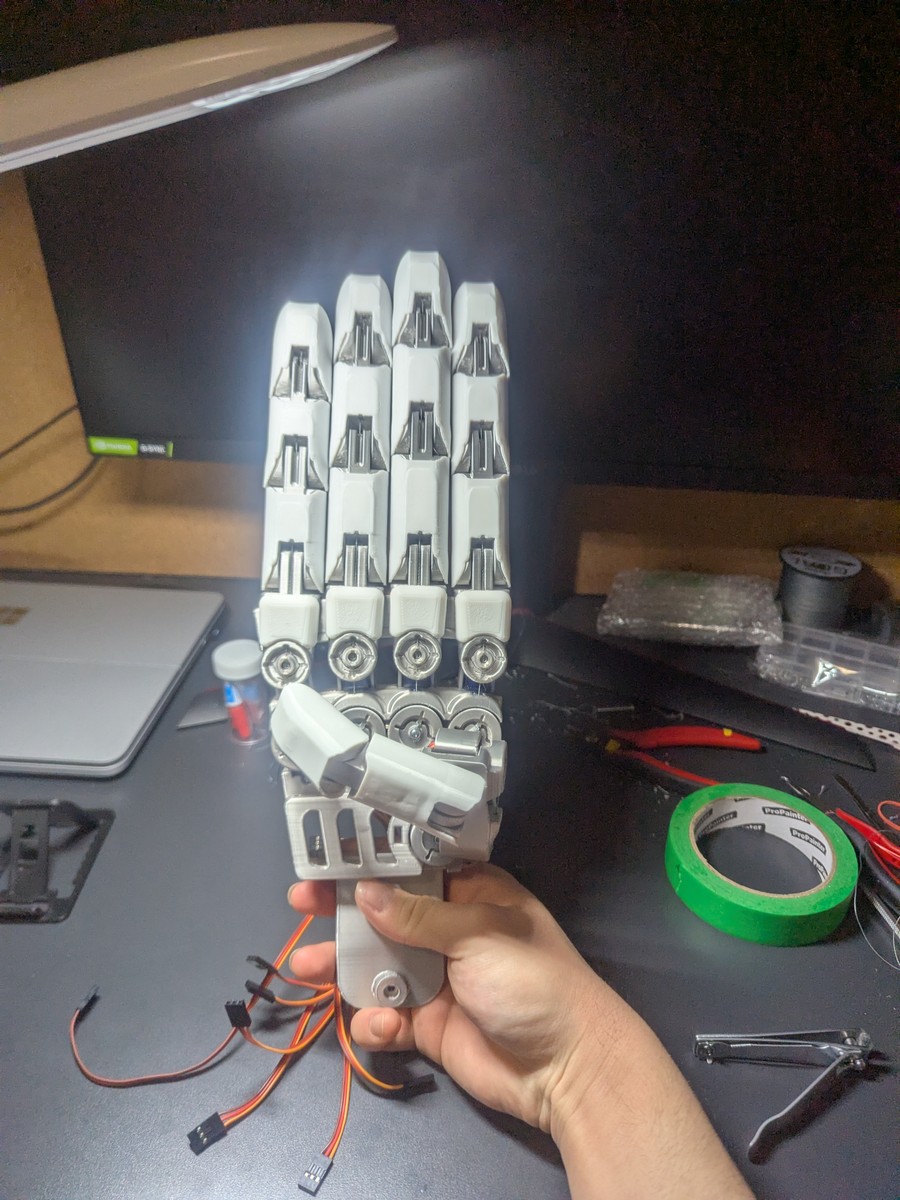
04Manual Kinematic & Pulley Testing
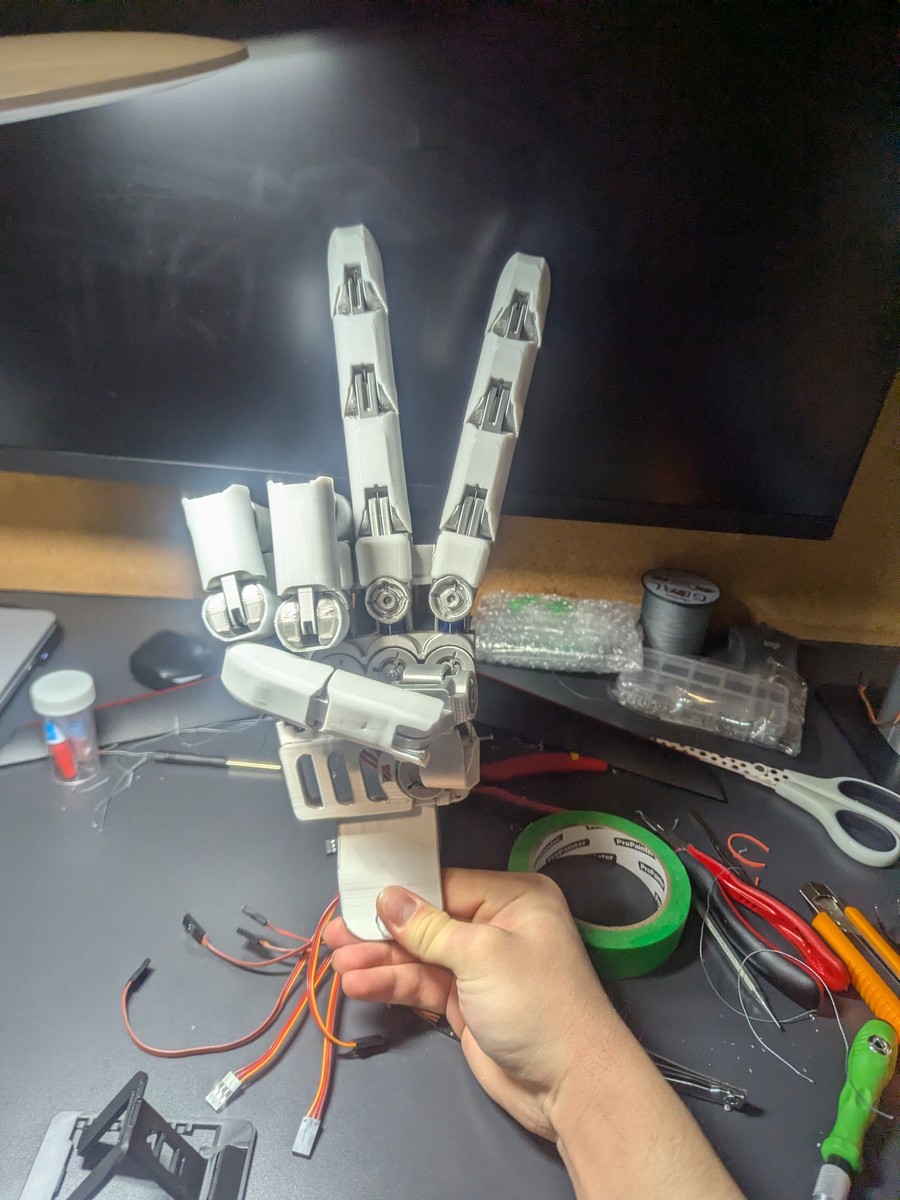
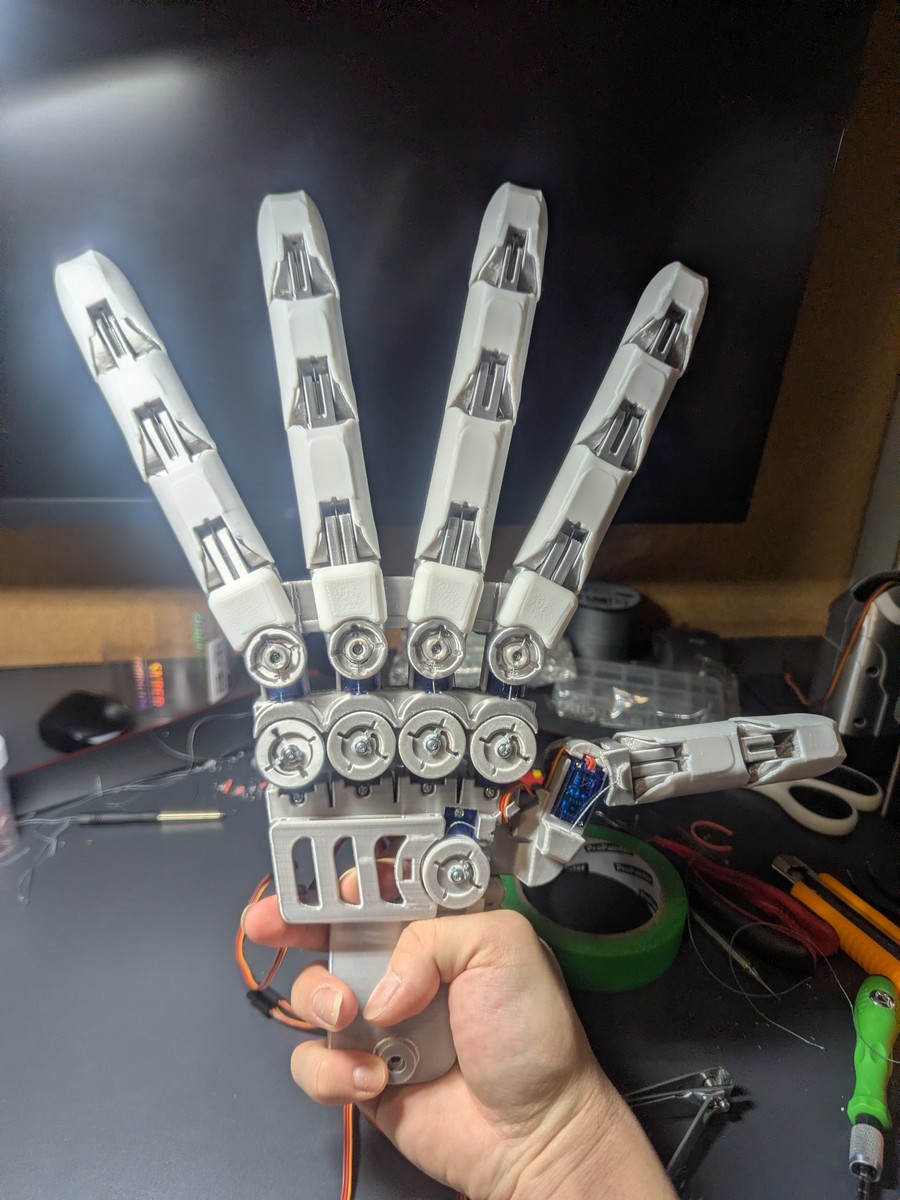
Initial dry-run kinematic validation was performed by manually tensioning high-tensile braided fishing wire lines through printed pulley conduits. This verified friction-free line travel, positive joint curl, passive spring return, and non-binding thumb opposition before electrical energization.


05Electrical Wiring & Transient-Safe Power
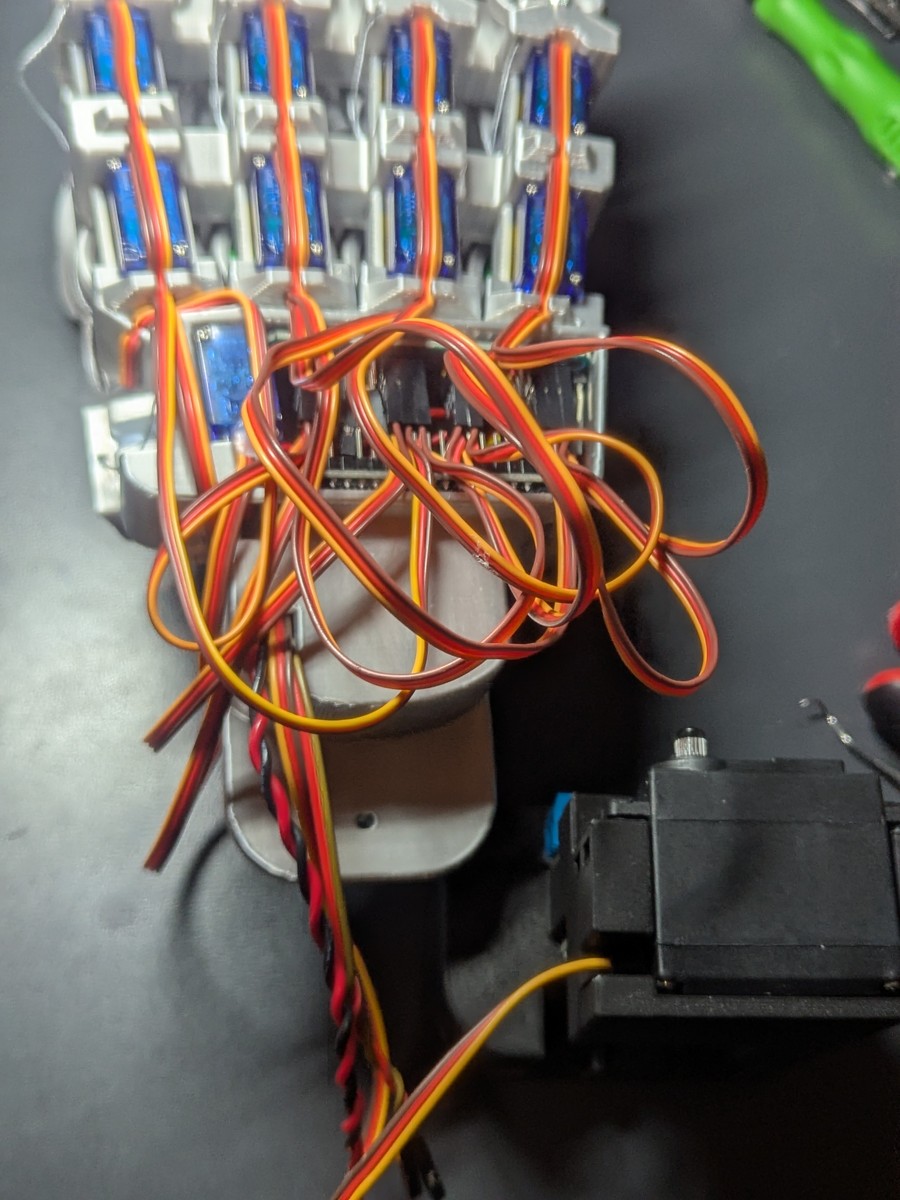
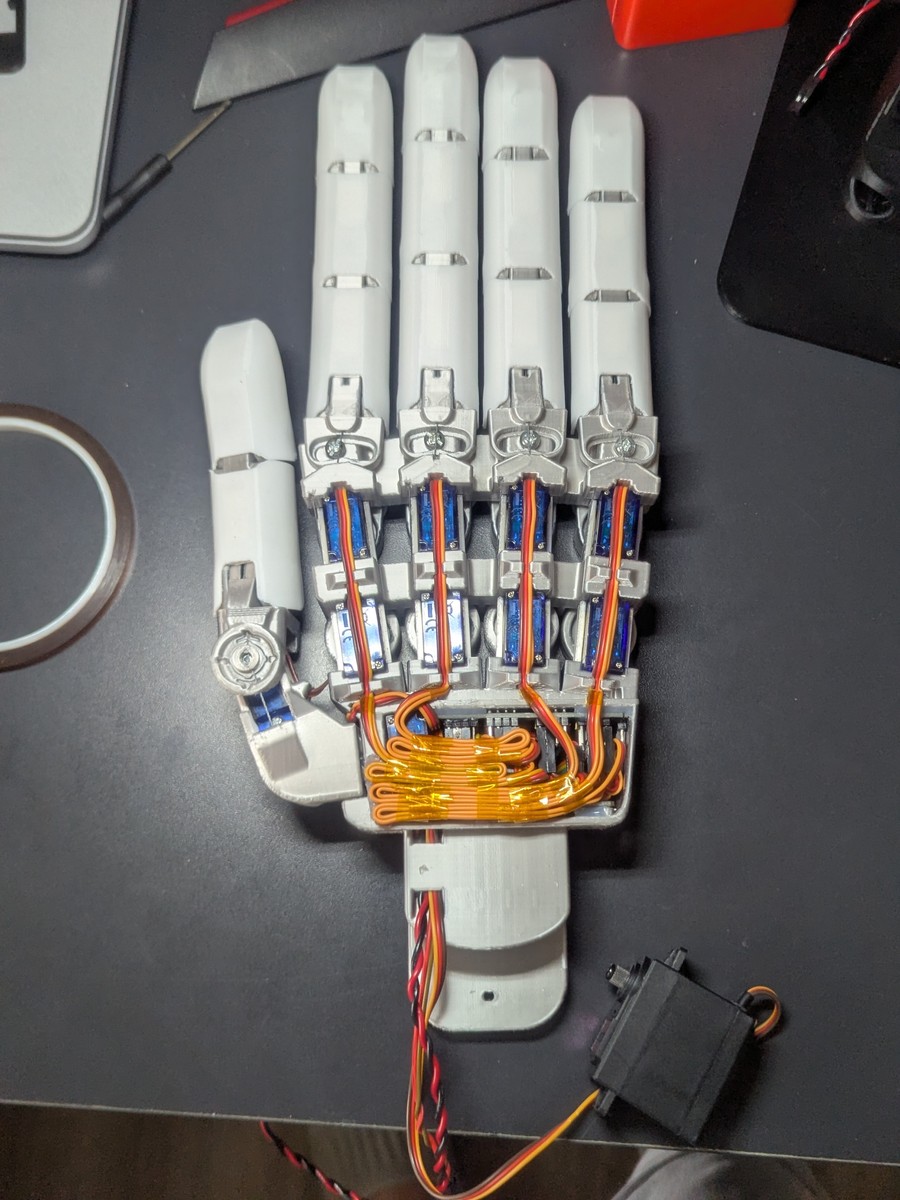
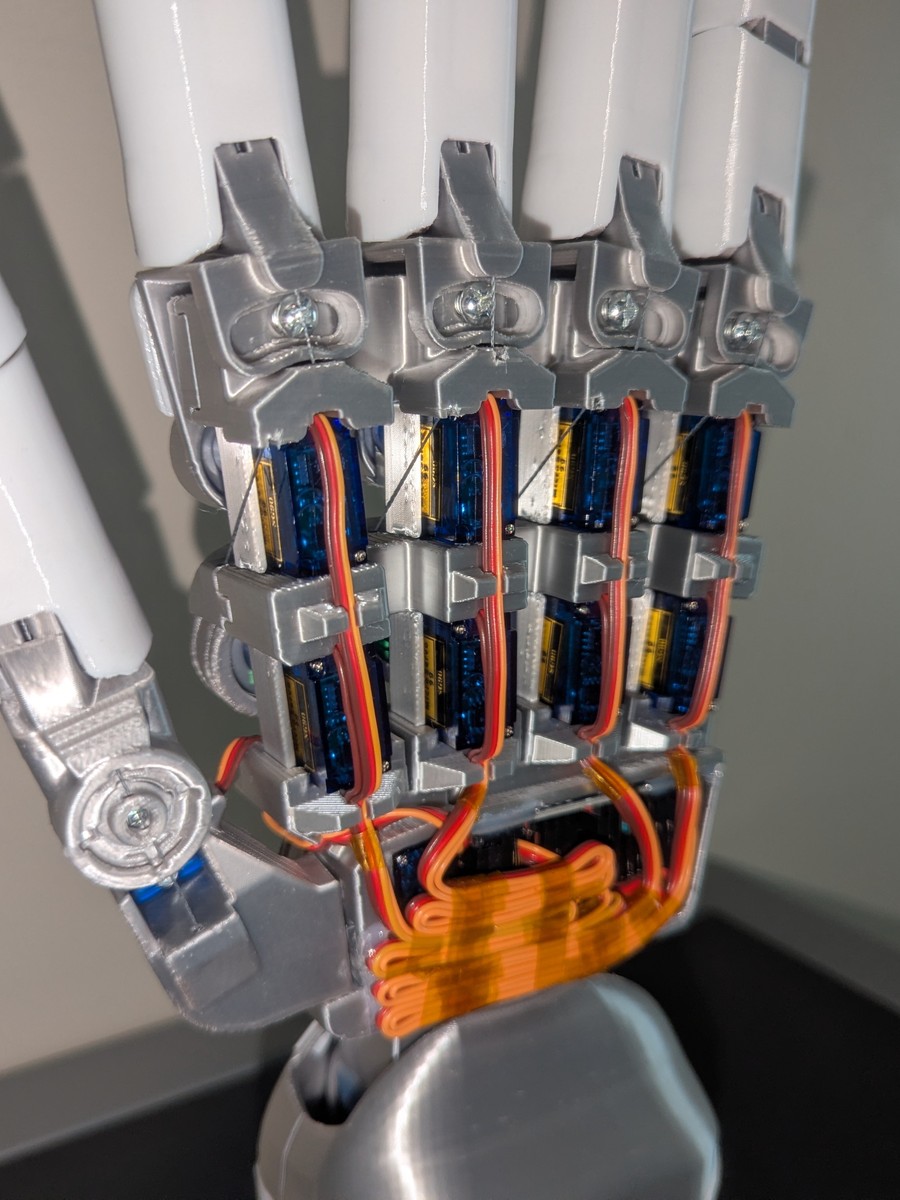
An isolated dual XL4015 buck regulation architecture steps down 12V DC input to a transient-safe 6.0V / 10A servo bus backed by 4,700 µF low-ESR bulk capacitance to prevent logic resets during stall events. Thirty servo signal conductors and power leads are neatly bundled through internal wrist raceways to the ESP32 DevKit and PCA9685 I²C driver.
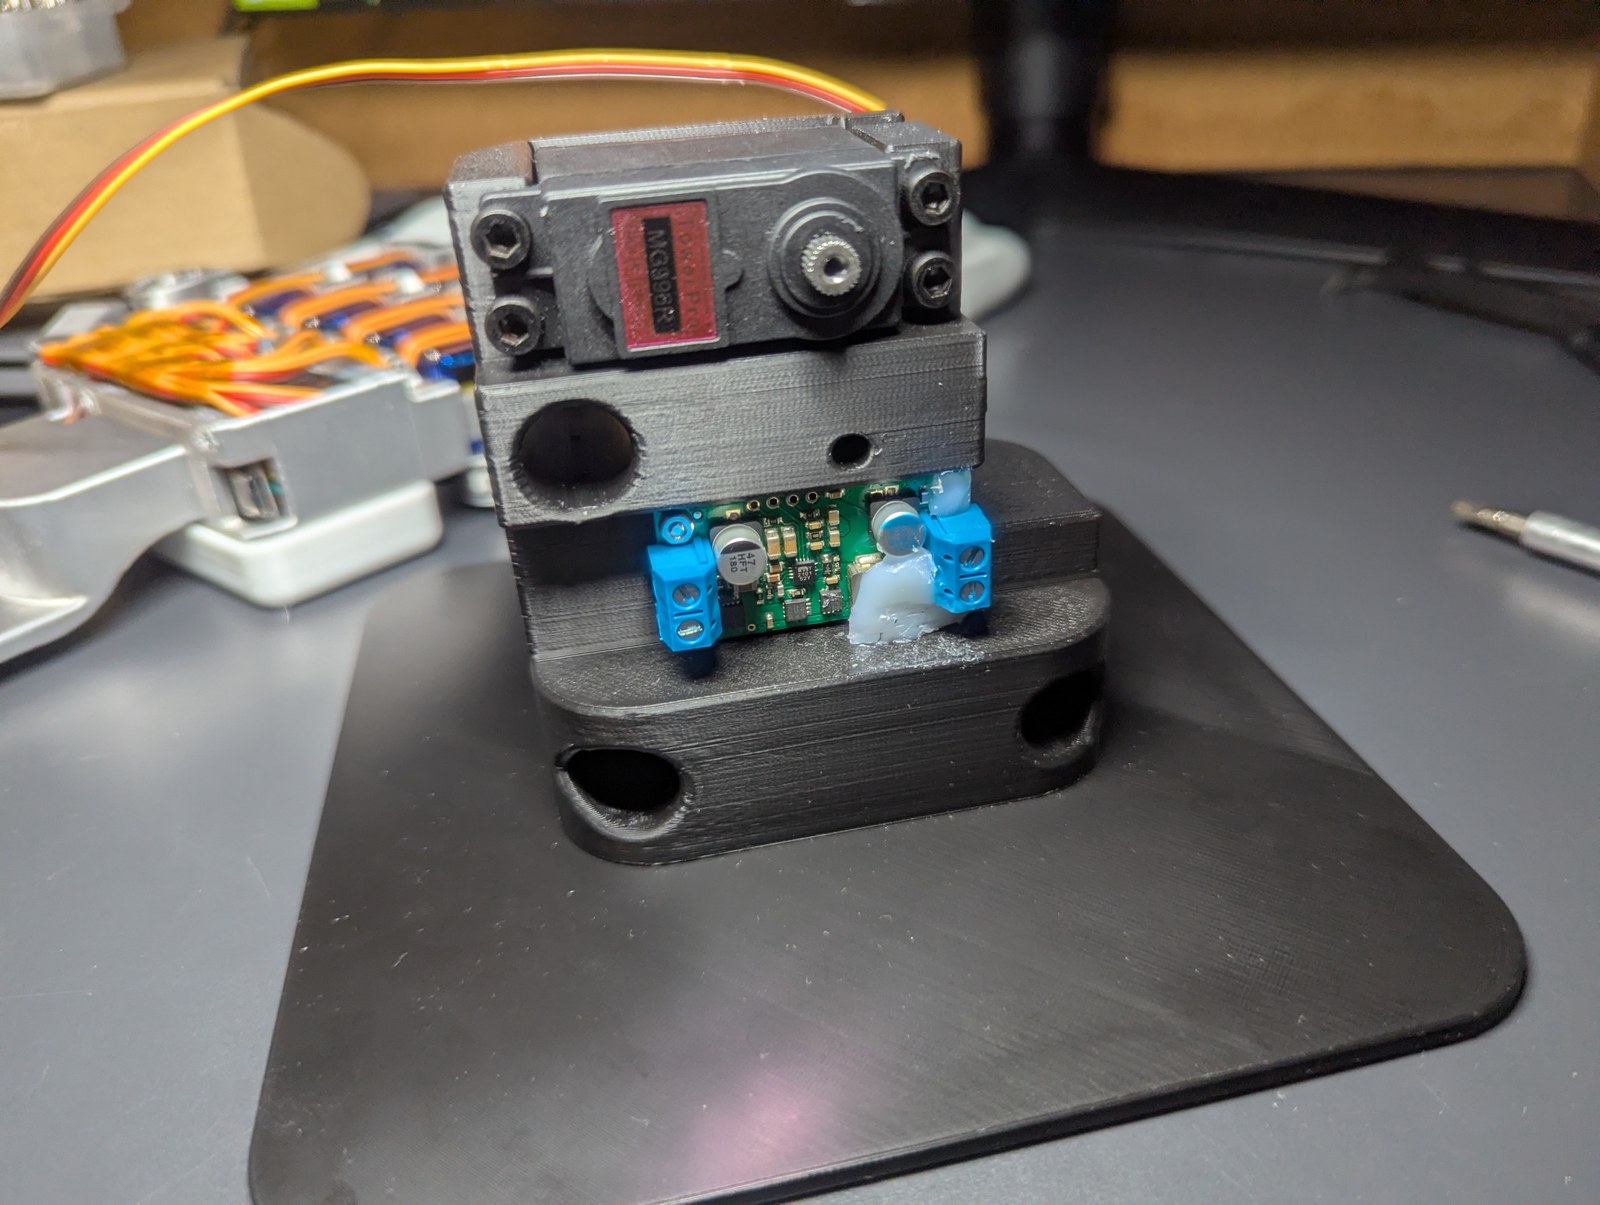
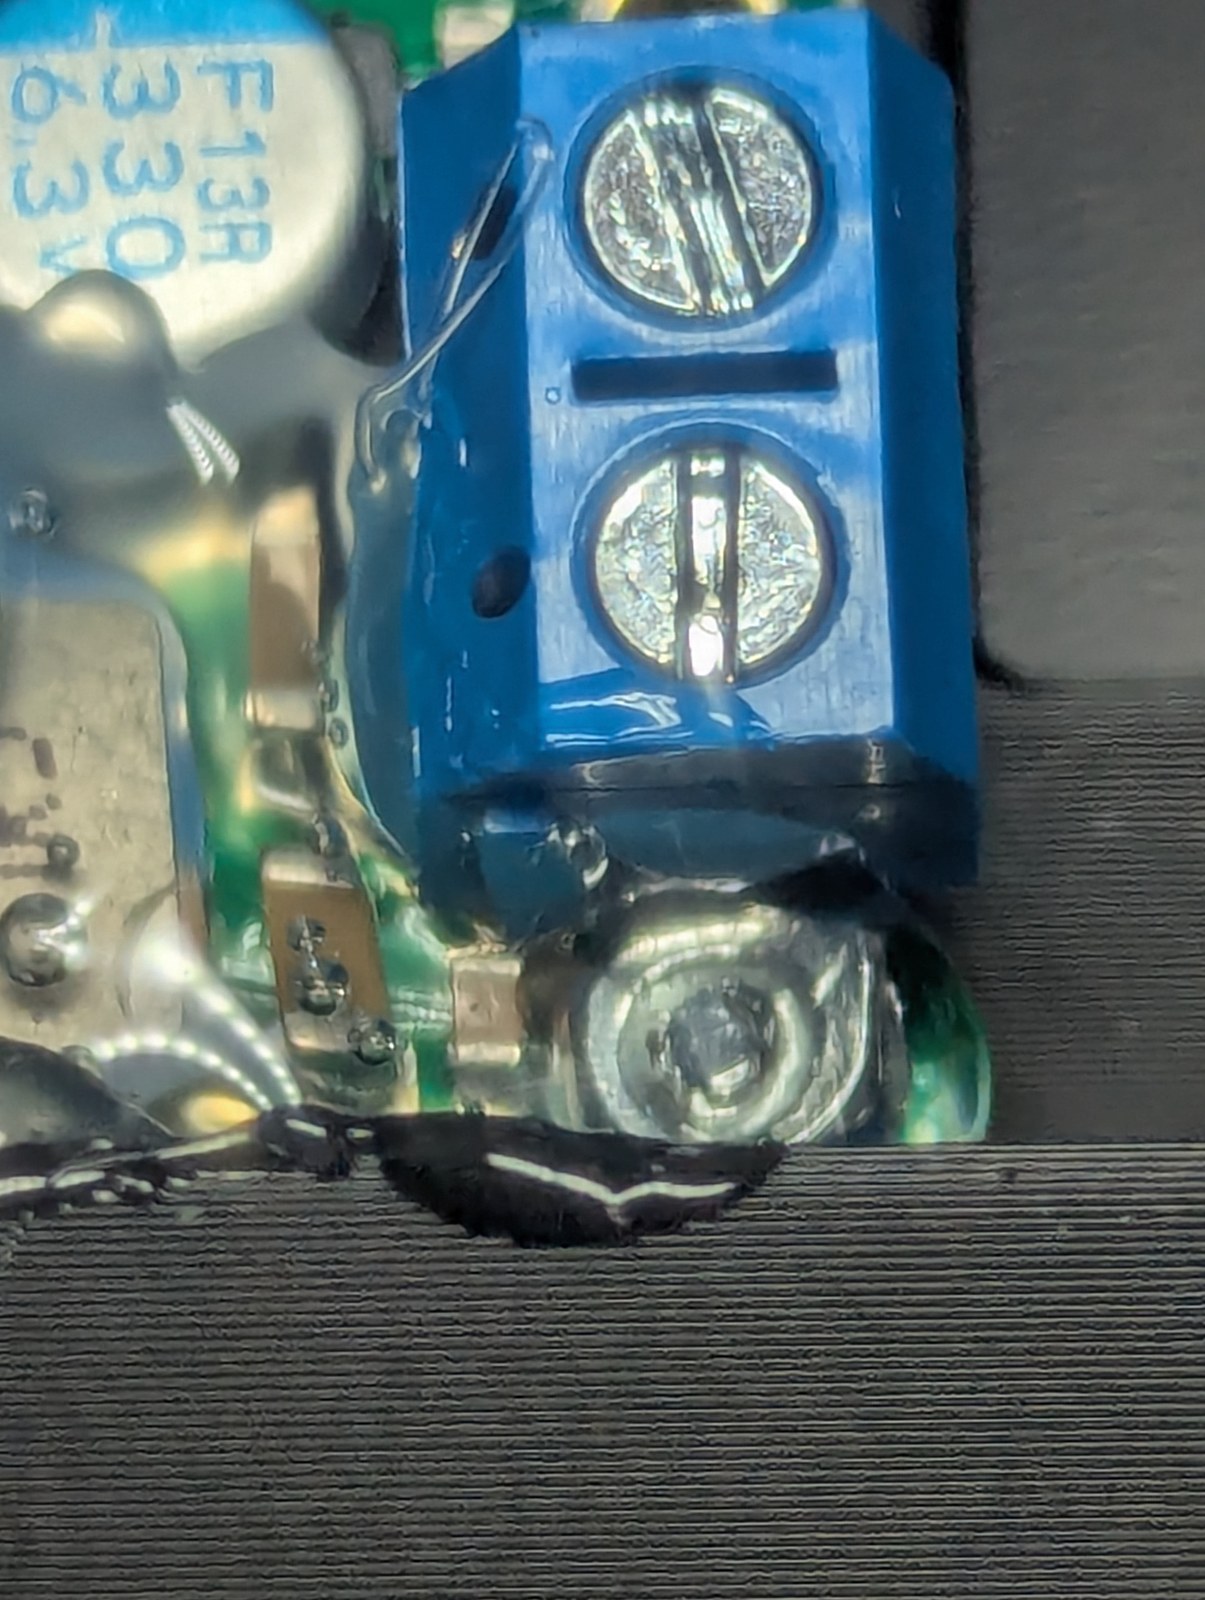
- Actuator Power Rail6.0V Regulated DC @ 10A Continuous (Dual XL4015 Buck Modules)
- Transient Suppression4,700 µF 16V Low-ESR Bulk Capacitance on Motor Rail
- Logic ArchitectureESP32 DevKit @ 3.3V Logic, Optically/Galvanically Isolated from Motor Bus
- PWM Offloading DriverNXP PCA9685 16-Channel 12-Bit PWM Controller via I²C (400 kHz)
- PWM Carrier Frequency50 Hz (20 ms period), 0.5 ms – 2.5 ms Pulse Width Range (4096-step resolution)
- Cable ManagementInternal hollow wrist raceway, strain-relieved DC input jack, silicone non-slip base
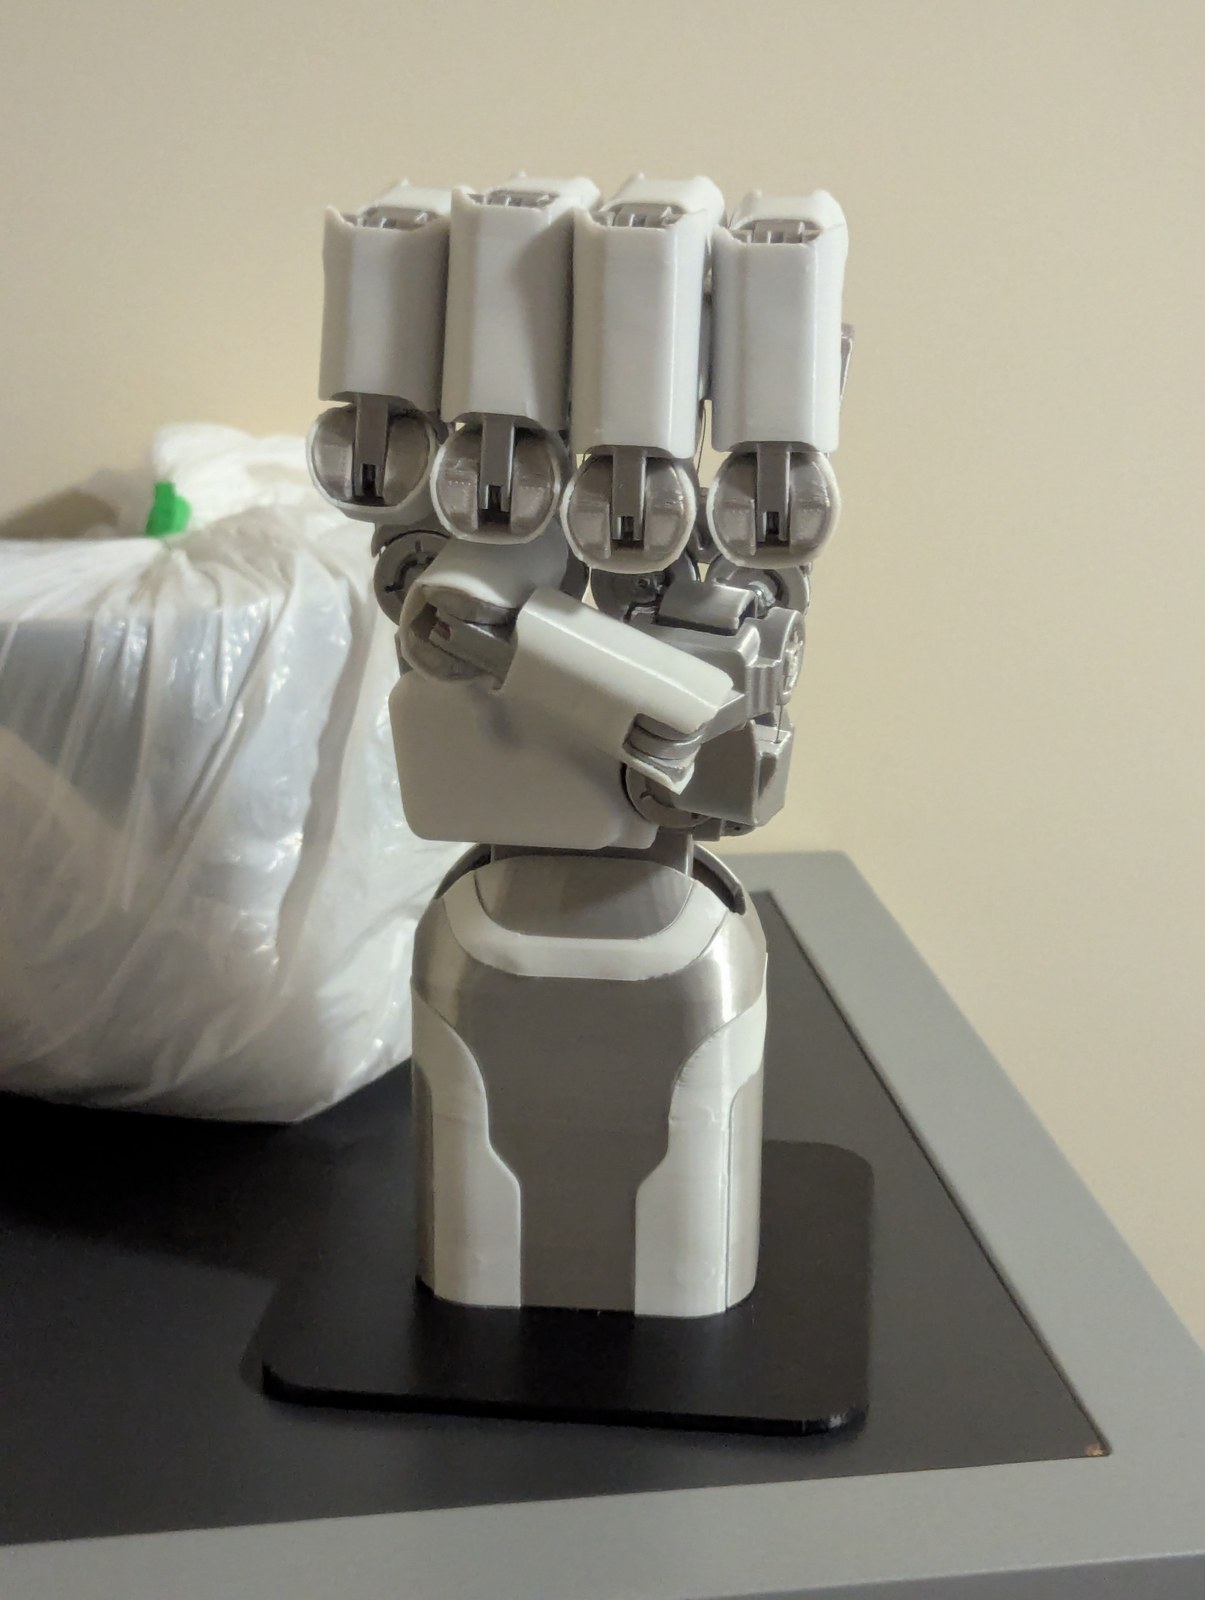
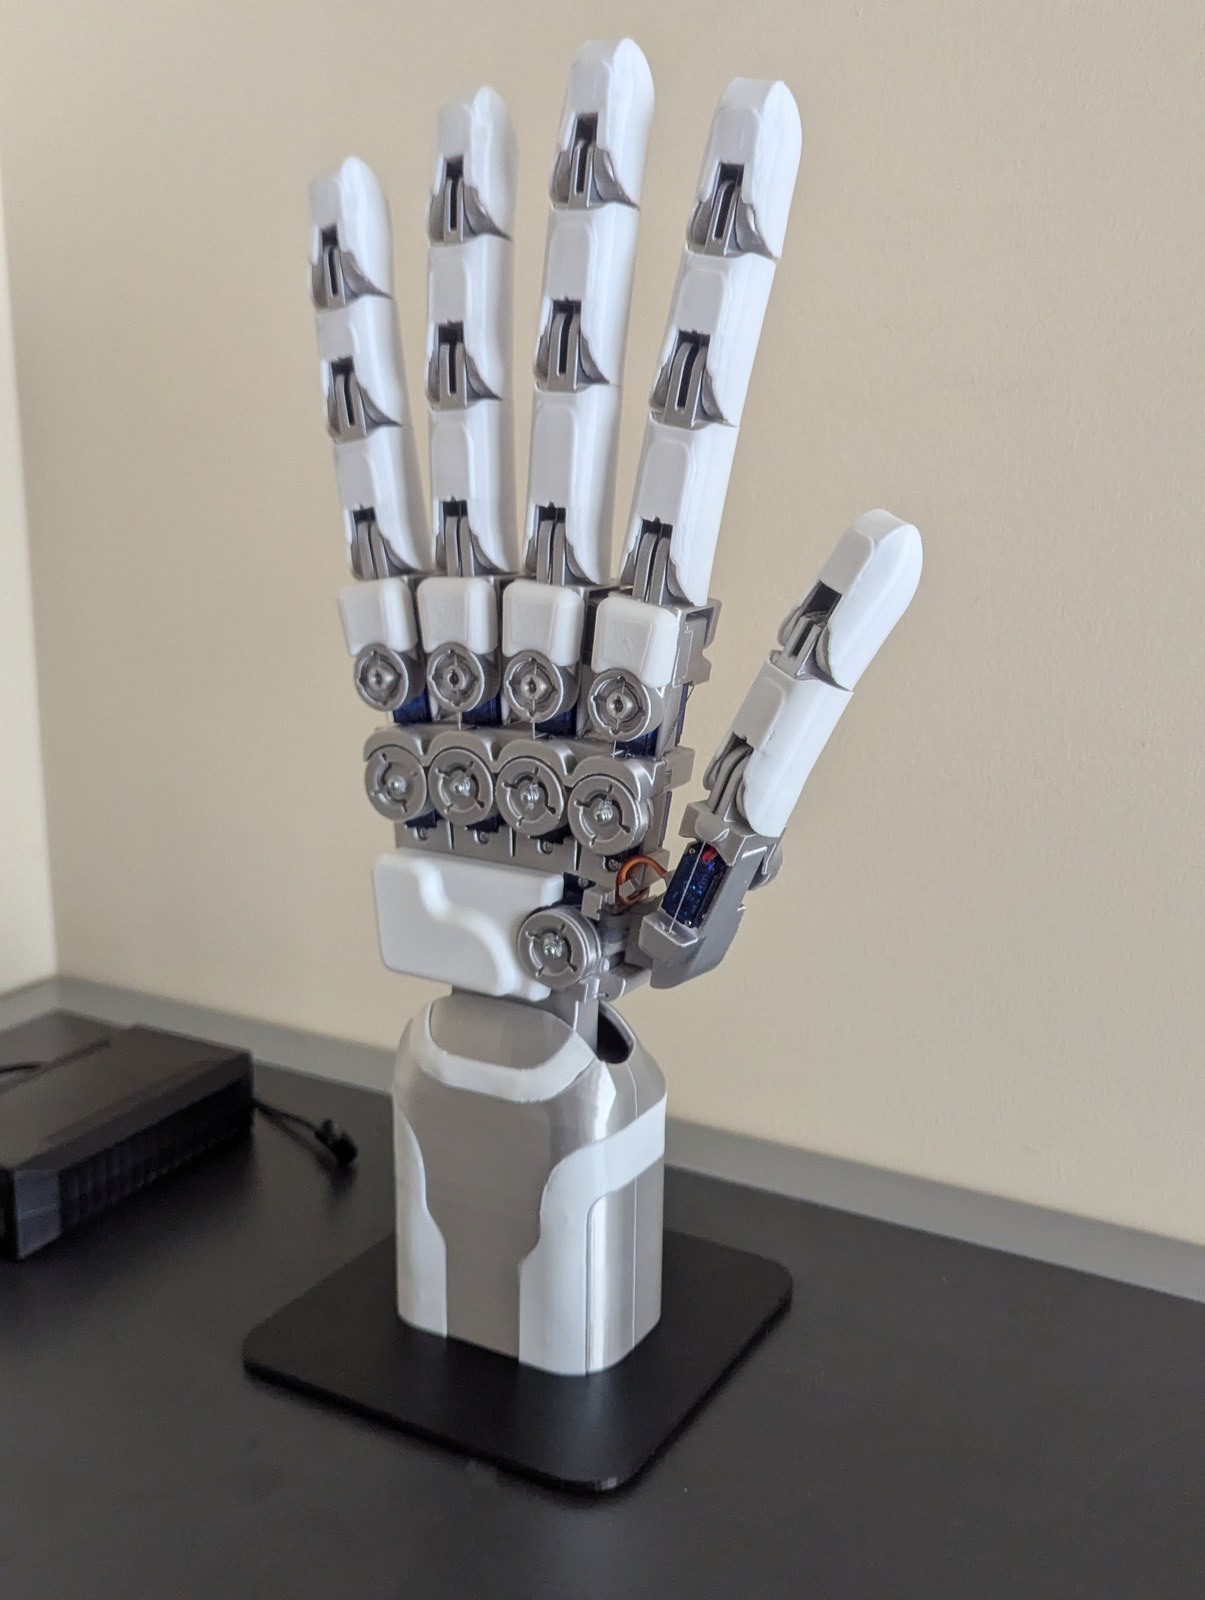
06Finished Product — Kinematics & System Showcase
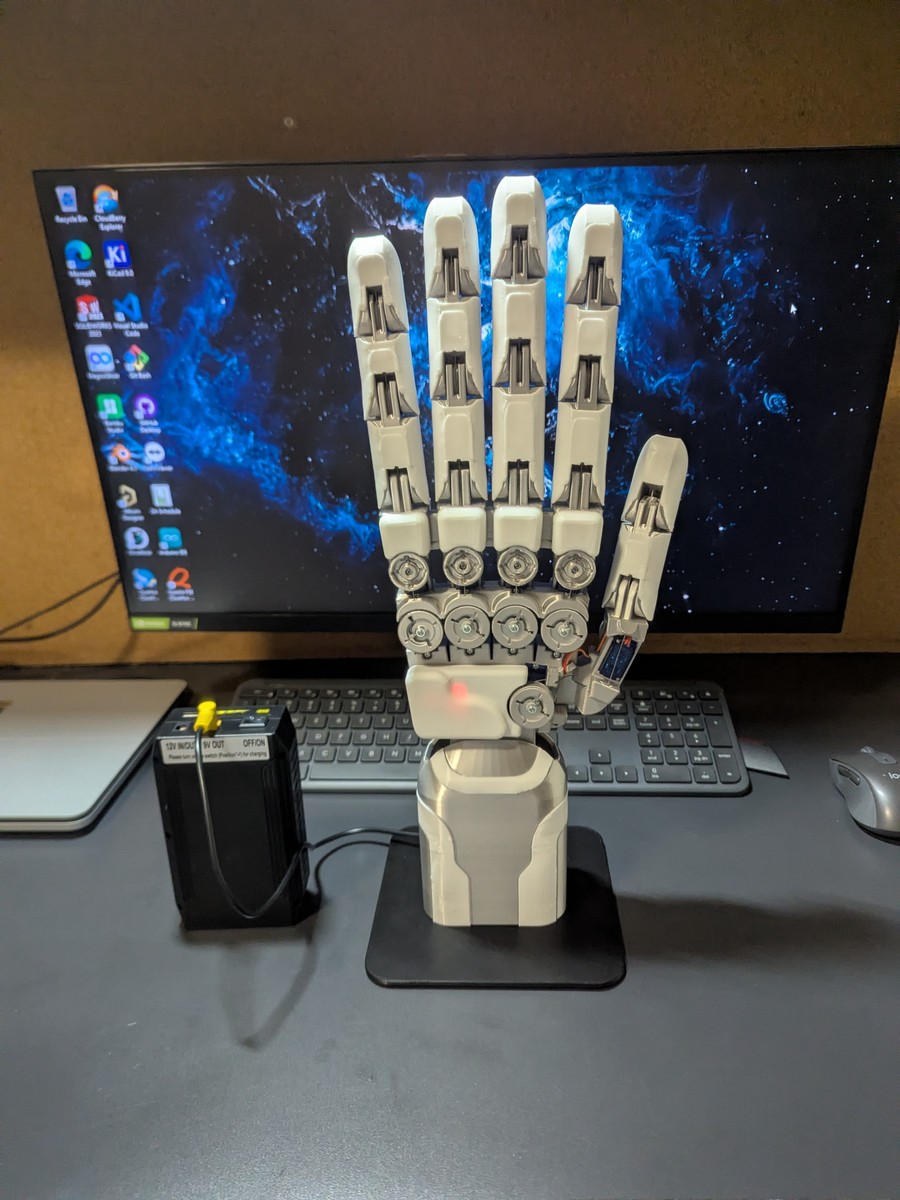
The finished 10-DOF dexterous hand mounted on its desktop pedestal combines an organic humanoid aesthetic with responsive, real-time actuation. Coordinated serial commands drive synchronized multi-finger flexion, wide knuckle splay, independent thumb circumduction, and high-stiffness power grasps.