projects / 3
Unitree G1 Humanoid — Teleoperation, Imitation & RL Control Suite
Five working control projects on a full-size 29-DOF bipedal humanoid — spanning every control plane of the robot: low-level 50 Hz joint streaming, high-level locomotion RPC, and serial-driven dexterous hands.
- Trained a PPO policy for ~53M timesteps that solves 7-joint inverse kinematics in real time — no analytical IK solver — then deployed it sim-to-real over DDS.
- Built a real-time hand teleoperation pipeline (~30 ms latency) mirroring a human hand from a webcam to a 6-DOF Inspire dexterous hand at 25–30 Hz.
- Root-caused a firmware RPC failure (error 3102) to an SDK service-name mismatch introduced in ai_sport ≥ 8.2.0.0 — a two-line patch restored all locomotion control.
- Authored robot behaviors by demonstration — recorder GUIs whose keyframed trajectories train continuous MLP policies for the arms.
01The Platform
- robotUnitree G1 EDU — 1.3 m, ~35 kg bipedal humanoid
- joints29 actuated (7 × 2 arms, 6 × 2 legs, 3 waist)
- handsInspire RH56 5-finger dexterous hands, 6 DOF each, RS-485
- computeJetson Orin NX onboard
- sensorsLivox Mid-360 LiDAR · Intel RealSense D435 depth camera
- middlewareCycloneDDS over wired Ethernet (192.168.123.x)
02The Seven Projects
Hand Mimic — Camera → Robot Hand
Webcam hand tracking mirrored live to the Inspire hand — MediaPipe landmarks, geometric retargeting, pinch detection, EMA smoothing.
Hand Recorder GUI — Keyframe Gesture Animator
Desktop GUI for authoring precise hand gestures — live sliders, recorded takes, combinable sequences, YAML preset playback.
MuJoCo Arm Policy — RL Goal Reaching
PPO agent trained ~53M steps solves 7-joint IK in real time; sim arm mirrors to the physical robot over DDS on keypress.
Arm Recorder GUI — 14-DOF Joint Animator
Dial, record, and replay full-arm trajectories — 50 Hz LowCmd streaming with PD gains; recordings train a continuous 3-axis arm policy.
WASDQE Walk — Locomotion Teleop
Keyboard-driven bipedal walking through the high-level velocity RPC — tap-to-inch pulses, safety clamps, and the error-3102 firmware fix.
Hardware Relay E-Stop — Dual Safety Cutoff
Wireless RF latching relay and head mushroom switch spliced via WAGO clips into G1 PC 1 for permanent compliant damping.
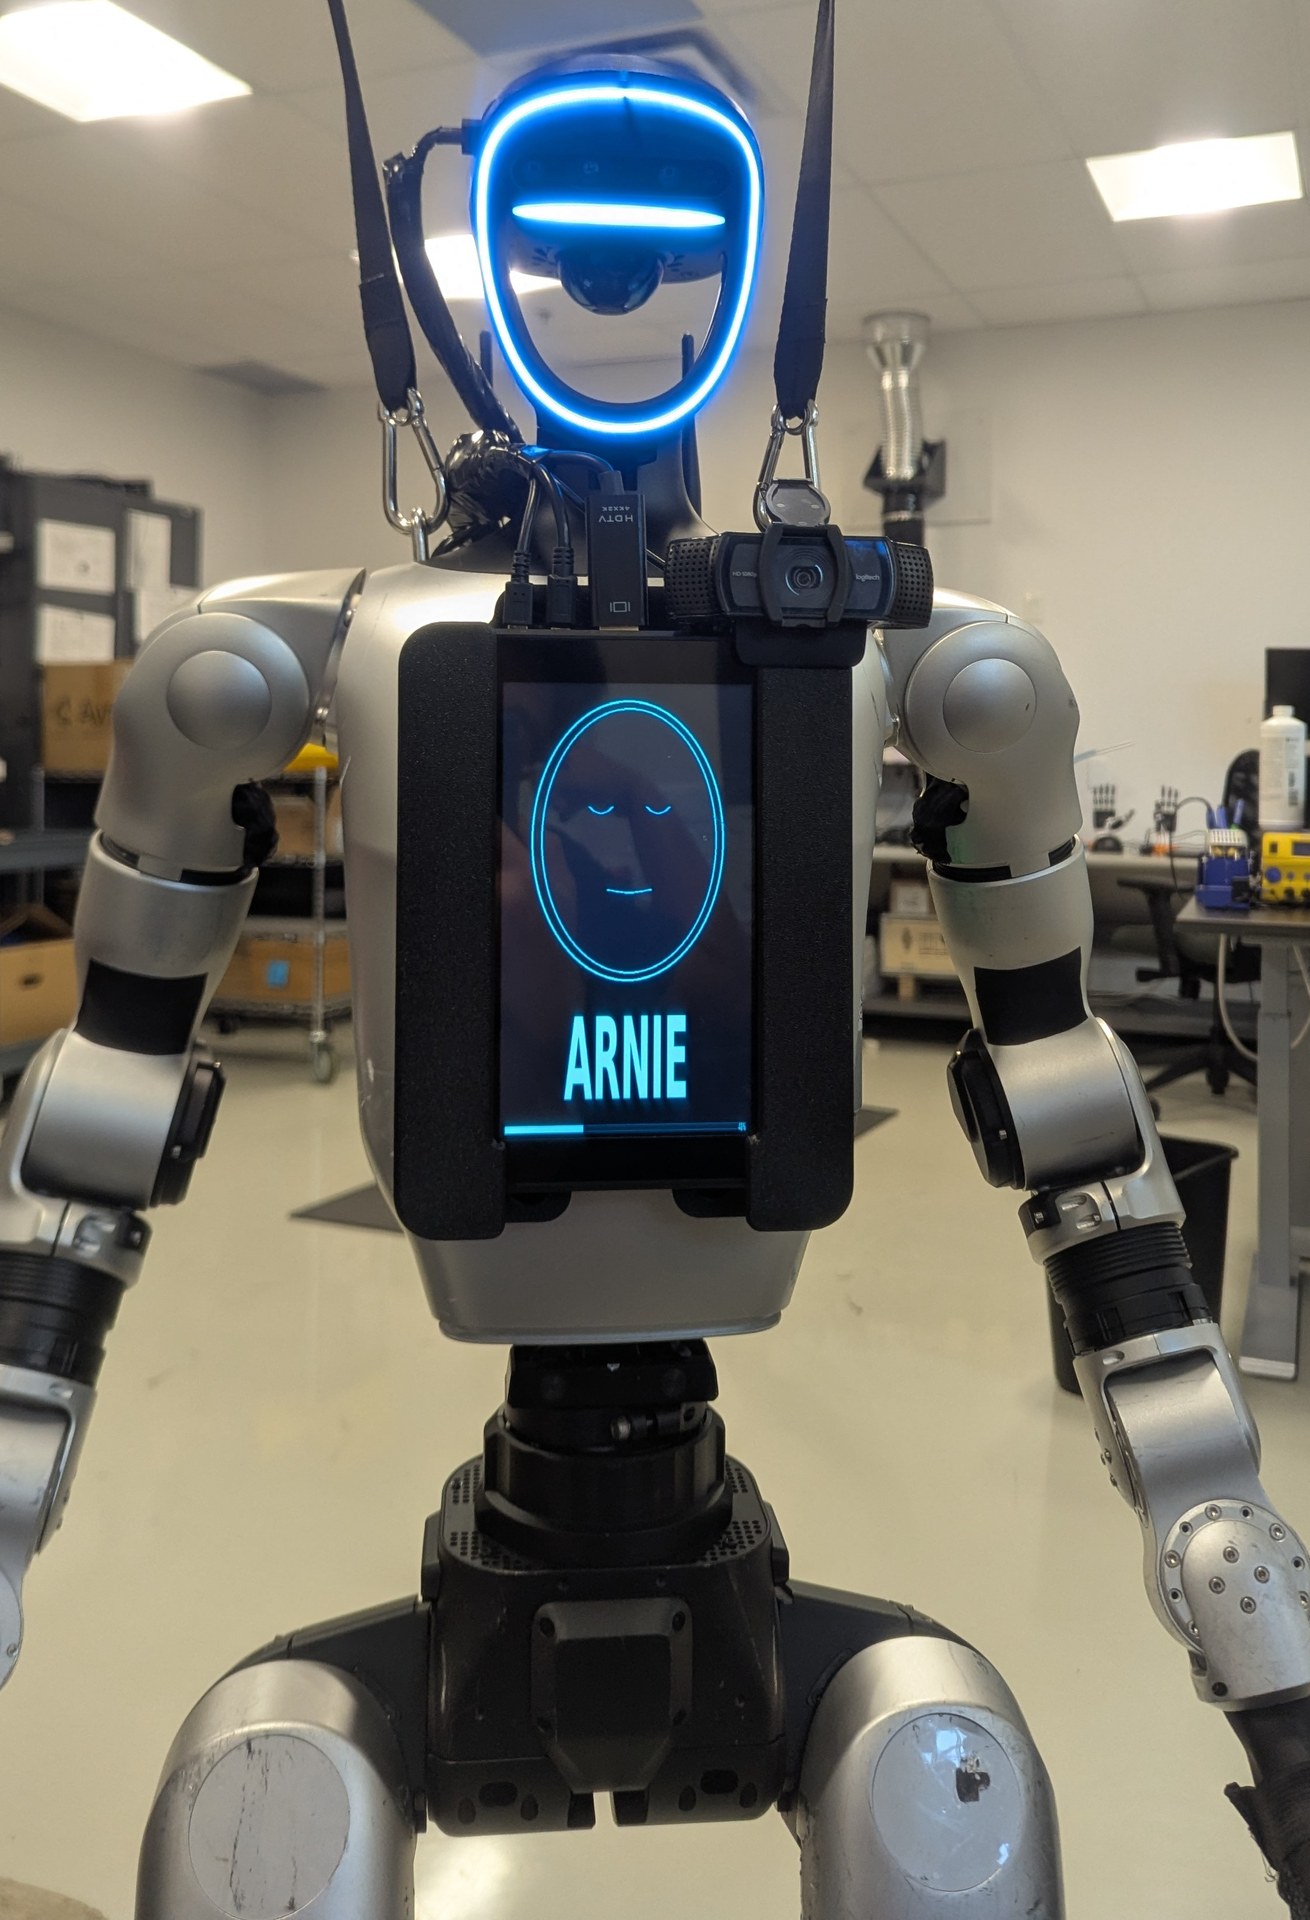
Camera & Display Mounts — Siemens NX CAD
Custom skull camera bracket and chest interactive touchscreen mount designed in Siemens NX and FDM 3D printed for the G1.
03Control Architecture
The control software interfaces directly with the Unitree G1 humanoid over CycloneDDS and RS-485, commanding 29 actuated joints across whole-body bipedal locomotion, bilateral 14-DOF arm manipulation, and dual 6-DOF dexterous hands.