Huamin (Lucas) Lu
Mechatronics Engineering @ University of Waterloo // Robotics · Embedded · CAD


Unitree G1 Humanoid
Five control projects on a 29-DOF humanoid — RL arm control, hand teleop, bipedal locomotion.
view project

7-DOF QDD Robot Arm
Cobot-style 7-DOF arm with quasi-direct-drive actuators. 10 kg arm, ~10 kg peak payload.
view project


10-DOF Dexterous Hand
Anthropomorphic robotic hand with 10 micro-servos, transient-safe power distribution.
view projectHand Mimic Teleop
Webcam hand tracking mirrored live to a 6-DOF dexterous robot hand.
view projectArm Recorder GUI
Dial, record, and replay full 14-DOF arm trajectories over CycloneDDS.
view projectHand Recorder GUI
Desktop GUI for authoring and combining precise hand gesture animations.
view projectRL Arm Policy
A PPO agent that solves 7-joint inverse kinematics — deployed to the real robot over DDS.
view projectWASDQE Walk
Keyboard-driven bipedal walking with bounded velocity pulses and safety exits.
view projectHardware Relay E-Stop
Dual-trigger safety integration putting humanoid into permanent damped mode on breach.
view project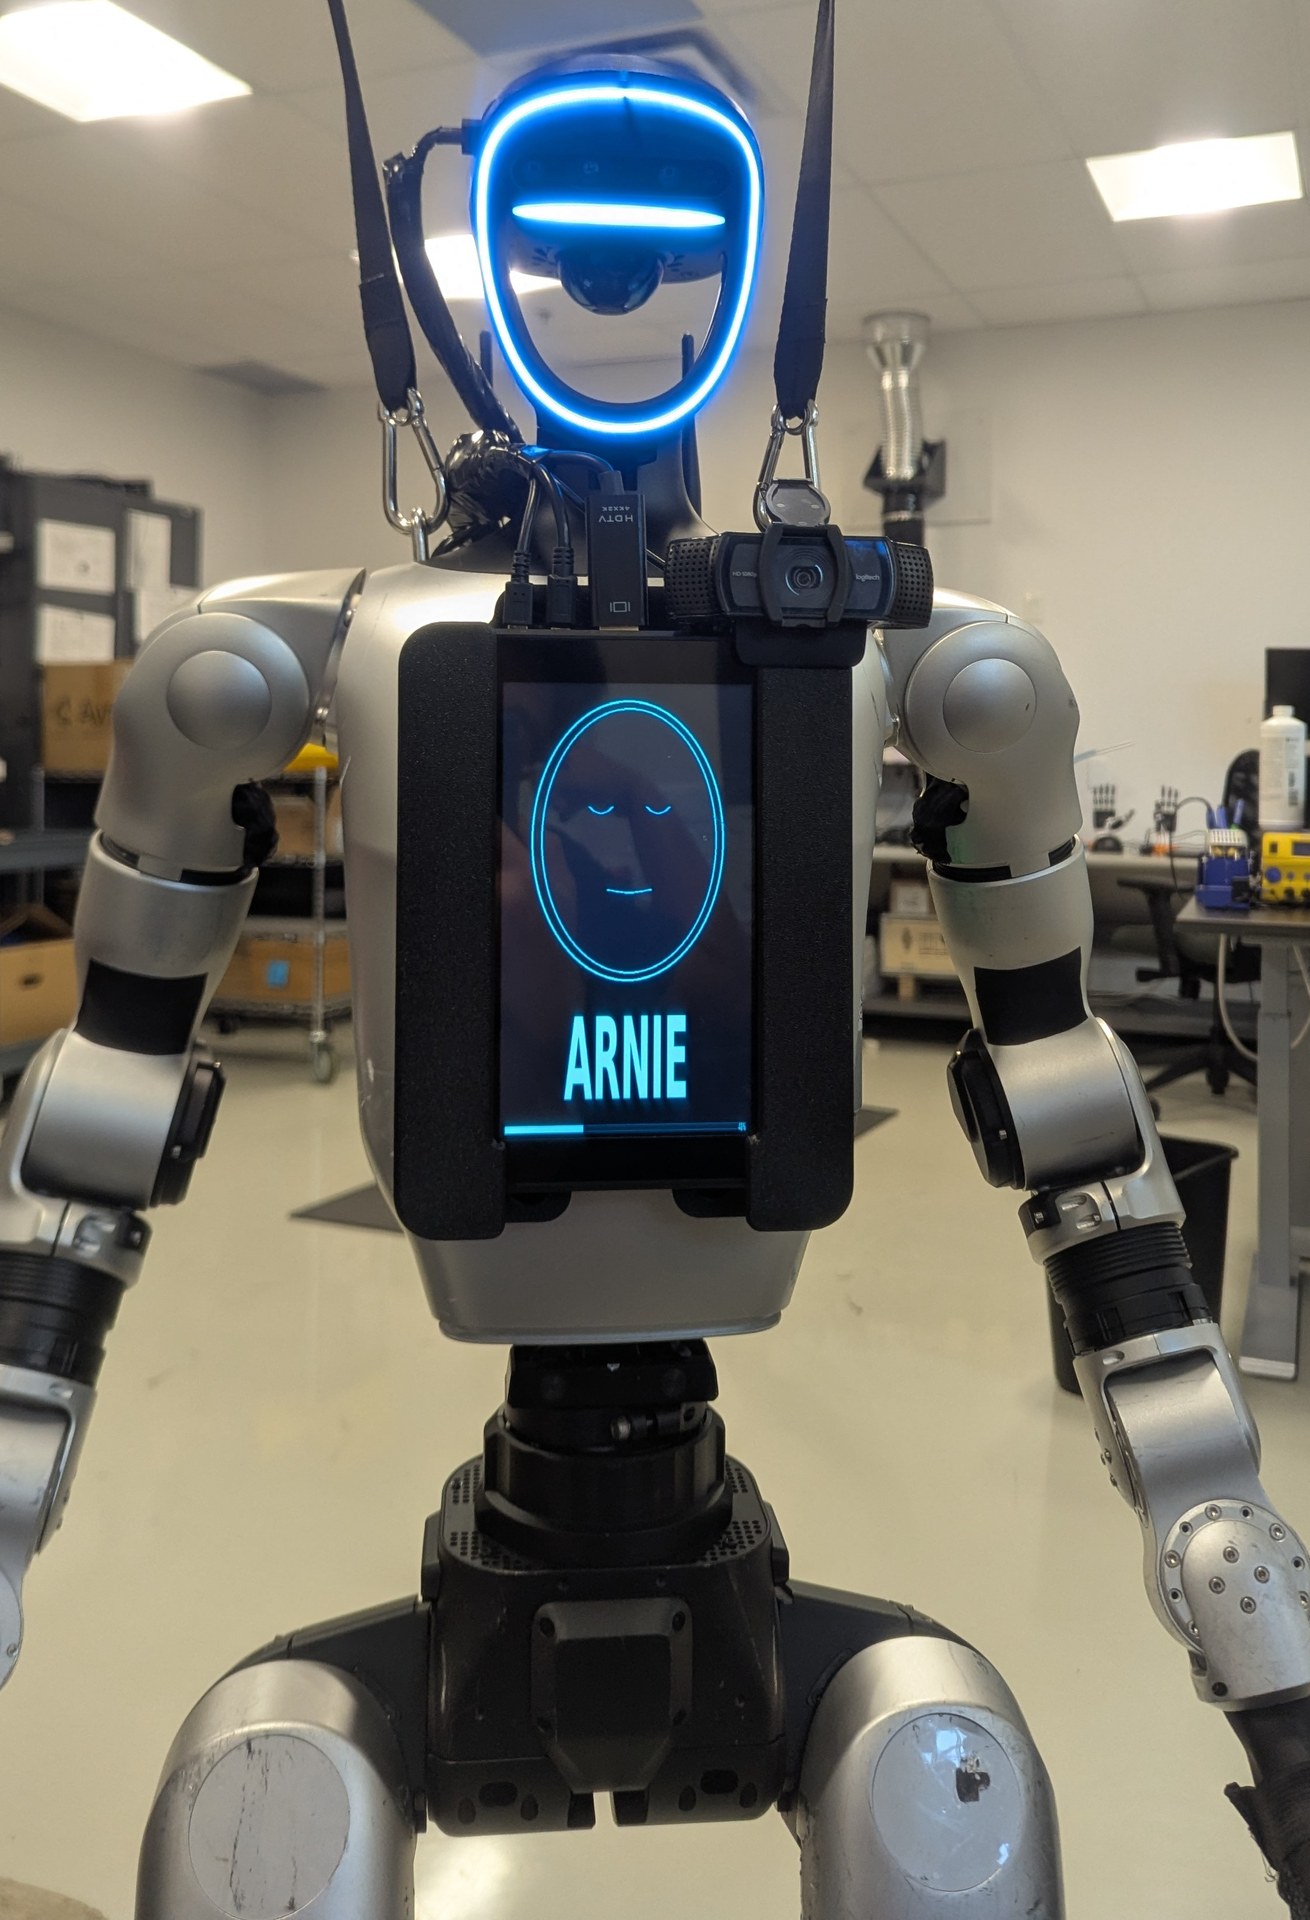
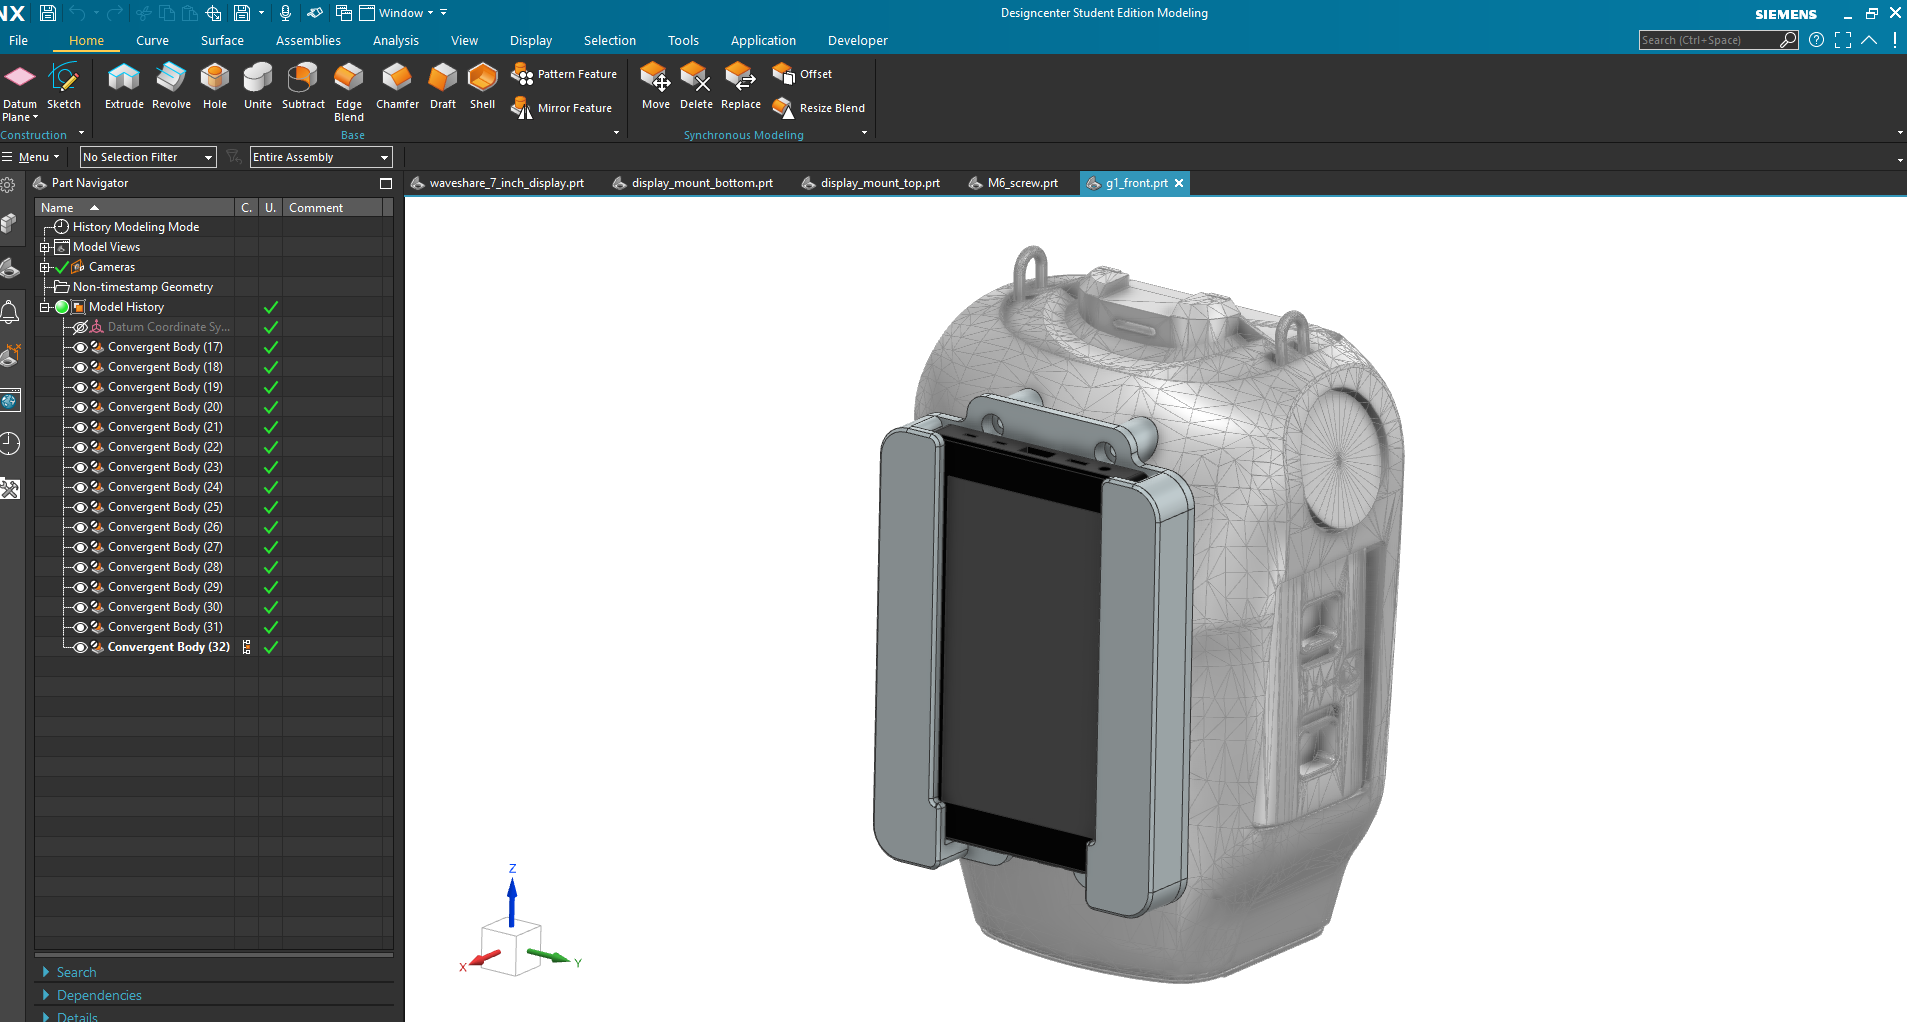
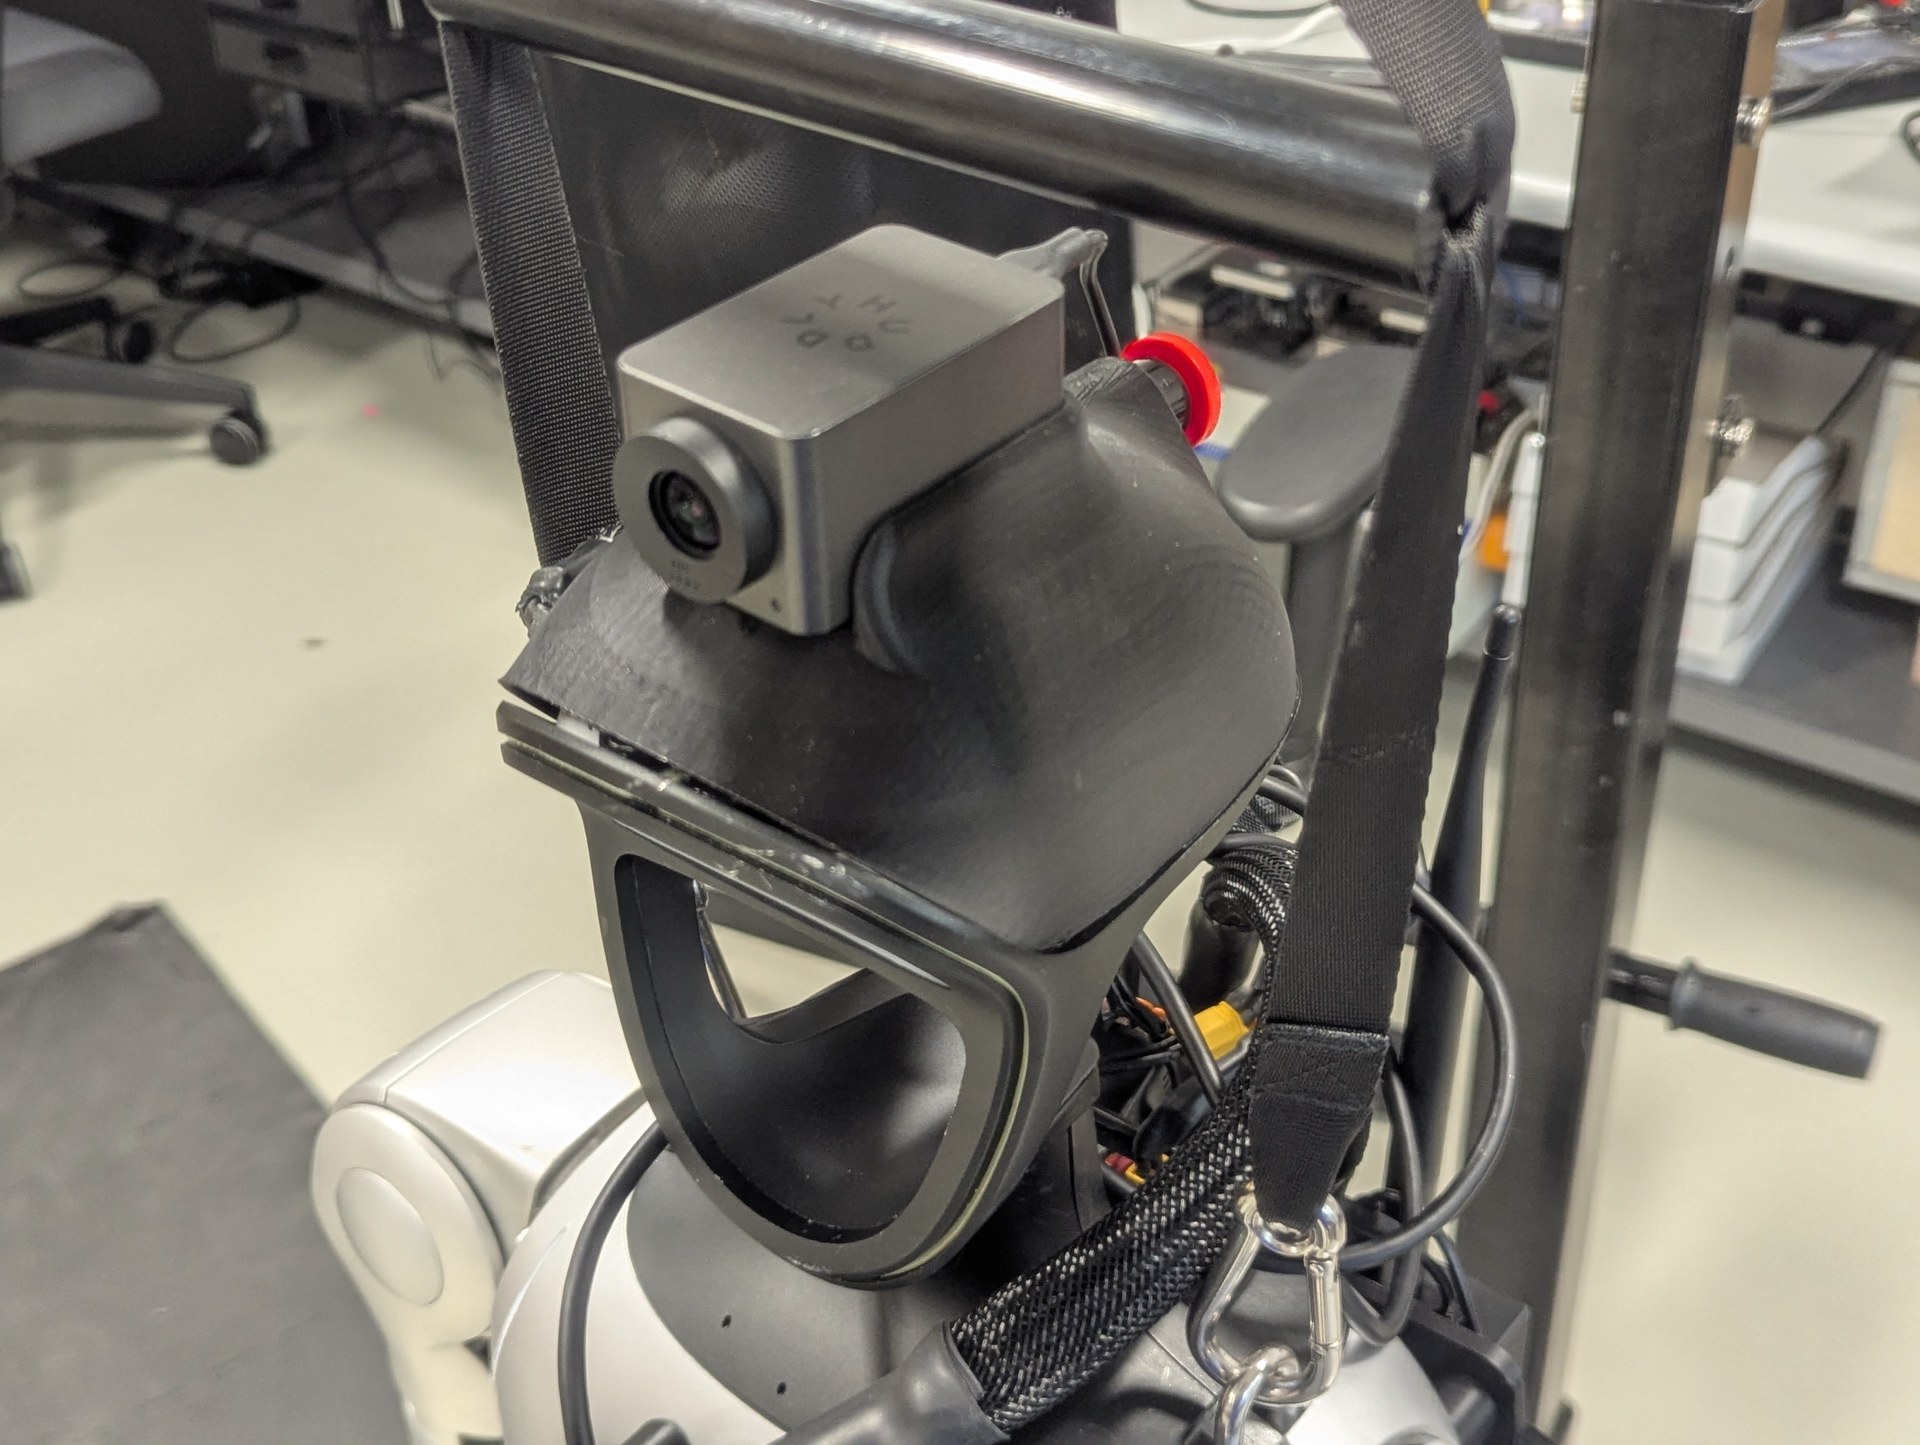
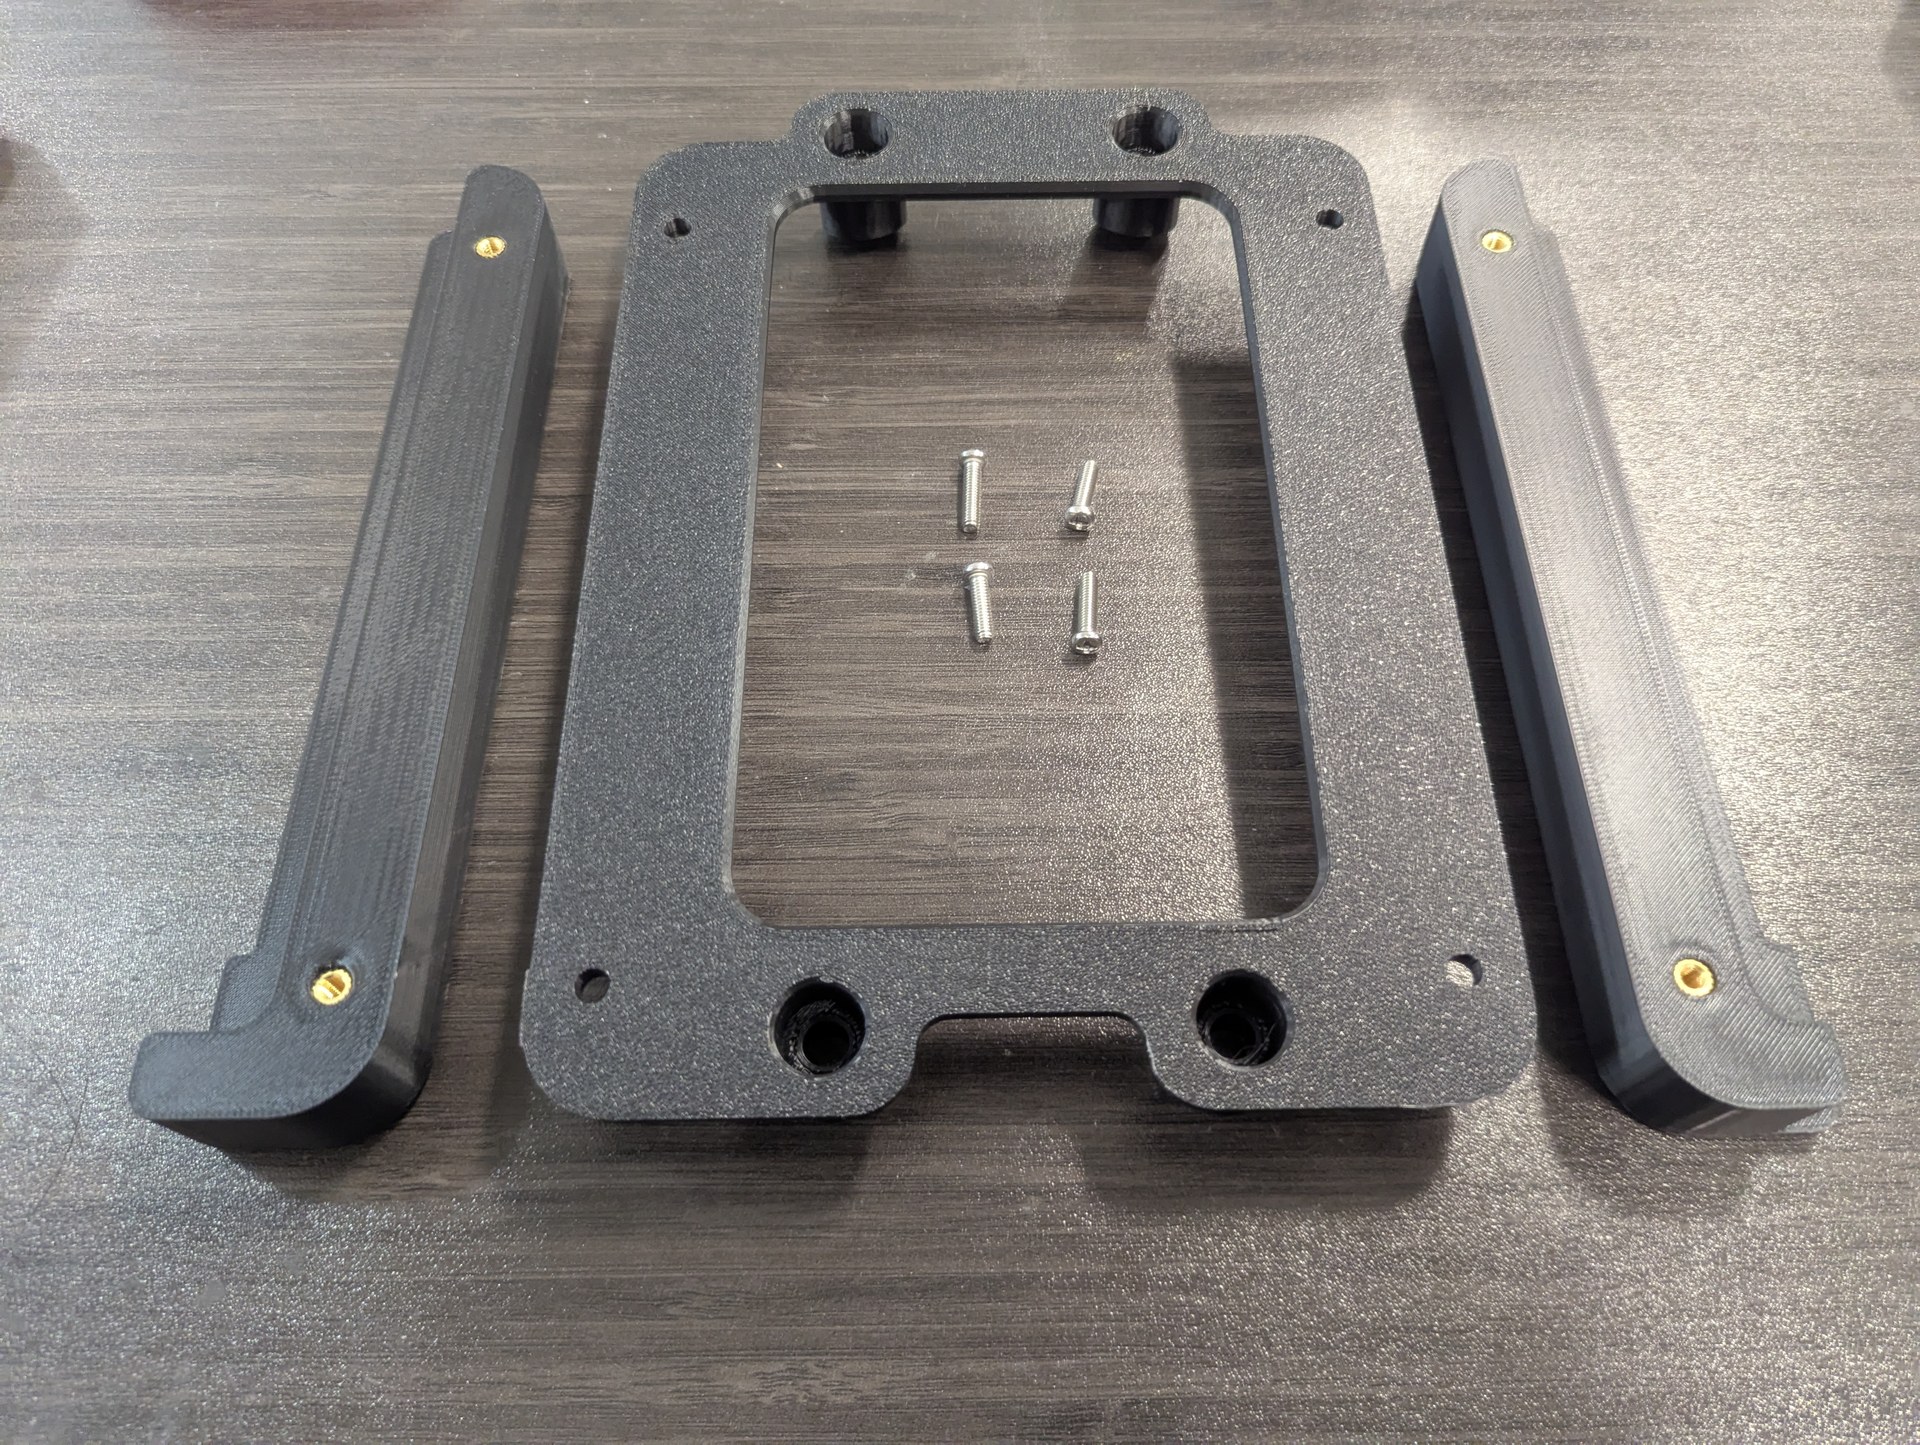
Camera & Display Mounts
Custom skull camera bracket and chest interactive touchscreen mount modeled in Siemens NX.
view projectabout

I'm a 2B Mechatronics Engineering student at the University of Waterloo who builds robots end-to-end — SolidWorks CAD, power and communication electronics, and embedded firmware in C++ and Python.
I've built a 7-DOF quasi-direct-drive robotic arm with a ~1:1 payload-to-weight ratio, a 10-servo dexterous hand, and a suite of control systems for a 29-DOF humanoid robot — reinforcement-learning arm control, real-time hand teleoperation, and bipedal locomotion.
My interests: humanoid and industrial robotics, learned control, and hardware that survives the real world.
Currently looking for robotics, mechanical design, and hardware engineering co-op roles.